
2 layers83 × 71 mm
 SageRobots/A412
Sage Robots A4 robot arm
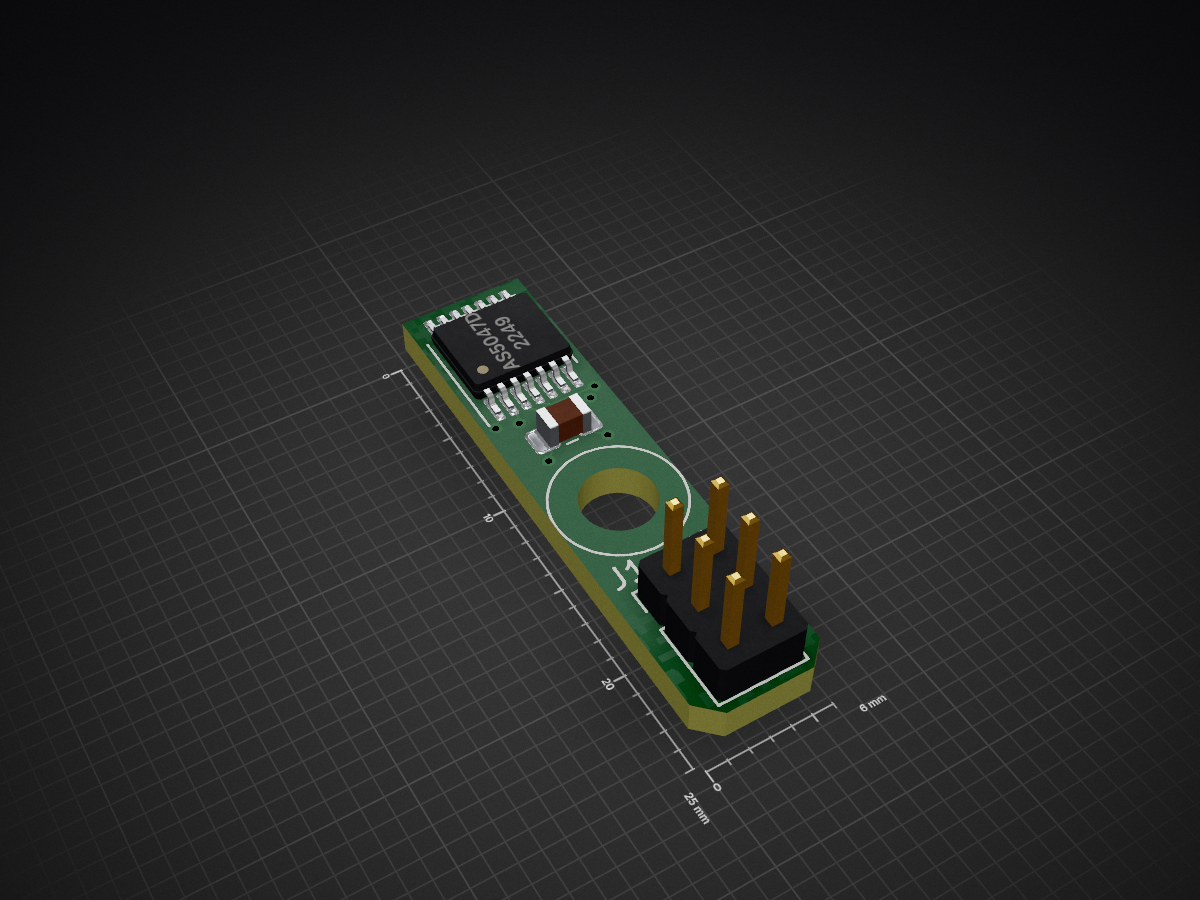
Encoder is an open-source printed circuit board by SageRobots, from the SageRobots/A4 repository on GitHub. It is a 2-layer board of 6 × 25 mm with 3 parts on 13 nets, routed with 51 tracks and 8 vias.
It is built around the AS5047D. Its parts include 1 capacitor, 1 IC and 1 connector.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 100nF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1 |
| 1 | AS5047D | Package_SO:TSSOP-14_4.4x5mm_P0.65mm | U1 |
| 1 | Conn_01x06_Male | Connector_PinHeader_2.00mm:PinHeader_2x03_P2.00mm_Vertical | J1 |
It measures 6 × 25 mm and has 2 copper layers, 1.6 mm thick.
3 parts, built around the AS5047D. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the SageRobots/A4 repository on GitHub, at the commit this page was made from: the board is PCBs/Encoder/Encoder.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask SageRobots before reusing the design.


pointhi/HighPower-Mechaduino
Mechaduino derivative which drives up to 10A, drawn using KiCad

NYDEREK/LineFollower_GRUZIK3.0
Loved the project? Please consider giving a Star ⭐️


williamhaarhoff/foc8313
Highly compact field oriented controller based on the DRV8313 IC

sequoia-hope/vesc_encoder
An openly licensed magnetic encoder board, compatible with VESC 4.12 based designs.

dognotdog/smol_servo
circuitry and software for controlling NEMA17 size brushless motors and stepper motors as servos.