2 layers204.1 × 93.3 mm
Proto2
rv456/BowlsEye
Repository for team 18's Real Time Embedded Programming Raspberry Pi project.
70 partsGPL-3.0

 rv456/BowlsEye
Repository for team 18's Real Time Embedded Programming Raspberry Pi project.
Proto1 is an open-source printed circuit board by rv456, from the rv456/BowlsEye repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 204.1 × 93.3 mm with 83 parts on 73 nets, routed with 308 tracks and 20 vias.
It is built around the LM324N and L78S05CV. Its parts include 21 resistors, 19 capacitors, 17 connectors, 9 ICs and 6 diodes.


Repository for team 18's Real Time Embedded Programming Raspberry Pi project.
Watch our promotional video at the link below!

To install the bowls eye system on the Raspberry Pi run the following
git clone https://github.com/rv456/BowlsEye.git
cd BowlsEye/Code/Pi_BowlsEyeMain/
make
./mainThe BowlsEye system requies Bluez and pigpio libraries. It also requires that SPI and bluethooth are enabled on the Raspberry Pi
sudo apt-get install bluetooth blueman bluez libbluetooth-devrm pigpio.tar
sudo rm -rf PIGPIO
wget abyz.me.uk/rpi/pigpio/pigpio.tar
tar xf pigpio.tar
cd PIGPIO
make
sudo make installfrom the installation instructions here
sudo raspi-confignavigate to SPI and enable, you will then need to reboot the Pi to enable the changes
sudo rebootCode contains all of the code written for the Raspberry Pi and the external GUI. Code documentation can be found here.
KiCad contains the various hardware design files used throught the project, including a full BOM and fabrication files. (note that part numbers for everything used in the project can also be found directly in the schematics thanks to kifields.
Planner contains documents related to project planning. These will be removed once the project is completed.
Resources contains various datasheets, notes and other supporting files.
Harvey Leicester: Raspberry Pi programming and hardware design.
Calum West: GUI programming and ultrasound guru.
Assistive technology is used throughout many sports to aid referees to determine the correct decision, or allow competitors to appeal against said decisions. However, in the sport of lawn bowls, there is still a large factor of human error that can occur when measuring the distance between the jack and the bowls when the game is close. As this is currently done with standard measurement techniques, any misreading of this distance by the referee will determine the wrong outcome of the game. Therefore, this project aims to remove the possibility of human error in these measurements by designing a real time embedded system that can perform these measurments more accurately than a human.
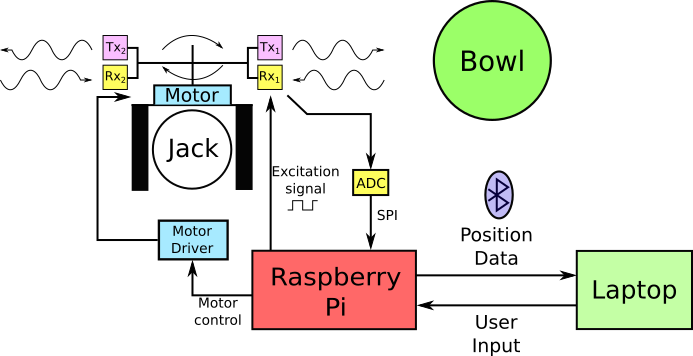
We have designed a system which uses ultrasonic transducers mounted on a stepper motor in order to map the distance from the jack to the surrounding area. This data is read via SPI by a Raspberry Pi and then transmitted via Bluetooth for a display on a GUI. More information can be found on our wiki.
A system overview is shown below, and you can follow our progress via this git, or our facebook or twitter.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 10 | R | Resistors_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R11, R12, R13, R14, R15, R16, R17, R18, R19, R21 |
| 9 | CONN_01X02 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-2_P5.00mm | J3, J4, J5, J6, J7, J8, J9, J10, J11 |
| 8 | 100nF | Capacitors_THT:C_Rect_L7.2mm_W3.0mm_P5.00mm_FKS2_FKP2_MKS2_MKP2 | C1, C2, C3, C4, C9, C10, C20, C21 |
| 6 | GS2 | Connectors:GS2 | J14, J15, J17, J18, J19, J20 |
| 4 | 100K | Resistors_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R5, R6, R9, R10 |
| 4 | 1K | Resistors_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R3, R4, R7, R8 |
| 4 | 1nF | Capacitors_THT:C_Rect_L7.2mm_W3.0mm_P5.00mm_FKS2_FKP2_MKS2_MKP2 | C16, C17, C18, C19 |
| 4 | D | Diodes_THT:D_T-1_P10.16mm_Horizontal | D1, D2, D3, D4 |
| 4 | transducer | BowlsEye:transducer | U6, U7, U8, U9 |
| 3 | 10uF | Capacitors_THT:CP_Radial_D5.0mm_P2.00mm | C8, C11, C22 |
| 2 | 10nF | Capacitors_THT:C_Rect_L7.2mm_W3.0mm_P5.00mm_FKS2_FKP2_MKS2_MKP2 | C12, C13 |
| 2 | 10pF | Capacitors_THT:C_Rect_L7.2mm_W3.0mm_P5.00mm_FKS2_FKP2_MKS2_MKP2 | C14, C15 |
| 2 | 2N3904 | TO_SOT_Packages_THT:TO-92_Molded_Narrow | Q1, Q2 |
| 2 | 3K9 | Resistors_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R1, R2 |
| 2 | LED | LEDs:LED_D3.0mm | D5, D7 |
| 1 | 0R | Resistors_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P10.16mm_Horizontal | R20 |
| 1 | ADC122S101 | BowlsEye:MyVSSOP-8_3.0x3.0mm_Pitch0.65mm | U1 |
| 1 | CONN_01X04 | Connectors_Terminal_Blocks:TerminalBlock_Altech_AK300-4_P5.00mm | J2 |
| 1 | CONN_02X20 | Pin_Headers:Pin_Header_Straight_2x20_Pitch2.54mm | J1 |
| 1 | L298_TH | TO_SOT_Packages_THT:TO-220-15_Vertical_StaggeredType1 | U2 |
| 1 | L78S05CV | TO_SOT_Packages_THT:TO-220-3_Horizontal | U3 |
| 1 | LD1117S33TR_SOT223 | TO_SOT_Packages_THT:TO-220-3_Horizontal | U4 |
| 1 | LM324N | Housings_DIP:DIP-14_W7.62mm_LongPads | U5 |
| 1 | SW_SPDT | BowlsEye:SPDT | SW1 |
The 75 most common of 83 parts.
rv456/BowlsEye
Repository for team 18's Real Time Embedded Programming Raspberry Pi project.

rv456/BowlsEye
Repository for team 18's Real Time Embedded Programming Raspberry Pi project.

dtpisanty/dmx2motion
An open-hardware project to control varing frequency AC motror drivers through DMX, ArtNet, OSC and MQTT

AidarIglesias/Projecte_Neteja_Parabrises
El sistema ha de complir les seguents especificacions:

AlistairCheeseman/WindTunnelApparatus
MENG Data Acquisition + motion control for Wind Tunnel Apparatus


PacktPublishing/Hands-On-Embedded-Programming-with-CPP-17
Hands-On Embedded Programming with CPP 17, published by Packt


It measures 204.1 × 93.3 mm and has 2 copper layers, 1.6 mm thick.
83 parts, built around the LM324N and L78S05CV. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rv456/BowlsEye repository on GitHub, at the commit this page was made from: the board is KiCad/Shield/Proto1/Proto1.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).