2 layers78 × 94.7 mm
ESP 32
robocon2026git-code/ELECTRICAL-AND-EMBEDDED
This document explains \\how team members should clone the repo, set up Git, and work using feature branches\\.
154 parts
 robocon2026git-code/ELECTRICAL-AND-EMBEDDED
This document explains \\how team members should clone the repo, set up Git, and work using feature branches\\.
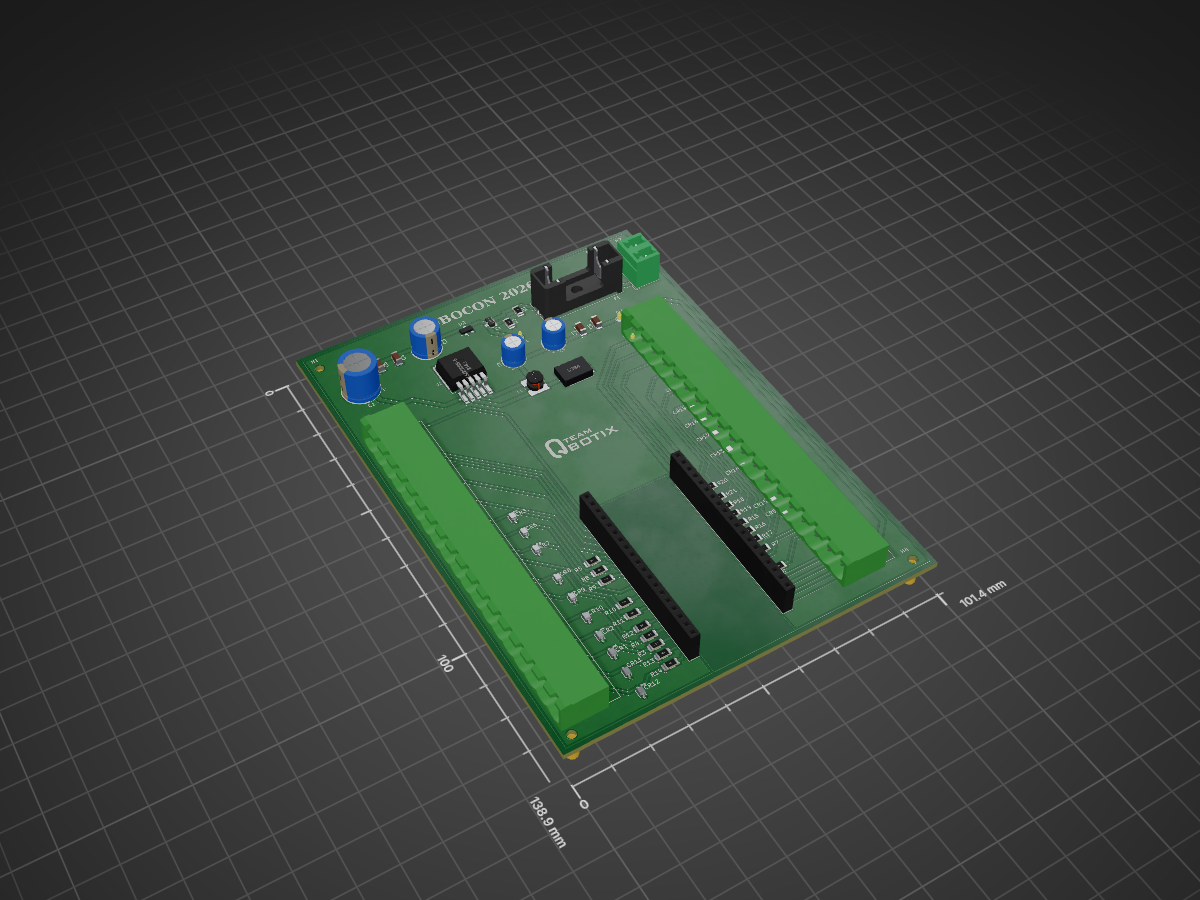
FINAL DESIGN is an open-source printed circuit board by robocon2026git-code, from the robocon2026git-code/ELECTRICAL-AND-EMBEDDED repository on GitHub. It is a 2-layer board of 101.4 × 138.9 mm with 68 parts on 60 nets, routed with 312 tracks and 0 vias.
It is built around the LM2596S-5.0, PESD3V3L1BA,115-ES and AO3401A, with the SS34 among its other parts. Its parts include 21 resistors, 8 capacitors, 5 connectors, 2 diodes and 1 IC.


# GITHUB WORKFLOW GUIDE
Welcome to **ROBOCON WORKSPACE**
This document explains **how team members should clone the repo, set up Git, and work using feature branches**.
⚠️ Direct changes to main are NOT allowed.
All work must be done using **feature branches** and merged via **Pull Requests (PRs)**.
## 🧠 Git Basics (Quick Understanding)
- **Repository (repo)** → Project stored with version control
- **main branch** → Stable, reviewed code only
- **feature branch** → Your personal workspace
- **commit** → A saved snapshot of changes
- **origin** → Remote GitHub repository
- **Pull Request (PR)** → Request to merge code into main
## One-Time Setup (Required on Every New PC)
Run these commands **once** after installing Git:
git config --global user.name "Your Name"

git config --global user.email "your-email@example.com"

git config --global init.defaultBranch main


\## To verify configuration


git config --global --list


**## Cloning and work steps starts from here:**


!!!!IMPORTANT ONE TIME SETTING AFTER INSTALLED GIT:

git clone https://github.com/robocon2026git-code/ELECTRICAL-AND-EMBEDDED.git
| Qty | Value | Footprint | References |
|---|---|---|---|
| 19 | PESD3V3L1BA_115 | footprints:DIODE_PESD3V3L1BA_115_NEX | CR1, CR2, CR3, CR4, CR5, CR6, CR10, CR11, CR12, CR13, CR14, CR15, CR16, CR17, CR18, CR19 +3 |
| 17 | 100 | Resistor_SMD:R_1206_3216Metric | R5, R6, R7, R8, R10, R11, R12, R13, R14, R15, R16, R17, R18, R19, R20, R21 +1 |
| 4 | MountingHole_2.2mm_M2 | MountingHole:MountingHole_2.2mm_M2 | H1, H2, H3, H4 |
| 2 | 0.1uF | Capacitor_SMD:C_1206_3216Metric | C6, C8 |
| 2 | 100K | Resistor_SMD:R_1206_3216Metric | R1, R2 |
| 2 | 10uF | Capacitor_SMD:C_1206_3216Metric | C4, C7 |
| 2 | 220uF | Capacitor_THT:CP_Radial_D6.3mm_P2.50mm | C2, C5 |
| 2 | 33 | Resistor_SMD:R_1206_3216Metric | R3, R4 |
| 2 | Conn_01x19_Socket | Connector_PinSocket_2.54mm:PinSocket_1x19_P2.54mm_Vertical | J3, J5 |
| 2 | TB010-508-P19BK | TB010-508-P19BK:CUI_TB010-508-P19BK | J2, J4 |
| 1 | 12V | TestPoint:TestPoint_Pad_D1.5mm | TP1 |
| 1 | 3V3 | TestPoint:TestPoint_Pad_D1.5mm | TP2 |
| 1 | 4628 | CATRIDGE_FUSE:FUSE_4628 | F1 |
| 1 | 470uF | Capacitor_THT:CP_Radial_D8.0mm_P3.50mm | C3 |
| 1 | 5V | TestPoint:TestPoint_Pad_D1.5mm | TP3 |
| 1 | 680uF | Capacitor_THT:CP_Radial_D10.0mm_P5.00mm | C1 |
| 1 | AO3401A | A03401:SOT23-3 | Q1 |
| 1 | LM2596S-5 | Package_TO_SOT_SMD:TO-263-5_TabPin3 | U1 |
| 1 | LOGO | ROBOCON2026_LOGO:ROBOCON 2026 LOGO | G*** |
| 1 | LOGO | QBOTIX_LOGO:QBOTIX_LOGO | G*** |
| 1 | MMBZ5242B-7-F | MMBZ5242B-7-F:SOT91P240X102-3N | D2 |
| 1 | SS34 | SS34:DIO_SS34 | D1 |
| 1 | Screw_Terminal_01x02 | Connector_Phoenix_MC_HighVoltage:PhoenixContact_MCV_1,5_2-G-5.08_1x02_P5.08mm_Vertical | J1 |
| 1 | WE-PD2_4532 | Inductor_SMD:L_Wuerth_WE-PD2-Typ-MS | L1 |
It measures 101.4 × 138.9 mm and has 2 copper layers, 1.6 mm thick.
68 parts, built around the LM2596S-5.0, PESD3V3L1BA,115-ES, AO3401A and SS34. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the robocon2026git-code/ELECTRICAL-AND-EMBEDDED repository on GitHub, at the commit this page was made from: the board is KiCad Projects/ESP32_PCB_ONLY_PINS/FINAL_DESIGN.kicad_pcb and its schematic KiCad Projects/ESP32_PCB_ONLY_PINS/FINAL_DESIGN.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask robocon2026git-code before reusing the design.
robocon2026git-code/ELECTRICAL-AND-EMBEDDED
This document explains \\how team members should clone the repo, set up Git, and work using feature branches\\.

AhmedAbo-Eita/BLDC_Motor_Driver
BLDC Motor Driver hardware and firmware project including power stage, gate driver, protection circuits, and control firmware for sensor-based and/or sensorless BLDC motors.


dexus1337/automotive-gateway
An automotive-grade, multi-protocol vehicle network interface, Man-in-the-Middle (MitM) filter, and wireless telemetry gateway


bejaouihamza/robotic_arm_controller
Traditional servo controllers simply send PWM signals. This board goes further:


willem-pennings/balancing-cube
A cube that balances itself in a corner or edge using reaction wheels