2 layers
Maglev26
Hansolini/Take-home-Maglev-lab
A small lab for students in control engineering to learn control topics at home!
60 parts15MIT

 rmingon/servo-controller
Custom-made dual-servo testing platform. It is designed for engineers, makers, and robotics developers who need a reliable and convenient way to drive and test two RC servos simultaneously from a PC.
Servo controller is an open-source printed circuit board by rmingon, from the rmingon/servo-controller repository on GitHub. It is a 2-layer board of 49 × 37 mm with 31 parts on 52 nets, routed with 144 tracks and 16 vias.
It is built around the ATMEGA328PB-AU, CH340C and LM1117S-5.0. Its parts include 12 capacitors, 6 connectors, 3 ICs, 2 resistors and 2 diodes. It belongs with the robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.


This repository contains the design files, schematics, and PCB layout for a compact, custom-made dual-servo testing platform. It is designed for engineers, makers, and robotics developers who need a reliable and convenient way to drive and test two RC servos simultaneously from a PC.
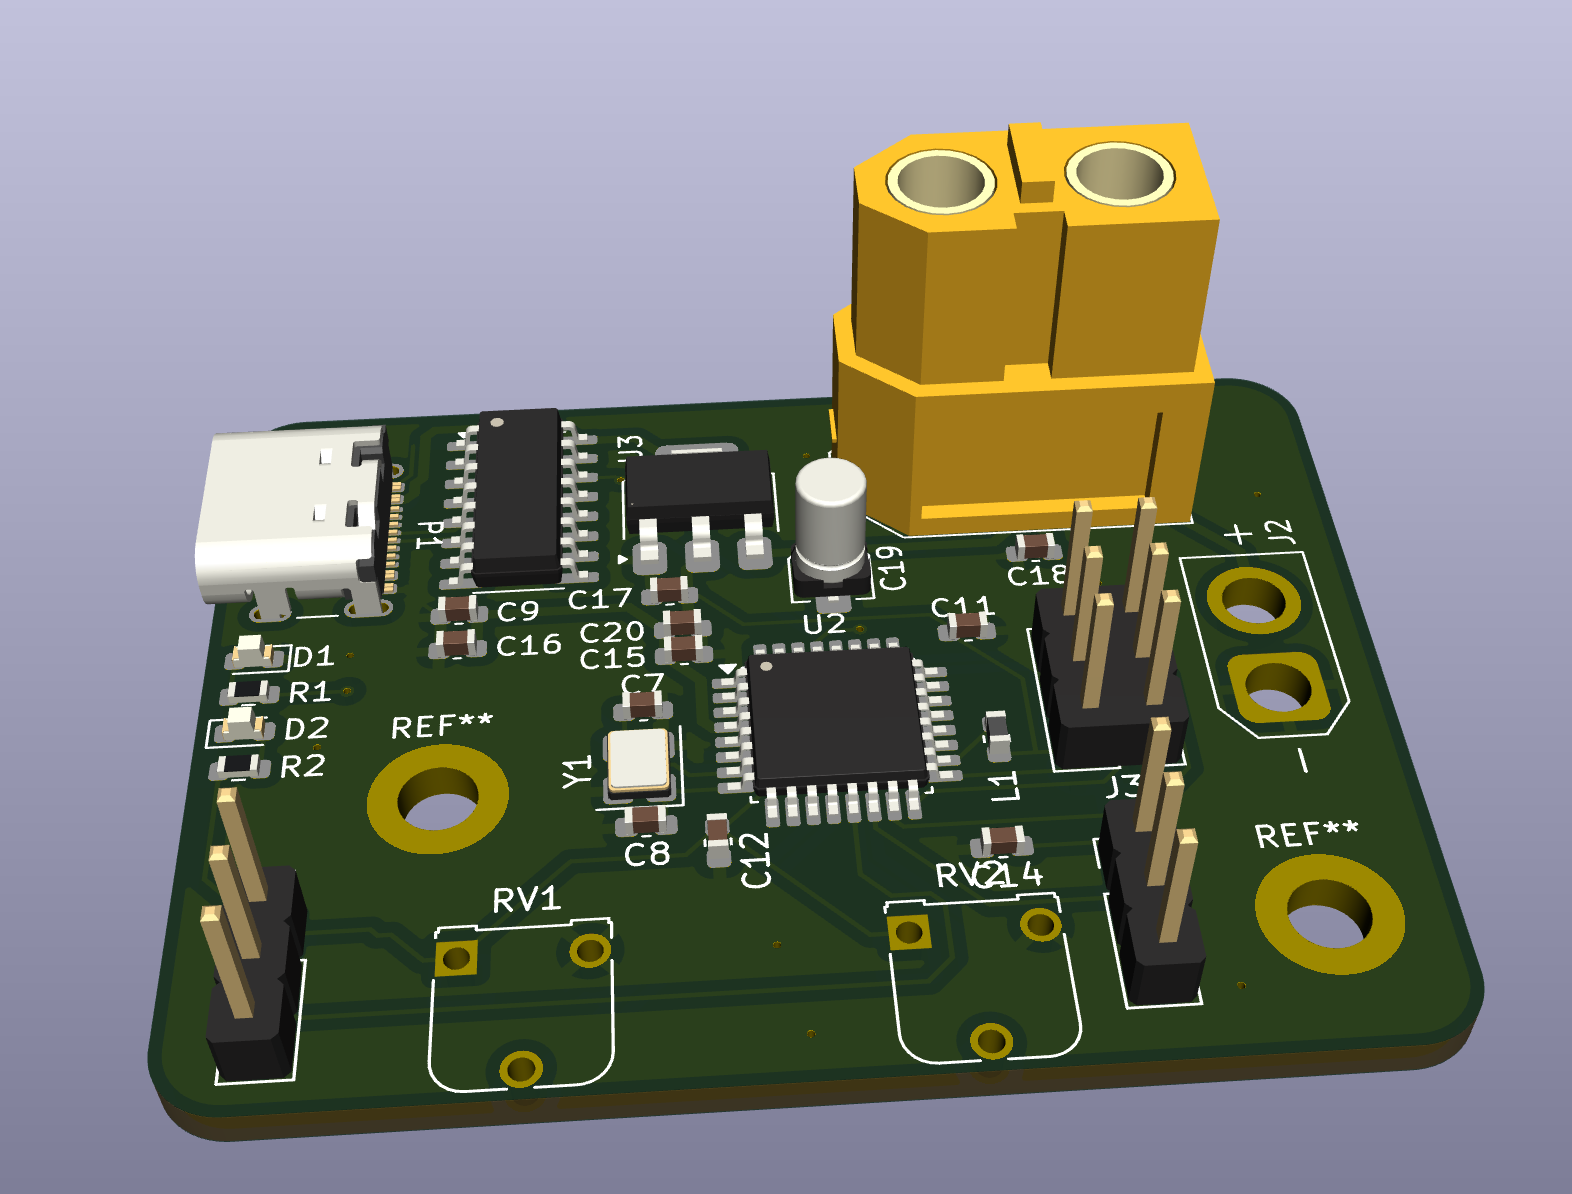
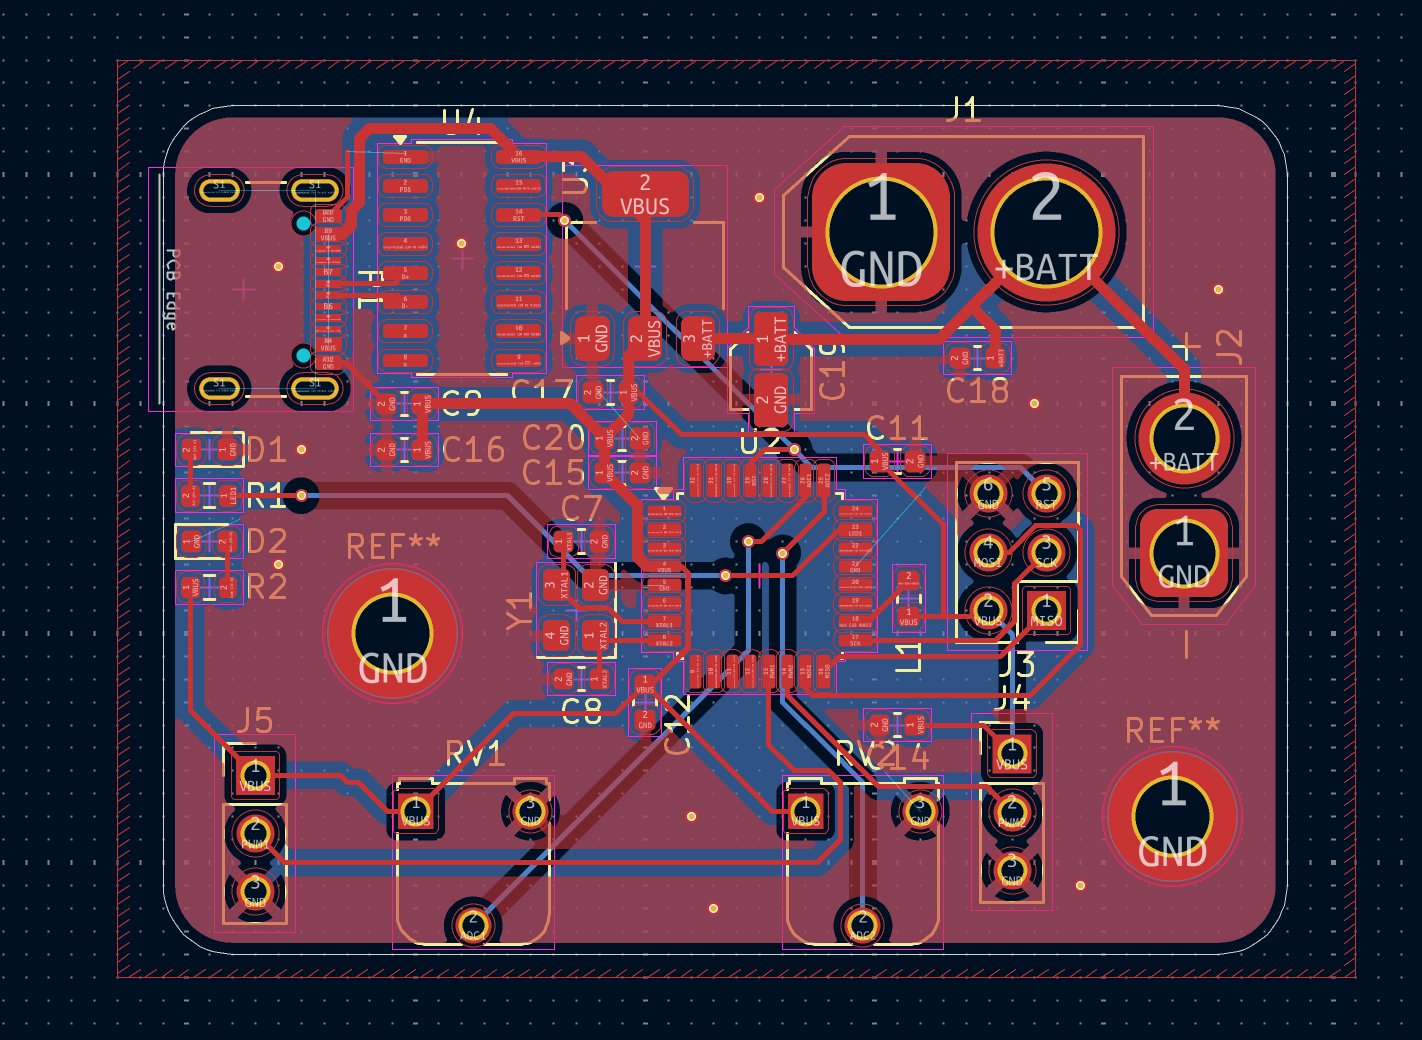
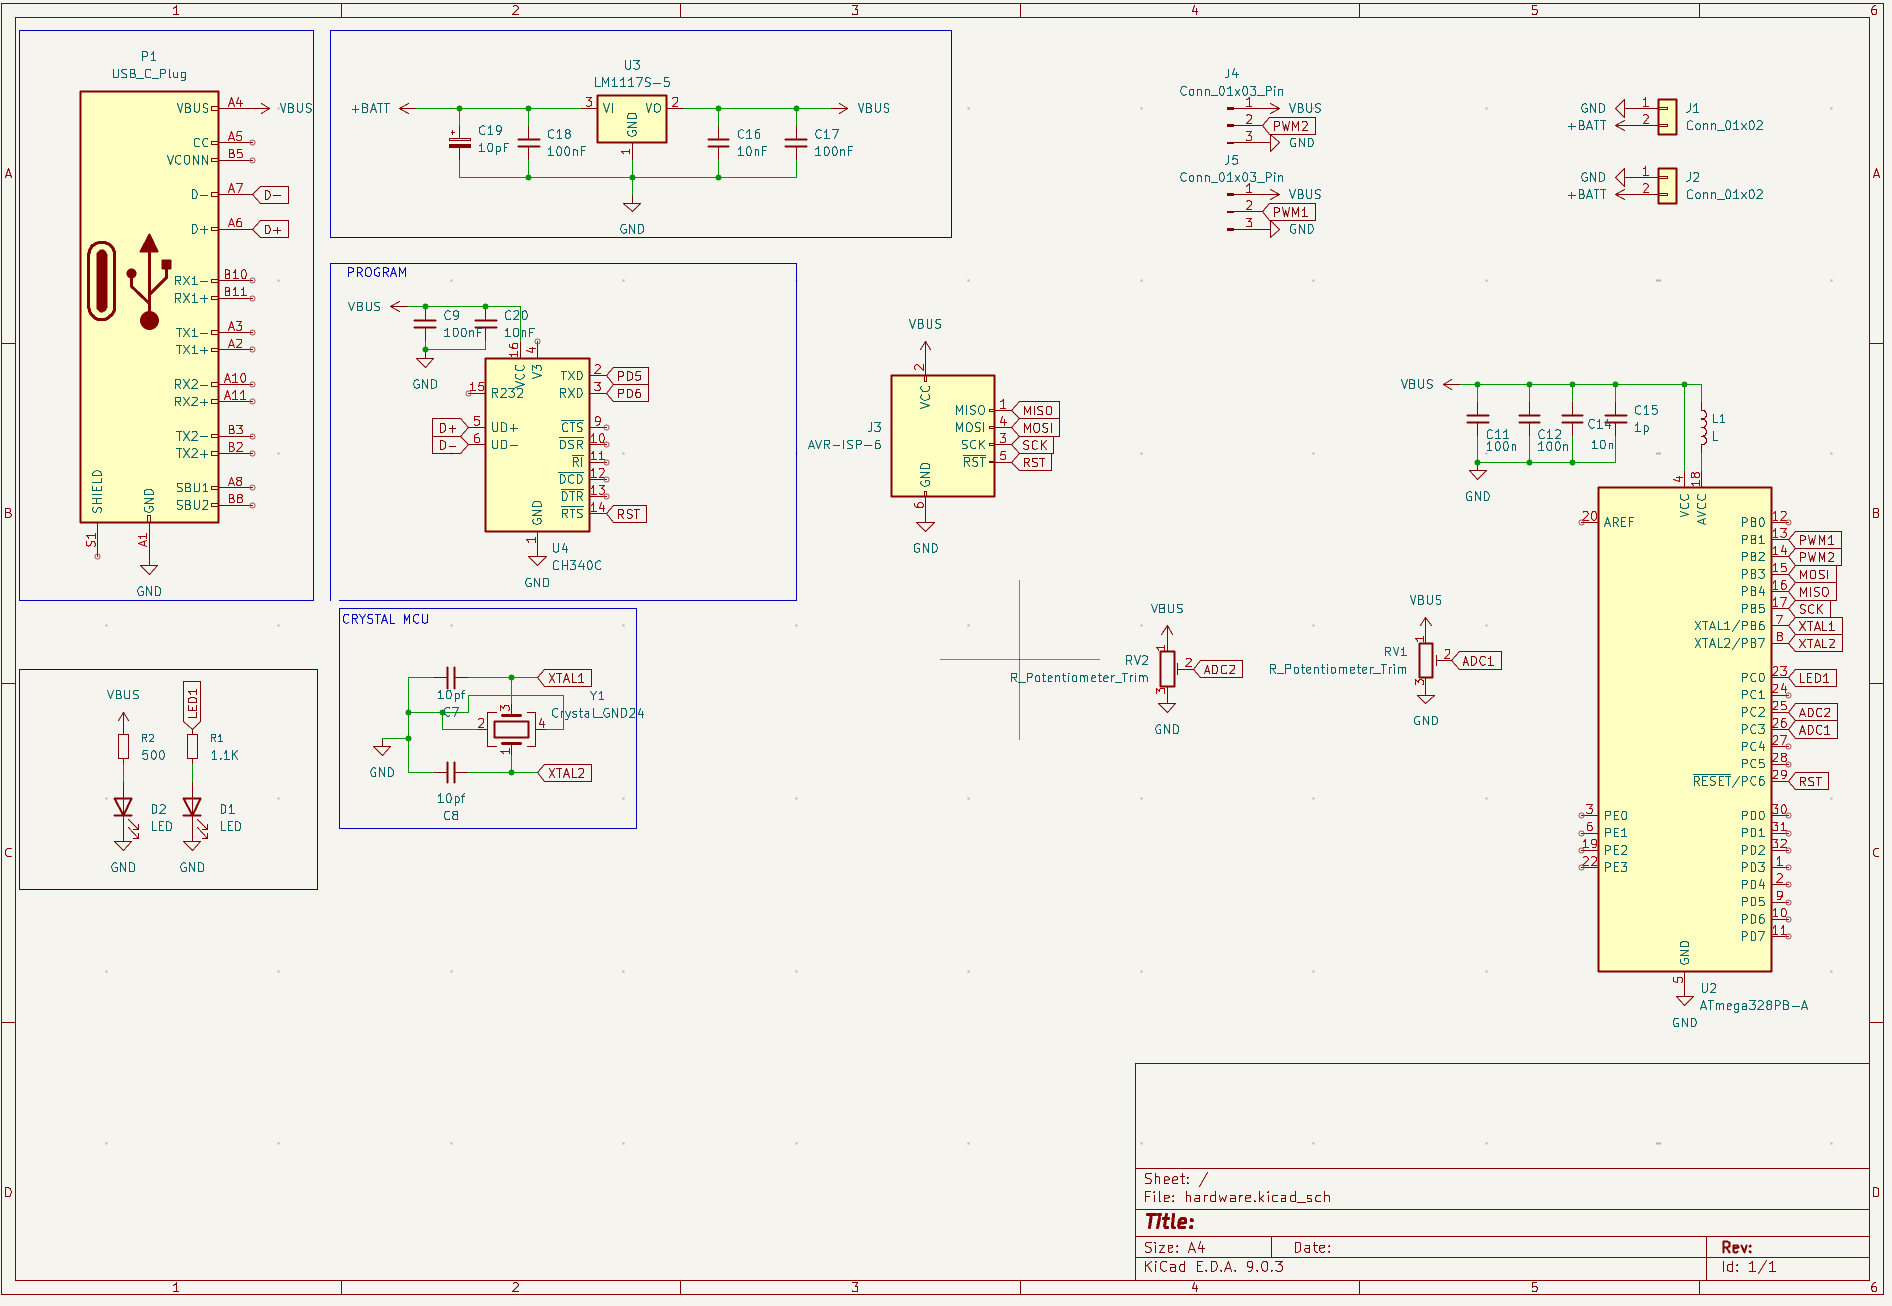
This board is built around the ATmega328P microcontroller (the same MCU used in Arduino Uno), making it extremely flexible and easy to program. Communication with the host PC is handled via an onboard CH340 UART-to-USB bridge, enabling simple plug-and-play connectivity over USB.
The board includes XT60 and XT30 connectors for safe and reliable power input, making it suitable for lab bench setups or battery-powered applications.
Dual Servo Control
Two independent PWM channels allow you to control and test two RC servos simultaneously.
Robust Power Delivery
USB-to-UART Interface
Microcontroller
Test Points & Expandability
| Connector | Function |
|---|---|
| XT60 | Primary power input (+BAT, GND) |
| XT30 | Secondary power option |
| USB-C | UART communication with PC |
| J3 | AVR-ISP programming header |
| J4 / J5 | Servo PWM outputs |
| Parameter | Value |
|---|---|
| Input Voltage | 6 – 12 V (recommended) |
| Logic Voltage | 5 V |
| PWM Frequency | ~50 Hz (standard RC servo) |
| MCU Clock | 16 MHz |
avrdude over ISP.This repository contains:
hardware.kicad_pcb)hardware.kicad_sch).kicad_pro, .kicad_prl)| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | 100nF | Capacitor_SMD:C_0603_1608Metric | C9, C17, C18 |
| 2 | 100n | Capacitor_SMD:C_0603_1608Metric | C11, C12 |
| 2 | 10nF | Capacitor_SMD:C_0603_1608Metric | C16, C20 |
| 2 | 10pf | Capacitor_SMD:C_0603_1608Metric | C7, C8 |
| 2 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4, J5 |
| 2 | LED | LED_SMD:LED_0603_1608Metric | D1, D2 |
| 2 | R_Potentiometer_Trim | Potentiometer_THT:Potentiometer_Runtron_RM-065_Vertical | RV1, RV2 |
| 1 | 1.1K | Resistor_SMD:R_0603_1608Metric | R1 |
| 1 | 10n | Capacitor_SMD:C_0603_1608Metric | C14 |
| 1 | 10pF | Capacitor_SMD:C_Elec_3x5.4 | C19 |
| 1 | 1p | Capacitor_SMD:C_0603_1608Metric | C15 |
| 1 | 500 | Resistor_SMD:R_0603_1608Metric | R2 |
| 1 | ATmega328PB-A | Package_QFP:TQFP-32_7x7mm_P0.8mm | U2 |
| 1 | AVR-ISP-6 | Connector_PinHeader_2.54mm:PinHeader_2x03_P2.54mm_Vertical | J3 |
| 1 | CH340C | Package_SO:SOIC-16_3.9x9.9mm_P1.27mm | U4 |
| 1 | Conn_01x02 | Connector_AMASS:AMASS_XT30U-F_1x02_P5.0mm_Vertical | J2 |
| 1 | Conn_01x02 | Connector_AMASS:AMASS_XT60-F_1x02_P7.20mm_Vertical | J1 |
| 1 | Crystal_GND24 | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y1 |
| 1 | L | Inductor_SMD:L_0603_1608Metric | L1 |
| 1 | LM1117S-5 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U3 |
| 1 | USB_C_Plug | Connector_USB:USB_C_Receptacle_GCT_USB4105-xx-A_16P_TopMnt_Horizontal | P1 |
The 29 most common of 31 parts.
It measures 49 × 37 mm and has 2 copper layers, 1.6 mm thick.
31 parts, built around the ATMEGA328PB-AU, CH340C and LM1117S-5.0. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the rmingon/servo-controller repository on GitHub, at the commit this page was made from: the board is hardware/hardware.kicad_pcb and its schematic hardware/hardware.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask rmingon before reusing the design.
Hansolini/Take-home-Maglev-lab
A small lab for students in control engineering to learn control topics at home!


jeffrey500/ServoBoard
A custom PCB that drives up to 4 PWM servos. The board uses the atmega328PB and has variable input and variable servo voltage using the LM2596S buck and AMS1117 LDO. The board also has 3 6n137 optocouplers.