2 layers19.4 × 21.4 mm
Xiao rp gpio adapter
phyreact/reactor
Robots that help AI sense and interact with the physical world.
2 parts

 phyreact/reactor
Robots that help AI sense and interact with the physical world.
Box carrier modules r2 is an open-source printed circuit board by phyreact, from the phyreact/reactor repository on GitHub. It is a 4-layer board of 103.7 × 93 mm with 61 parts on 111 nets, routed with 2,338 tracks and 202 vias.
It is built around the BOB-12009, B2B-PH-K-S and SSW-104-01-G-S, with the B2B-XH-A(LF)(SN), M50-3601242 and M20-9982046 among its other parts.


A world that can be seen, heard, and sensed.
Someone calls from across the room. A hand moves beside the camera. The surface under a device shifts. Each moment carries a cue about what is happening nearby.
We want to build machines that can notice those cues and respond in ways people understand. Reactor explores that idea through two devices: an expressive robot and a compact sensing hub. They share a Radxa ZERO 3W host and four-microphone audio, with different bodies and ways to interact.

| Donald Microduck | Mickey Hub |
|---|---|
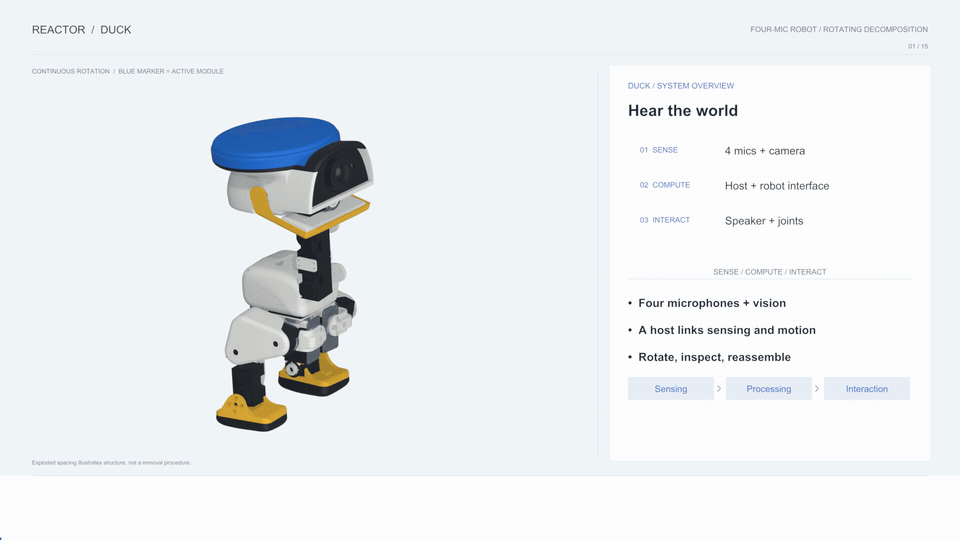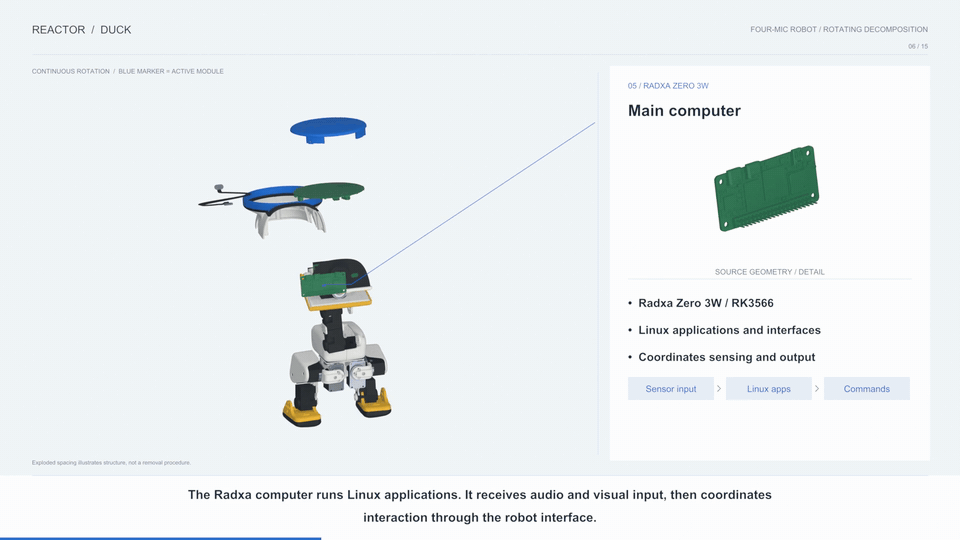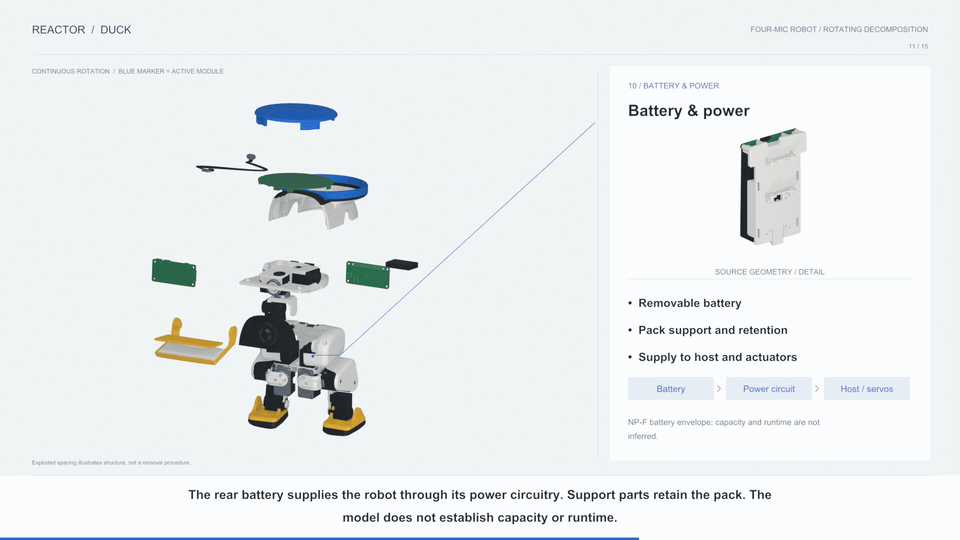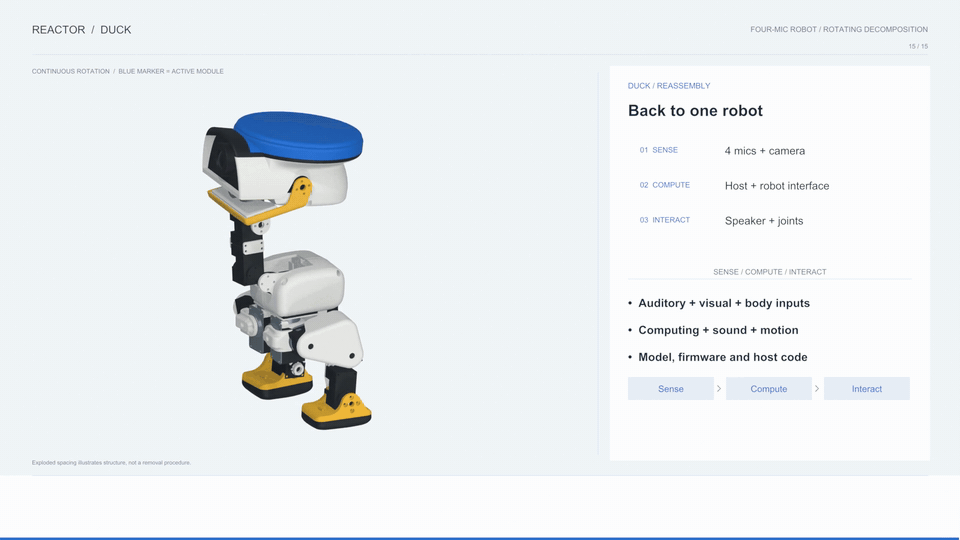 | 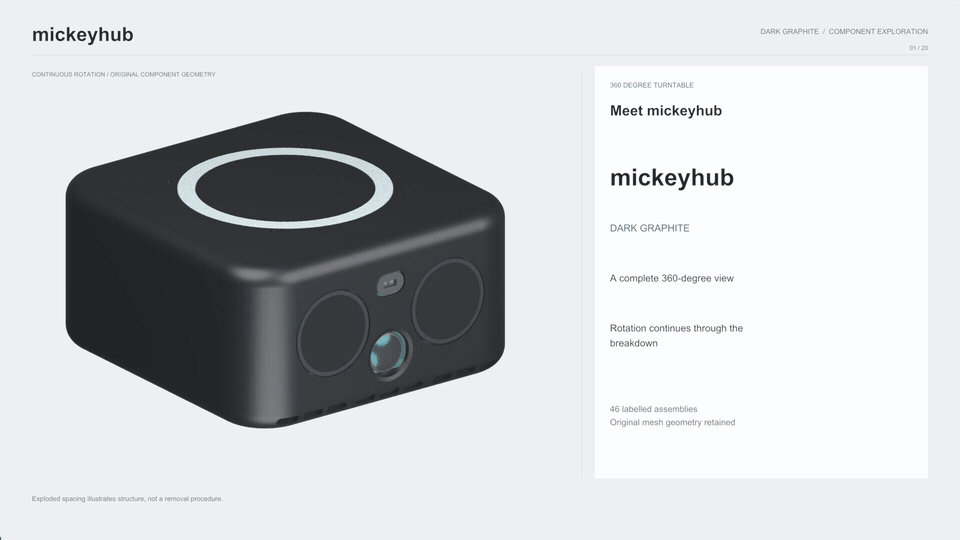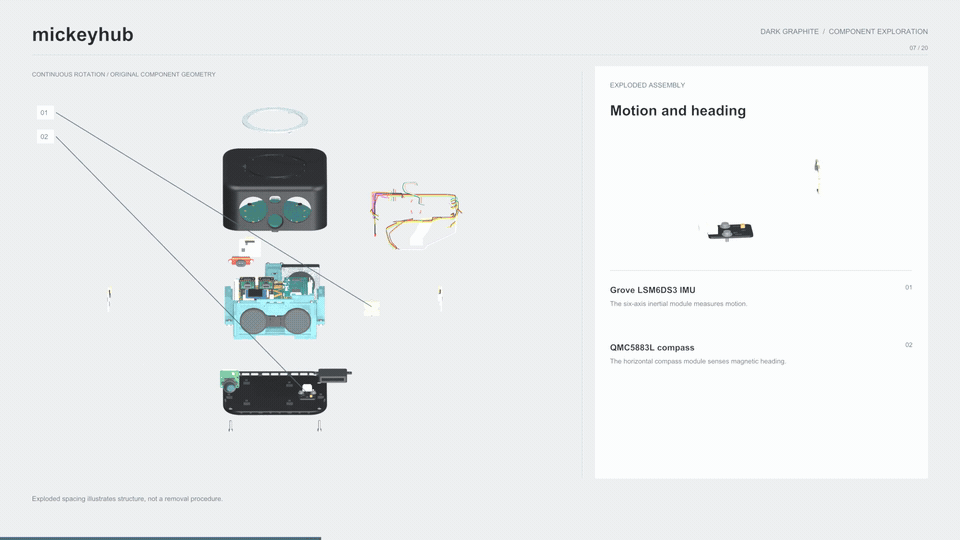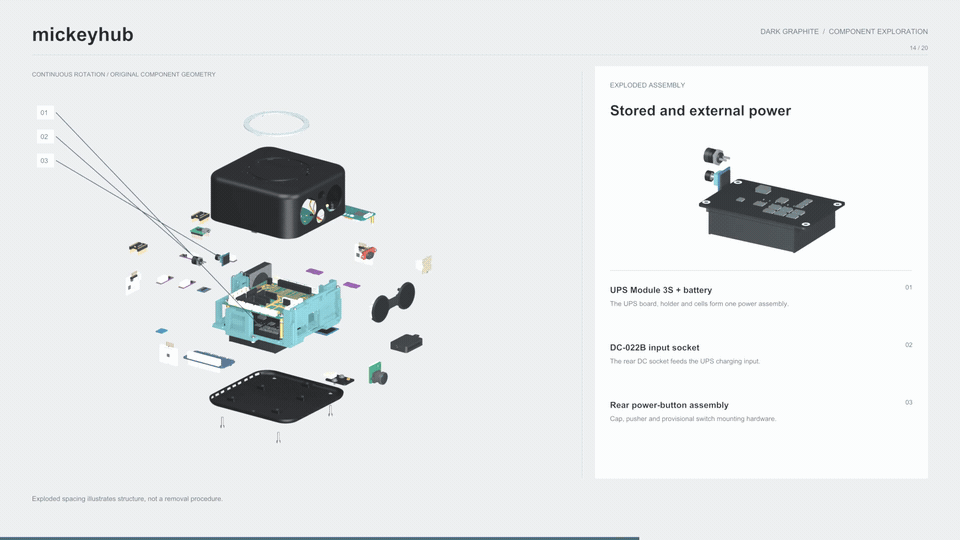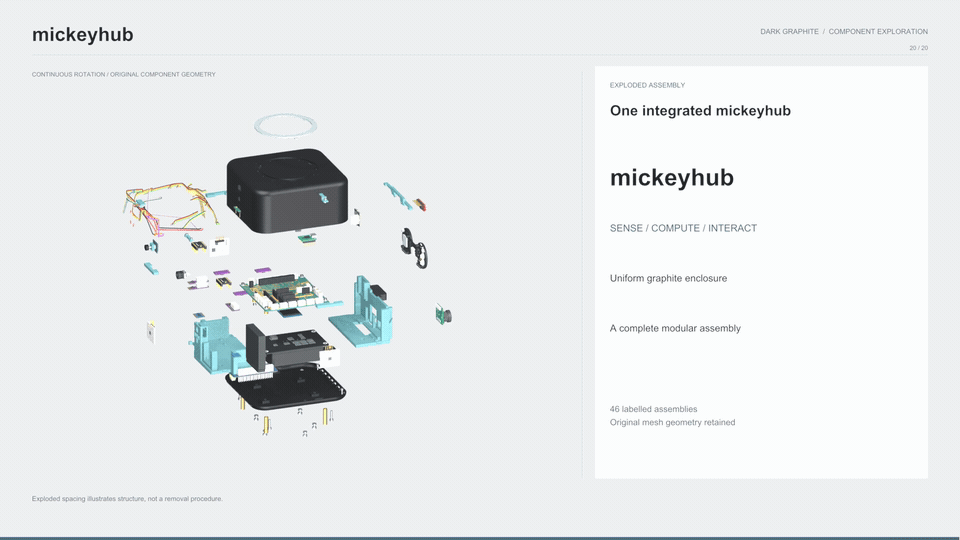 |
| Give listening a body. A small robot with four microphones, a camera, a speaker and 15 smart servos. | Bring perception together. Four microphones, three radars, a camera, depth sensing, motion sensors and dual displays. |
| Explore Donald Microduck → | Explore Mickey Hub → |
Each project has its own guide, animated previews, STL parts, one final assembled Blender model, firmware and build instructions. The GIFs above show the devices rotating, separating into modules and coming back together, with English explanations.
| Area | Donald Microduck | Mickey Hub |
|---|---|---|
| Hearing | Four-microphone ReSpeaker hardware; current firmware provides 16 kHz stereo processed audio. | Four-microphone ReSpeaker hardware and a speaker for audio experiments. |
| Perception | Camera and motion sensing in a moving robot. | Ultra-wide camera, 8 × 8 ToF depth sensing, three radar modules, six-axis IMU and compass. |
| Interaction | Speaker, expressive pose and 15 smart servos. | Glasses-like dual displays, speaker, light ring, controls and additional I/O. |
| Design files | One final assembled Blender model and 37 printable STL parts. | One final assembled Blender model, 15 printable STL parts, four fit samples and native KiCad projects. |
| Development | Firmware · Host tools · Simulation | Firmware · Electronics · Simulation |
These are evolving hardware projects. Sound-source localization, sensor fusion and autonomous responses are development goals. Each project guide distinguishes the supplied files and recorded checks from work that still needs assembled hardware testing.
Choose a project above. Its README introduces the device and points to the relevant files.
Retrieve the large models with Git LFS. Run these commands inside your checkout:
git lfs install --local
git lfs pull
Open an editable assembly. Start with Donald Microduck or Mickey Hub, then follow the project's build guide.
The repository includes firmware and application sources, native electronics,
manufacturing files, STL exports, one final assembled Blender file per project,
GIF previews and captions. Component GLBs, STEP references, intermediate design
files, separate animation scenes and full MP4 renders stay in the local
memory_backups/ directory, alongside render caches and conversation history.
They are excluded from commits and source archives.
Work on mechanical fit, audio processing, perception, firmware, host applications and interaction design is welcome. Identify the affected project, explain the change and include the checks needed to reproduce your result.
| Project | Terms |
|---|---|
| Donald Microduck | Preserves the official upstream Apache-2.0 software license and the upstream noncommercial, share-alike model notice. Upstream terms. |
| Mickey Hub | First-party designs and content: CC BY-NC 4.0. First-party firmware and tools: PolyForm Noncommercial 1.0.0. Additional permission allows up to 100 covered units sold per entity per calendar year without a license fee. License. |
Mickey Hub's limited commercial permission covers up to and including 100 devices or one-device kits sold by the same individual or legal entity each calendar year. Before selling the 101st unit, obtain separate written authorization from the Reactor maintainers. The complete grant defines the counting rules and third-party exclusions.
Original shared documentation and graphics use CC BY-NC 4.0. Third-party material retains its own terms. LICENSING.md defines the project scopes, commercial authorization and model exceptions; THIRD_PARTY.md records upstream sources.
For questions or commercial licensing, contact phyreact@gmail.com.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | UPS M2.5 / 3mm PTH / isolated 6.0mm copper | CompactMechanical:UPS_M2p5_PTH_3mm_Copper6p0_Isolated | MH_UPS1, MH_UPS2, MH_UPS3, MH_UPS4 |
| 2 | GND | box:COPPER_TEST_2MM | TP1, TP10 |
| 2 | MountingHole_2.7mm_M2.5_Pad | MountingHole_2.7mm_M2.5_Pad | H1, H3 |
| 1 | A5V | box:COPPER_TEST_1MM | TP2 |
| 1 | BAT | box:COPPER_TEST_1MM | TP13 |
| 1 | COMMON CTRL 5V LINK / TWO SHUNTS | box:Dual_Power_Shunt_2x02 | JP1 |
| 1 | EYES | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J15 |
| 1 | EYES 3V3 REFERENCE INPUT | Connector_JST:JST_PH_B2B-PH-K_1x02_P2.00mm_Vertical | J53 |
| 1 | FAN PWM / POLOLU 2990 | box:Pololu_2990_REAR_LANDS | M42 |
| 1 | FRONT BUTTON | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J19 |
| 1 | H5V | box:COPPER_TEST_1MM | TP3 |
| 1 | IMU | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J17 |
| 1 | LD2450 / FRONT LEFT | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J12 |
| 1 | LD2450 / FRONT RIGHT | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J13 |
| 1 | LD2450 / REAR LEFT | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J14 |
| 1 | LD2450 / REAR RIGHT | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J36 |
| 1 | M1 / 5V RELAY / ZERO + HAT | box:ZXC0073_28p08x8p55_FLUSH_SMD_PENDING | M1 |
| 1 | M16 / MAIN HOLD / LOAD QUALIFY | box:ZXC0073_28p08x8p55_FLUSH_SMD_PENDING | M16 |
| 1 | M17 / 5V RELAY / SEN0628 TOF | box:ZXC0073_28p08x8p55_FLUSH_SMD_PENDING | M17 |
| 1 | M2 / 5V RELAY / FOUR LD2450 | box:ZXC0073_28p08x8p55_FLUSH_SMD_PENDING | M2 |
| 1 | MUX / FRONT PAIR TX GATE | box:UART_MUX_SOCKET_16_USER_PINOUT | J28 |
| 1 | MUX / REAR PAIR TX GATE | box:UART_MUX_SOCKET_16_USER_PINOUT | J29 |
| 1 | OLED / PARALLEL / SCREEN UP | box:SSW_104_01_G_S_OLED_Parallel | J35 |
| 1 | PANEL START / MOMENTARY NO | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J51 |
| 1 | RADV | box:COPPER_TEST_1MM | TP11 |
| 1 | RELAY_EN | box:COPPER_TEST_1MM | TP9 |
| 1 | RP / Seeed XIAO SOCKET14 | box:Seeed_XIAO_14pin_Socket | J10 |
| 1 | RP D1 / ZERO RELAY | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J47 |
| 1 | RP EDGE GPIO D0-D10 / AUX NC | box:Harwin_M50-3601242_2x12_P1.27_SMT_CENTERED | J52 |
| 1 | RP I2C SHARED | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J39 |
| 1 | RP UART1 | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J41 |
| 1 | RP3V3 | box:COPPER_TEST_1MM | TP5 |
| 1 | Radxa ZERO 3W SOCKET | box:Zero_socket40_PROVISIONAL | J5 |
| 1 | S3 / Seeed XIAO SOCKET14 | box:Seeed_XIAO_14pin_Socket | J7 |
| 1 | S3 D2 D3 / FRONT LEFT UART | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J46 |
| 1 | S3 EDGE GPIO D0-D10 / AUX NC | box:Harwin_M50-3601242_2x12_P1.27_SMT_CENTERED | J50 |
| 1 | S3 I2C | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J34 |
| 1 | S3 UART A | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J40 |
| 1 | S3V3 | box:COPPER_TEST_1MM | TP6 |
| 1 | SEN0628 / UART4 | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J16 |
| 1 | SPARKFUN BOB-12009 / 4CH BSS138 | box:SparkFun_BOB12009_Module_SolderLands | M15 |
| 1 | UPS BAT OUT | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J42 |
| 1 | UPS I2C STATUS | box:NS-Tech_Grove_1x04_P2mm_Vertical_J3_SilkClearance | J3 |
| 1 | UPS REGULATED 5V | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J1 |
| 1 | UPS SWITCH LOOP | Connector_JST:JST_XH_B2B-XH-A_1x02_P2.50mm_Vertical | J44 |
| 1 | Z3V3 | box:COPPER_TEST_1MM | TP4 |
| 1 | ZERO EYES UART5 / ADUM1201 | box:LA161062_ADuM1201_REAR_LANDS | M21 |
| 1 | ZERO FAN / NOCTUA 5V PWM / 4P | Connector:FanPinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | ZERO GPIO COPY / FULL40 1:1 | box:HAT_P4_M20_9982046_2x20 | J33 |
| 1 | ZERO I2C4 | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J37 |
| 1 | ZERO RP UART9 | Connector:NS-Tech_Grove_1x04_P2mm_Vertical | J38 |
| 1 | ZERO RP UART9 / ADUM1201 | box:LA161062_ADuM1201_REAR_LANDS | M20 |
| 1 | ZERO TOF UART4 / ADUM1201 | box:LA161062_ADuM1201_REAR_LANDS | M22 |
| 1 | ZERO socket support / UNQUALIFIED | MH_ZERO | |
| 1 | ZRX | box:COPPER_TEST_1MM | TP8 |
| 1 | ZTX | box:COPPER_TEST_1MM | TP7 |
It measures 103.7 × 93 mm and has 4 copper layers, 1.6 mm thick.
61 parts, built around the BOB-12009, B2B-PH-K-S, SSW-104-01-G-S and B2B-XH-A(LF)(SN). The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the phyreact/reactor repository on GitHub, at the commit this page was made from: the board is mickeyhub/electronics/kicad/box_carrier_modules_r2.kicad_pcb and its schematic mickeyhub/electronics/daughterboards/adapter_rp/xiao_rp_gpio_adapter.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask phyreact before reusing the design.
phyreact/reactor
Robots that help AI sense and interact with the physical world.

phyreact/reactor
Robots that help AI sense and interact with the physical world.


agtbaskara/game-boy-pico-link-board
An Open-Source USB to Gameboy Link Cable Adapter for Raspberry Pi Pico


VincentKobz/diy-weather-station
The goal is to build from scratch a small intelligent weather station that can be connected to IOT networks.


hselomein/Car-LED-Controller
This is a private repo for my car led project