4 layers305 × 208.3 mm
 paradise-fi/RoFI42
Distributed Metamorphic Robots
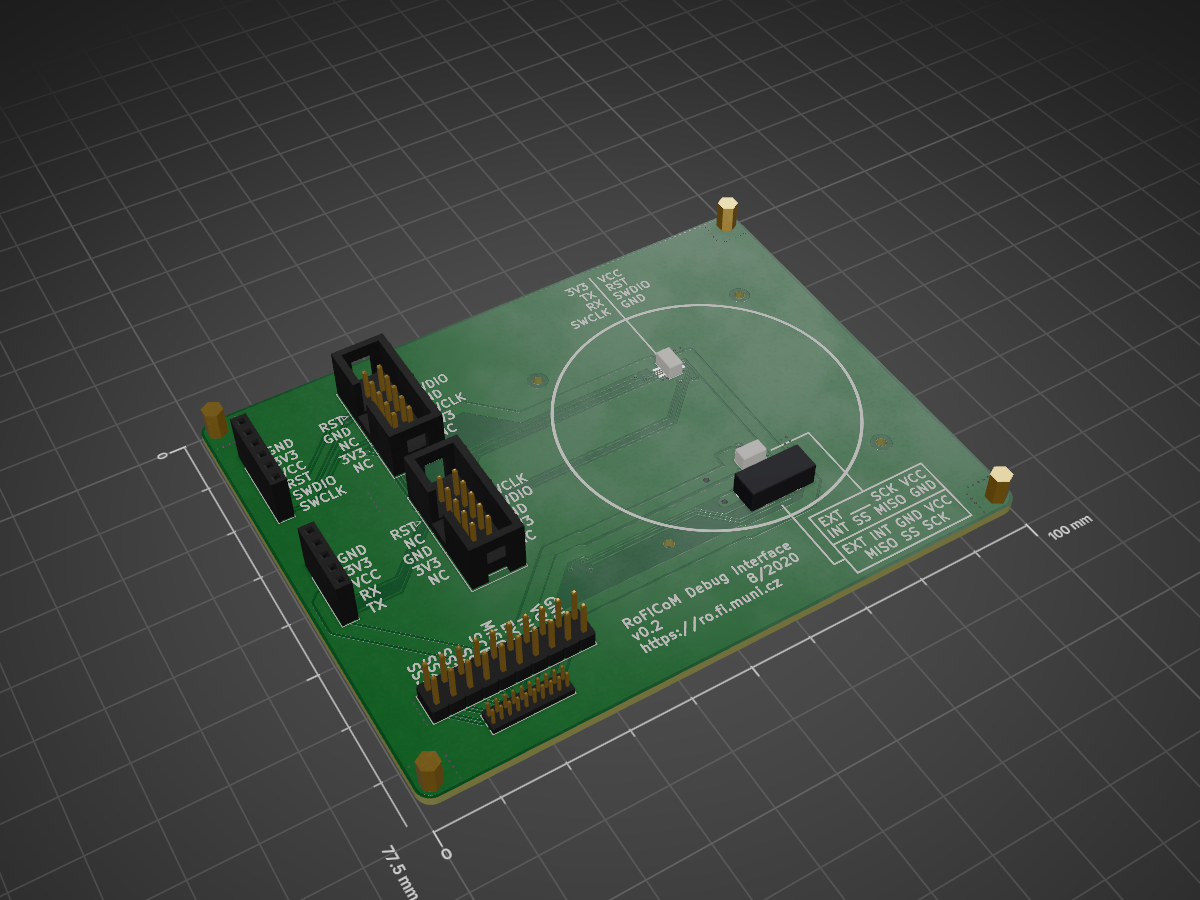
Debug interface is an open-source printed circuit board by paradise-fi, from the paradise-fi/RoFI repository on GitHub. It is a 2-layer board of 100 × 77.5 mm with 17 parts on 16 nets, routed with 213 tracks and 102 vias.
It belongs with the robots and motor control and interfaces and adapters boards of this library.
Project website: https://rofi.fi.muni.cz/
RoFI is a platform of modular robots developed at Faculty of Informatics at Masaryk University. The platform is designed for building larger robots (RoFIbots) from a small number of module types.
The modules of the platform can connect together using RoFI dock. Mechanically connected modules can communicate over TCP/IP and share power.
For an in-depth description of the RoFI platform see the project website.
If you are interested in building your modules or development of the platform, please refer to the project documentation: https://paradise-fi.github.io/RoFI/.
You will find all the necessary information about building and using the project there. For a brief reminder of the compilation process, see:
$ source setup.sh <Configuration> # Setup your shell for compiling the
                                  # project in a configuration
$ rcfg --list                     # Show available compilation suites
$ rcfg <suiteName>                # Configure given suite
$ rmake --all                     # Compile all configured suites or...
$ rmake <targetName>              # Compile given target or...
$ rmake tools/ # Compile all configured targets from source prefix| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | rofi:ThreadedHole-M2 | H1, H2, H3, H4 |
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2 | H5, H6, H7, H8 |
| 1 | Conn_01x07 | rofi:pogo_pads_4_3 | J9 |
| 1 | RoFICoM | rofi:molex-505004-0812 | J6 |
| 1 | RoFICoM-debug | rofi:molex-505004-0812 | J4 |
| 1 | ST-Link | Connector_PinSocket_2.54mm:PinSocket_1x06_P2.54mm_Vertical | J5 |
| 1 | ST-Link A | Connector_IDC:IDC-Header_2x05_P2.54mm_Vertical | J1 |
| 1 | ST-Link B | Connector_IDC:IDC-Header_2x05_P2.54mm_Vertical | J3 |
| 1 | UART | Connector_PinSocket_2.54mm:PinSocket_1x05_P2.54mm_Vertical | J2 |
| 1 | system-1.27 | Connector_PinHeader_1.27mm:PinHeader_2x10_P1.27mm_Vertical | J8 |
| 1 | system-2.54 | Connector_PinHeader_2.54mm:PinHeader_2x10_P2.54mm_Vertical | J7 |
It measures 100 × 77.5 mm and has 2 copper layers, 1.6 mm thick.
17 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the paradise-fi/RoFI repository on GitHub, at the commit this page was made from: the board is hardwareModules/RoFICoM/hardware/debug_interface/debug_interface.kicad_pcb and its schematic hardwareModules/RoFICoM/hardware/control_board/bi-switch.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask paradise-fi before reusing the design.


hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

DDeGonge/OS-ARM
This arm is not industrial and it will not be fast, but that is not my goal. But it will hopefully be a very nice looking arm fully capable of 6dof motion, cheap enough to keep it accessable but capable enough to…

