Skip to the content
PCBKitNew board
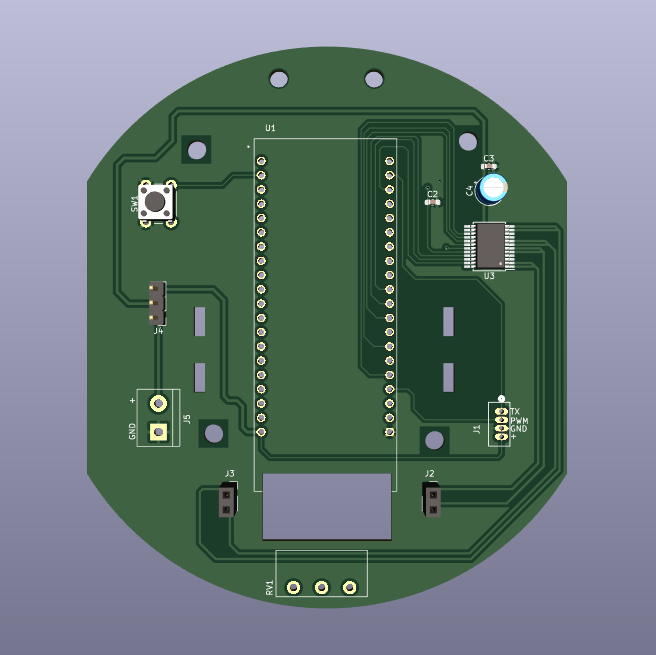
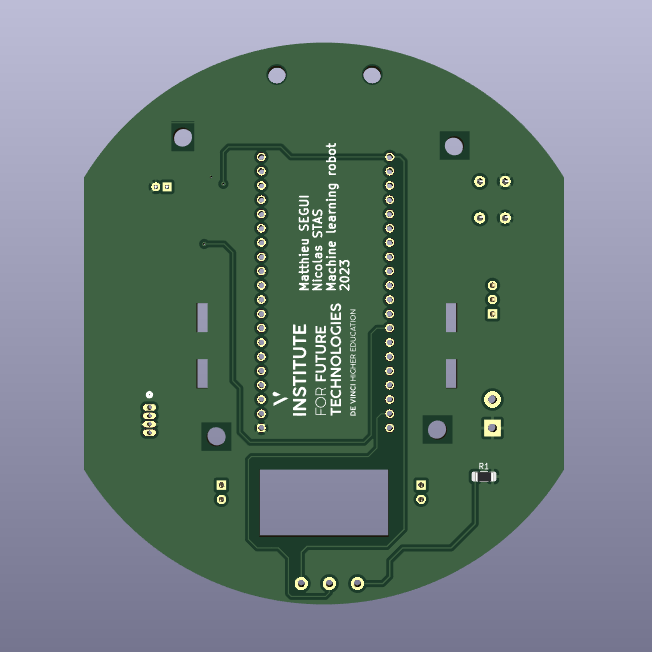
2 layers85.4 × 100 mmMl robot, the printed circuit board in 3D

A machine learning bot.

Size
85.4 × 100 mm
Copper layers
2
Thickness
1.6 mm
Parts
16
Nets
45
Pads
90
Tracks, vias
231, 3
Pours
9
Routed
Yes
KiCad
KiCad 7 (file 20221018)
Created
5 Oct 2023
Updated
18 Dec 2024

Overview

Ml robot is an open-source printed circuit board by matthieu-sgi, from the matthieu-sgi/machine_learning_robot repository on GitHub. It is a 2-layer board of 85.4 × 100 mm with 16 parts on 45 nets, routed with 231 tracks and 3 vias.

It is built around the ESP32-S3-DEVKITC-1-N8R2. Its parts include 5 connectors, 3 capacitors, 2 ICs and 1 switch. It belongs with the robots and motor control boards and the ESP32 boards of this library.

Main components

1

README

README.md

Machine learning robot

The machine learning bot is a project of making an OpenSource robot that will be able to learn from its environment and adapt to it using machine learning.

The robot is based on a FREENOVE ESP32 S3 MCU and its camera. It also includes a LIDAR. The mechanical part is based on a Adafruit 3216 chassis.

Electronics

Electronics components

The robot is based on a FREENOVE ESP32 S3.

In addition to the included camera, we bought this camera. The ribbon cable is longer than the included one and it allows to position it on the front of the robot.

The LIDAR used is a LD06 from innomaker (datasheet).

PCB

The chassis chosen is very tiny. It includes only two frame for two stages. To gain space, we decided to build and make a full PCB stage. Allowing the robot to go from 2 to 3 stages.

The PCB project can be found in the pcb folder.

3D view of the PCB:

Front 3D viewBack 3D view

Parts

16
QtyValueFootprintReferences
2100nFCapacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolderC2, C3
1100kΩpotentiometer_custom:Potentiometer_Piher_PC-16_Single_HorizontalRV1
110uCapacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolderC1
1ESP32-S3-DEVKITC-1-N8R2custom_esp32:XCVR_ESP32-S3-DEVKITC-1-N8R2U1
1LOGOift_logo:logo_20G***
1Motor1Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_VerticalJ2
1Motor2Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_VerticalJ3
1SW_PushButton_Switch_THT:SW_PUSH_6mmSW1
1TB6612FNGPackage_SO:SSOP-24_5.3x8.2mm_P0.65mmU3
1ext_powerTerminalBlock:TerminalBlock_bornier-2_P5.08mmJ5
1jmp_alimConnector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_VerticalJ4
1lidar_connB4B-ZR_LF__SN_:CONN_B4B-ZR_LF__SN__JSTJ1

The 13 most common of 16 parts.

Questions

How big is the Ml robot PCB?

It measures 85.4 × 100 mm and has 2 copper layers, 1.6 mm thick.

What parts does the Ml robot use?

16 parts, built around the ESP32-S3-DEVKITC-1-N8R2. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.

Where can I download the Ml robot KiCad files?

From the matthieu-sgi/machine_learning_robot repository on GitHub, at the commit this page was made from: the board is PCB/ml_robot.kicad_pcb and its schematic PCB/ml_robot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.

Can I use the Ml robot design in my own project?

Its repository states no licence, so its author keeps all rights: ask matthieu-sgi before reusing the design.

Similar boards

  • 4 layers135 × 84 mmStepper with TMC2209 controller board V1, the printed circuit board in 3D

    Stepper with TMC2209 controller board V1

    JasonHEngineering/DIY-Robot-Arm-V3

    1) Along with using with TMC2209 motor drivers, I have removed R8, R15, R16, R17, R18, R19 because the R value was accidentally too high. I have shorted R8, R16, R17, and left open R15, R18, R19.

    95 parts2
  • 2 layers200 × 130 mmEsp32s3 wmlta, the printed circuit board in 3D

    Esp32s3 wmlta

    riezky-gitH/SIMPAS-BOILER

    > 📖 Guidebook proyek — tautan guidebook baru akan ditambahkan di sini.

    129 parts2MIT
  • 2 layers100 × 50 mmVga test, the printed circuit board in 3D

    Vga test

    cfrankb/ESP32-S3-VGA-ADAPTOR

    VGA ESP32-S3 Breakout board for WROOM1- DevKit

    38 parts1
  • 4 layers100 × 79 mmESP32 Interface, the printed circuit board in 3D

    ESP32 Interface

    dennowiggle/ESP32_Interface

    Facilitate learning the Z80 Retro! hardware and software.

    114 parts1LGPL-2.1
  • 2 layers126.2 × 143.6 mmSciencepcb, the printed circuit board in 3D

    Sciencepcb

    Sidbit08/ABEX_PCB_v1

    A custom ESP32-S3-based PCB designed in KiCad for automated soil sample analysis, featuring drivers and interfaces for environmental sensors, peristaltic pumps, and auger drilling actuators.

    100 parts1
  • 2 layers102 × 45 mmHELPStat V2, the printed circuit board in 3D

    HELPStat V2

    stevfu/eis_capstone

    Utilization of Electrochemical Impedance Spectroscopy for the Detection of Drugs

    51 parts1MIT
  • 2 layers156.4 × 71.6 mmDelta 2.0, the printed circuit board in 3D

    Delta 2.0

    YesidAlmanzaGamba/Thesis-Flight-Controller-Fixed-Wing

    This thesis addresses the critical need for efficient data management and operational control in fixed-wing UAVs, targeting the gaps in current commercial flight controllers.

    43 parts1