4 layers136.2 × 25 mm
 MarkusVLA/robot-controller3
150g combat robot controller PCB and firmware
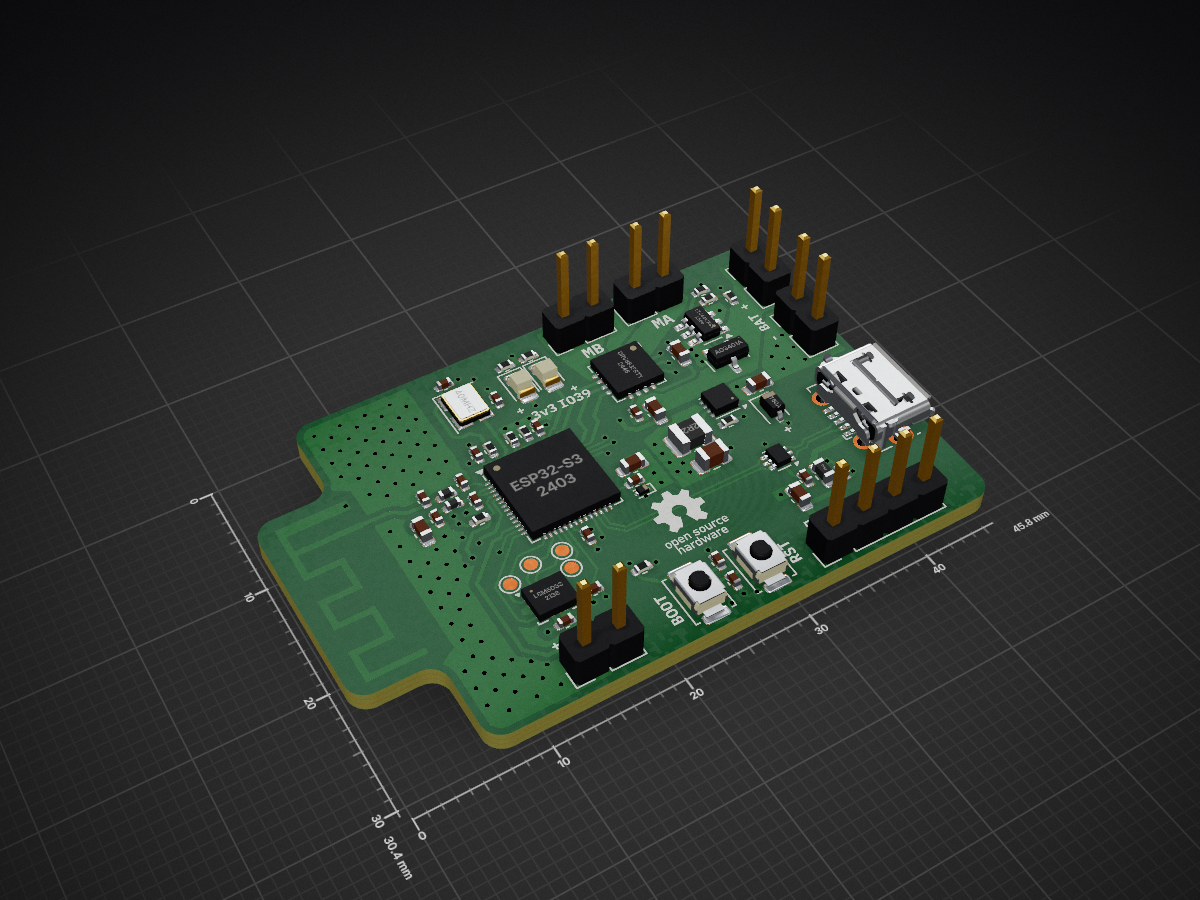
Battle bot pcb is an open-source printed circuit board by MarkusVLA, from the MarkusVLA/robot-controller repository on GitHub, published under the Apache-2.0 licence. It is a 4-layer board of 45.8 × 30.4 mm with 66 parts on 74 nets, routed with 430 tracks and 159 vias.
It is built around the ESP32-S3, DRV8833RTYR and TPS62172DSG, with the LSM6DS3, USBLC6-2P6 and AO3401A among its other parts. Its parts include 24 capacitors, 11 resistors, 7 connectors, 6 ICs and 4 diodes. It belongs with the robots and motor control and radio and wireless boards and the ESP32 boards of this library.


ESP32-S3 based robot controller designed for combat robots in the 150g weight class
The controller can control 2 DC-motors for vehicle movement and an ESC for the main weapon. The board also embeds a 3-axis gyroscope and accelerometer which can be used to improve vehicle handling or detect when the robot is flipped. Wireless control is enabled through an integrated 2.4GHz PCB-antenna supporting both WiFi and Bluetooth.
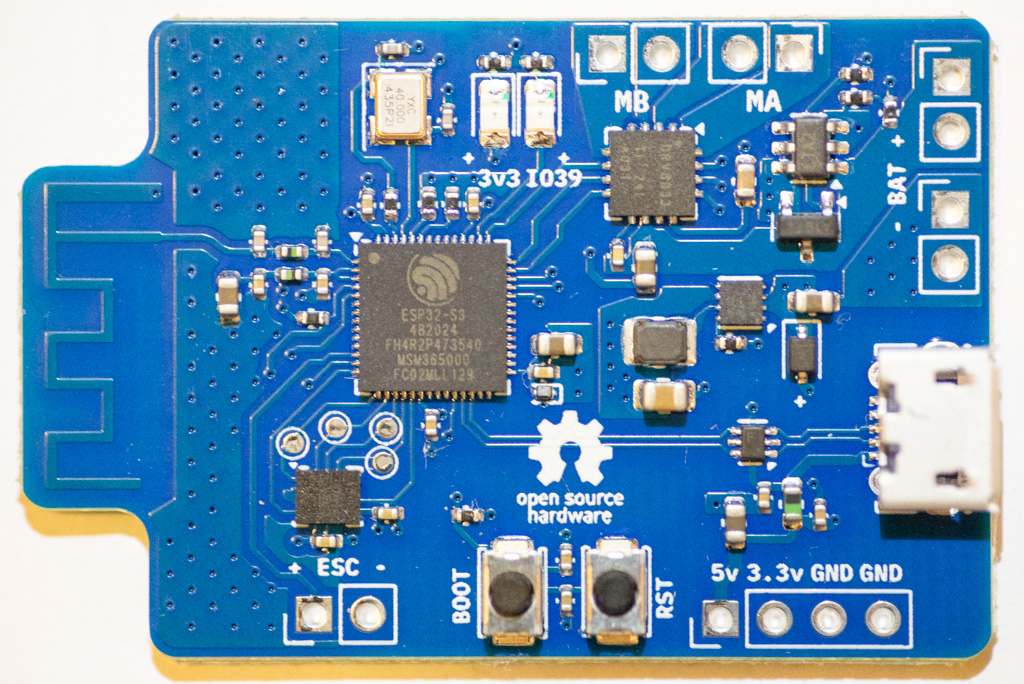
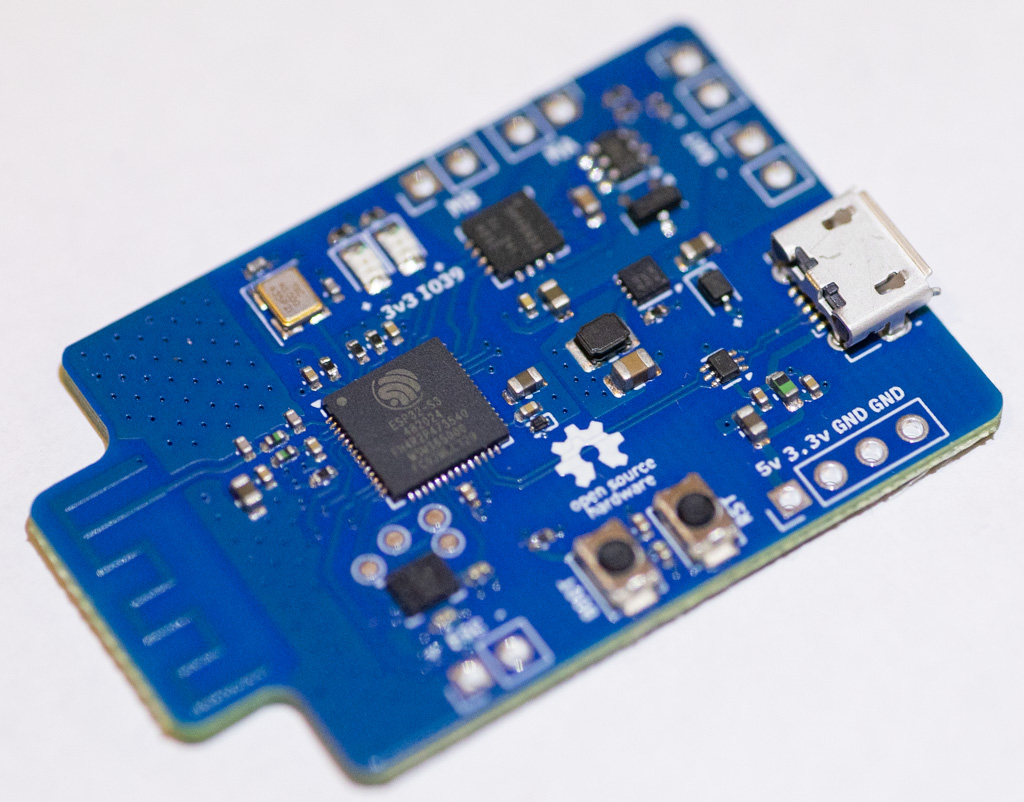
The esp32 firmware is being developed in C using the ESP-IDF framework. Installation and build instructions from: ESP-IDF API reference
| Qty | Value | Footprint | References |
|---|---|---|---|
| 12 | 100n | Capacitor_SMD:C_0402_1005Metric | C1, C2, C8, C9, C13, C14, C30, C32, C33, C35, C36, C37 |
| 5 | 10k | Resistor_SMD:R_0402_1005Metric | R2, R7, R8, R13, R14 |
| 5 | 10u | Capacitor_SMD:C_0603_1608Metric | C5, C10, C12, C34, C39 |
| 5 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J3, J4, J5, J6, J10 |
| 4 | TestPoint | TestPoint:TestPoint_Pad_D1.0mm | TP1, TP2, TP3, TP4 |
| 2 | 1k | Resistor_SMD:R_0402_1005Metric | R1, R5 |
| 2 | 2.2n | Inductor_SMD:L_0402_1005Metric | L5, L6 |
| 2 | 22p | Capacitor_SMD:C_0402_1005Metric | C27, C28 |
| 2 | 3.3p | Capacitor_SMD:C_0402_1005Metric | C29, C31 |
| 2 | LED | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D1, D4 |
| 1 | 10 | Resistor_SMD:R_0402_1005Metric | R12 |
| 1 | 100k | Resistor_SMD:R_0402_1005Metric | R4 |
| 1 | 10n | Capacitor_SMD:C_0402_1005Metric | C7 |
| 1 | 15k | Resistor_SMD:R_0402_1005Metric | R6 |
| 1 | 2.2n | Inductor_SMD:L_0603_1608Metric | L2 |
| 1 | 2.2u | Inductor_SMD:L_1008_2520Metric | L1 |
| 1 | 2.2u | Capacitor_SMD:C_0603_1608Metric | C11 |
| 1 | 22u | Capacitor_SMD:C_0805_2012Metric | C6 |
| 1 | 40MHz | Crystal:Crystal_SMD_3225-4Pin_3.2x2.5mm | Y2 |
| 1 | 470k | Resistor_SMD:R_0402_1005Metric | R3 |
| 1 | AO3401A | Package_TO_SOT_SMD:SOT-23 | Q1 |
| 1 | Antenna_Shield | RF_Antenna:Texas_SWRA117D_2.4GHz_Left | AE2 |
| 1 | BAT60A | Diode_SMD:D_SOD-323 | D3 |
| 1 | Boot | Button_Switch_SMD:SW_Push_SPST_NO_Alps_SKRK | SW4 |
| 1 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J2 |
| 1 | DRV8833RTY | Package_DFN_QFN:Texas_RTY_WQFN-16-1EP_4x4mm_P0.65mm_EP2.1x2.1mm_ThermalVias | U5 |
| 1 | ESP32-S3 | Package_DFN_QFN:QFN-56-1EP_7x7mm_P0.4mm_EP5.6x5.6mm | U7 |
| 1 | LOGO | LOGO | G*** |
| 1 | LSM6DS3 | Package_LGA:LGA-14_3x2.5mm_P0.5mm_LayoutBorder3x4y | U1 |
| 1 | LTC4412xS6 | Package_TO_SOT_SMD:TSOT-23-6 | U2 |
| 1 | Reset | Button_Switch_SMD:SW_Push_SPST_NO_Alps_SKRK | SW3 |
| 1 | SZESD9B5.0ST5G | Diode_SMD:D_SOD-923 | D5 |
| 1 | TPS62172DSG | Package_SON:WSON-8-1EP_2x2mm_P0.5mm_EP0.9x1.6mm_ThermalVias | U4 |
| 1 | USBLC6-2P6 | Package_TO_SOT_SMD:SOT-666 | U3 |
| 1 | USB_B_Micro | Connector_USB:USB_Micro-B_Molex-105017-0001 | J1 |
It measures 45.8 × 30.4 mm and has 4 copper layers, 1.6 mm thick.
66 parts, built around the ESP32-S3, DRV8833RTYR, TPS62172DSG and LSM6DS3. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the MarkusVLA/robot-controller repository on GitHub, at the commit this page was made from: the board is PCB/Battle_bot_pcb.kicad_pcb and its schematic PCB/Battle_bot_pcb.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the Apache-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

SkyRizzAI/SkyRizz-ESPSOL
An open-hardware, coin-sized ESP32-S3 development board with an on-board secure element, 6-axis IMU, PDM microphone, buzzer, USB-C, and Li-Po charging — all on a 40.6 mm (1.6") round, 2-layer PCB.


sthabisoslushaba/Flight-Controller-Design-2025
KiCad project for a drone flight controller based on an STM32 microcontroller

aeonSolutions/AeonLabs-AI-Volvo-MKII-Open-Hardware
Volvo MKII Open Hardware

aeonSolutions/AeonLabs-HomeAutomation-Bed-Sheet-EMF-Protection-for-Better-Health-Sleep
Bed Sheet EMF Protection for Better Health & Sleep

C-monC/Drone-simluation
Experimenting with reinforcement learning for drone control.
