

2 layers52 × 36 mm
CyphalPicoBase CAN
generationmake/CyphalPicoBase-CAN
Board for the Raspberry Pi Pico to connect via CAN using OpenCyphal and UCANPHY Micro
62 parts5CERN-OHL-W-2.0

 marinecircuits/kicad-template
Template for my KiCad projects
Template is an open-source printed circuit board by marinecircuits, from the marinecircuits/kicad-template repository on GitHub. It is a 2-layer board of 40 × 22.5 mm with 4 parts on 3 nets, routed with 24 tracks and 5 vias.
It is built around the BSS138 and MBR0530-TP. Its parts include 1 resistor, 1 diode, 1 transistor and 1 connector.
mkdir new-prorject && cd new-projectcurl -L https://github.com/marinecircuits/kicad-template/archive/refs/heads/main.tar.gz | tar -xz --strip-components=1python3 -m venv .venv && source .venv/bin/activate && pip install -r requirements.txtpython3 scripts/setup_template.pygit init . && git add .pre-commit install --hook-type commit-msgThese variables are relevant for this template / workflow:
${ISSUE_DATE}: the release PR workflow will update this with the current date, in the YYYY-MM-DD format (the only date format you should ever use by the way). It is committed and added in the PR as a change${REVISION}: the release PR will update this with the git tag (not 100% true, the git tag will be only created one the PR is merged into main, but the result is the same). It is committed and added in the PR as a change. This field will have +! appended if it's not a released version.${COMMENT9}: before kibot is invoked on github, this variable is updated with the short git hash from git rev-parse --short HEAD. It is committed and added in the PR as a change${COMMENT8}: This contains the project name. It is not updated automatically, you should set it once at the beginning of the project.It follows the semantic versionin approach. Schematics and PCB always have the same version. Anything breaking functional interfaces will be a breaking change which increments the major version. This includes board shape, connector position. TBD: will adding functionality without breaking interfaces just increment the minor version? Difficult to say if adding a connector will interfere with an existing case or other mechanical constraints. Changes in schematics which do not affect anything electrical (documentation, re-organize wires) will increment a patch. Changes in schematics which affect the value of a component, new connections, removal of components will increment a minor version.
This is a property of the BOM. At the moment variants are not fully supported (or better: only one variant is fully supported). VARIANT.md lists all the different variants with a textual description with the differences with respect to variant 1.
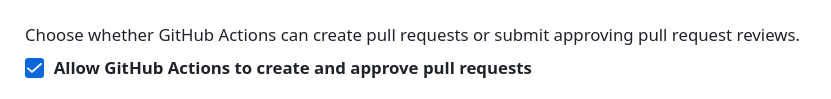
In github you must allow actions to create pullrequest for this workflow to be working.
Under Settings, Actions, General this settings must be enabled. If greyed out, it must be enabled at the organization level.
During daily work, the user branches off from main, makes changes, commits them, pushes to github, opens a PR, and merges the changes back to main. It is important to commit using the commitizen commit format, otherwise the whole versioning will not make sense. Checkout the documentation.
When a PR to main is opened, the jobs inside .github/worflows/pullrequest.yml get triggered.
The worflow will call .github/workflows/module-kibot.yml, which generates all the files needed for production.
In kibot.yaml the output files can be tweaked. The most important thing is to have dont_stop set to false under preflight in erc and drc, such that the workflow will fail and nothing broken is merged into main.
A release is started by invoking the Create Release PR Action. This will trigger the jobs inside .github/workflows/create-release-pr.yml.
First, commitizen will bump the version, create (update) the CHANGELOG.md.
Then the date, rev, comment 9 fields are updated and committed to a release branch release/v$VERSION. Then, a pull request to main is opened.
The user can now inspect the changes and merge it.
Once the PR has been merged, the jobs inside .github/workflows/tag-release-merge.yml are triggered.
The job extracts the version from the pull request title and creates a corresponding tag on main. The kibot workflow is invoked, and artifacts are generated.
An official Github release Release X.Y.Z is created and the production files are uploaded to it.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 47k_0805 | Resistor_SMD:R_0805_2012Metric | R1 |
| 1 | BSS138 | Package_TO_SOT_SMD:SOT-23-3 | Q1 |
| 1 | MBR0530 | Diode_SMD:D_SOD-123 | D1 |
| 1 | Screw Terminal Block 5.00 mm 2 pol | 2s_connectors:TerminalBlock_MaiXu_MX126-5.0-02P_1x02_P5.00mm | J1 |
generationmake/CyphalPicoBase-CAN
Board for the Raspberry Pi Pico to connect via CAN using OpenCyphal and UCANPHY Micro


StuckAtPrototype/Racer
These are structured into their own files. I could have used submodules, but decided against it.

willem-pennings/balancing-cube
A cube that balances itself in a corner or edge using reaction wheels

abhishek-kakkar/BeagleLogic
A Software Suite that implements a logic analyzer with the PRU on the BeagleBone / BeagleBone Black.


lachlanA/eagle-to-kicad
Eagle SCH/LIB to KiCad SCH/LIB ULP conversion script
It measures 40 × 22.5 mm and has 2 copper layers, 1.6 mm thick.
4 parts, built around the BSS138 and MBR0530-TP. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the marinecircuits/kicad-template repository on GitHub, at the commit this page was made from: the board is template.kicad_pcb and its schematic template.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask marinecircuits before reusing the design.