4 layers47 × 39.5 mm
Stealthburner Toolhead PCB
acha666/RP2040_ToolheadPCB_SB
A Toolhead PCB for VORON StealthBurner based on RP2040
145 parts43GPL-3.0
 laneboysrc/rc-winch-controller6
This project is for a winch controller for Radio Controlled cars that uses channel 3 to operate the winch remotely.
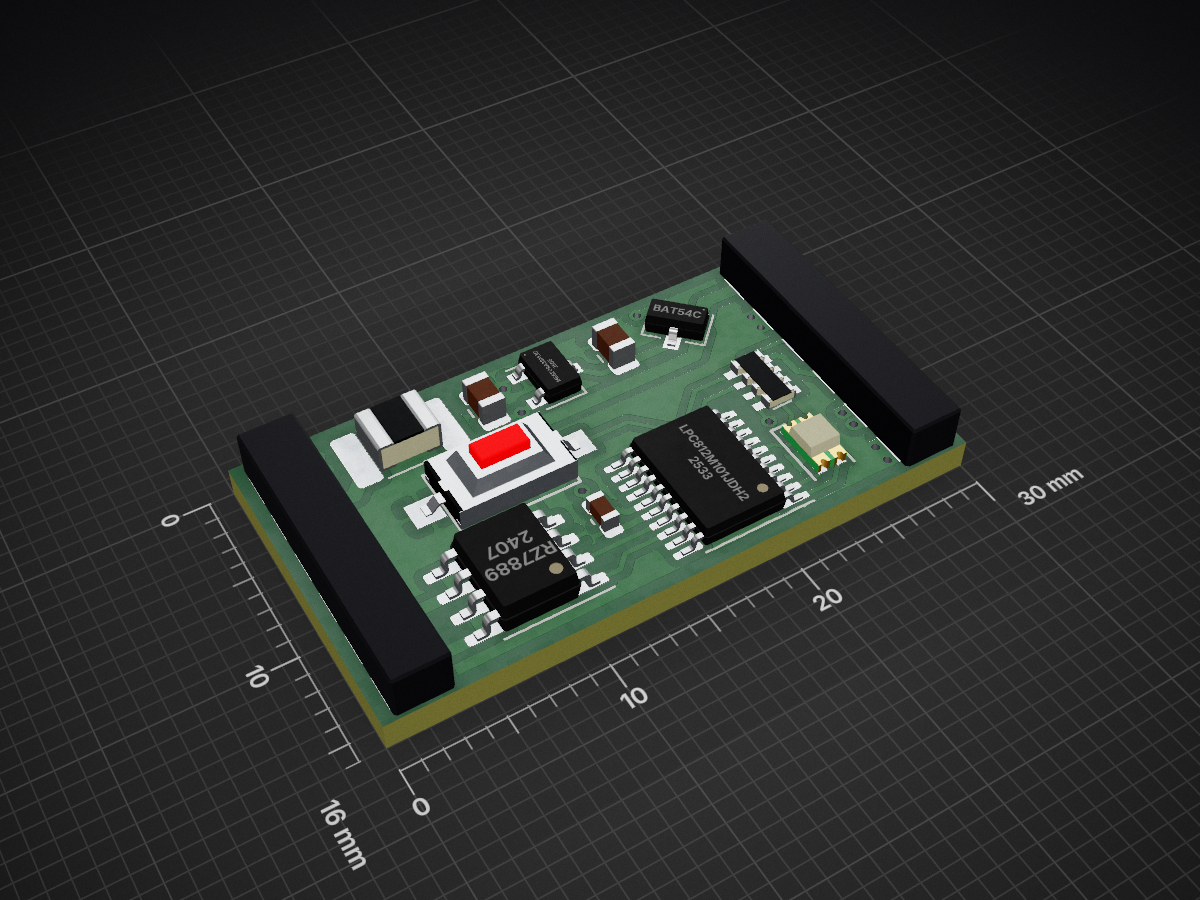
Rc winch controller is an open-source printed circuit board by laneboysrc, from the laneboysrc/rc-winch-controller repository on GitHub, published under the MIT licence. It is a 2-layer board of 30 × 16 mm with 13 parts on 19 nets, routed with 130 tracks and 18 vias.
It is built around the LPC812M101JDH20, RZ7889 and ME6209A33M3G, with the BAT54C among its other parts. Its parts include 3 capacitors, 3 ICs, 2 diodes, 2 connectors and 1 switch. It belongs with the radio and wireless boards and the NXP (LPC, Kinetis, i.MX RT) and PIC boards of this library.


This project is for a winch controller for Radio Controlled cars that uses channel 3 to operate the winch remotely.
Connect the winch controller to channel 3 of your receiver.
Three seconds after you apply power to the controller the winch motor will play a short tune. The sound will only play if a valid input signal has been detected. Note that the sound generated by the motor may be very faint depending on your winch.
To arm the switch, change the position of the channel 3 switch on your transmitter five times within a short period of times. The winch motor will now play a different tune of rising sounds indicatiting that it is armed. While armed, the winch motor will be braked electrically.
To move the winch in one direction, change the position of the channel 3 switch once. To move the winch in the other direction, change the position of the channel 3 switch twice within a short time.
To stop the winch moving toggle the position of the channel 3 switch.
The winch hardware is basically a H-bridge motor driver controlled from a tiny microcontroller.
The winch controller can be powered via the RC receiver, or from a separate supply connected to the pins labeled + an - on the ICSP connector.
The main components are a Microchip PIC 12F1840 microcontroller, two dual N- and P-Channel power FETs Fairchild FDS9934C, and a 3.3V LDO (Microchip MCP1702, 1703 or similar).
A common 1/10th scale RC winch can lift about 1.5 kg at 6 Volts. The maxium current we measured on our winch is 800 mA.
The schematics and a PCB layout are available in the electronics <electronics/>_ folder.
Bill of material:
::
Qty Value            Device               Parts
1   PIC12F1840       PIC12F1840 S08       U$2
2   FDS9934          P/N MOSFET SO8       T1, T2
1   MCP1702-3302     LDO 3V3 SOT23        U$1
2   MMTB2222         NPN-TRANSISTOR SOT23 Q1, Q2
2   1uF/16V          Capacitor SMD 1206   C1, C2
1   0R               Resistor SMD 0603    R9 (can be replced with a solder bridge)
6   4k7              Resistor SMD 0603    R1, R2, R3, R4, R7, R8
2   47k              Resistor SMD 0603    R5, R6
The 2-layer PCB size is 22.05 x 27.43 mm (0.87 x 1.08 inches).
.. image:: _images/pcb-top.png .. image:: _images/pcb-bottom.png
Gerber files for the PCB can be found in the electronics <electronics/>_ folder. The PCB can be
ordered directly from OSHPark <http://www.oshpark.com>_ in a minimum quantity of three.
The firmware has been developed using SDCC version 3.3 and gpasm version 1.0. GNU make is required for the build.
If you are compiling the software on a computer that does not have Unix-like tools installed (e.g. Microsoft Windows) then you may need to adapt the rm utility referenced in the Makefile (i.e. use "del" instead of "rm").
For convenience a pre-compiled HEX file is available for download here <firmware/rc-winch-controller-servo.hex>_.
The firmware comes in two variants: One that connects to channel 3 of a
RC receiver, and one with UART input which is meant to be utilized in
conjunction with the LANE Boys RC DIY RC Light controller <http://laneboysrc.blogspot.com/2012/07/diy-car-light-controller-for-3-channel.html>_.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 2 | Conn_01x06 | rc-winch-controller-footprints:PinHeader_1x06_P2.54mm_Flat | J1, J2 |
| 1 | 100n | Capacitor_SMD:C_0603_1608Metric | C3 |
| 1 | 10u | Capacitor_SMD:C_0805_2012Metric | C2 |
| 1 | 1K | Resistor_SMD:R_Array_Convex_4x0603 | RN1 |
| 1 | 1u | Capacitor_SMD:C_0805_2012Metric | C1 |
| 1 | 4A 16V 1812 | Fuse:Fuse_1812_4532Metric_Pad1.30x3.40mm_HandSolder | F1 |
| 1 | BAT54C | Package_TO_SOT_SMD:SOT-23 | D1 |
| 1 | LED_ARGB | rc-winch-controller-footprints:LED_RGB_XINGLIGHT_XL-2012RGBC | D2 |
| 1 | LPC812M101JDH20 | Package_SO:TSSOP-20_4.4x6.5mm_P0.65mm | U2 |
| 1 | ME6209A33M3G | Package_TO_SOT_SMD:SOT-23W | U1 |
| 1 | RZ7889 | Package_SO:SOIC-8-1EP_3.9x4.9mm_P1.27mm_EP2.29x3mm_ThermalVias | U3 |
| 1 | SETUP | rc-winch-controller-footprints:Tact switch 6x4x3 | SW1 |
It measures 30 × 16 mm and has 2 copper layers, 1.6 mm thick.
13 parts, built around the LPC812M101JDH20, RZ7889, ME6209A33M3G and BAT54C. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the laneboysrc/rc-winch-controller repository on GitHub, at the commit this page was made from: the board is electronics/rev2/rc-winch-controller.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
acha666/RP2040_ToolheadPCB_SB
A Toolhead PCB for VORON StealthBurner based on RP2040

laneboysrc/nrf24l01-rc
nRF24-based RC car receiver, compatible with HobbyKing HK310 and Turnigy 3XS


Squantor/squantorDevelBoards
Various development boards/test for microcontrollers, check for breakouts here


theta-machines/DEV-G2-NANO
The G2 Nano is powered by a record-breaking 1 GHz Arm Cortex-M7 processor, combining the performance of an application processor with real-time determinism.

Duet3D/Duet-2-Hardware
The KiCAD source for the Duet 3d printer controller see www.duet3d.com