2 layers112 × 45 mm
Pc1715-esp32vga
mgoegel/robotron-esp-vga.pcb
Robotron MDA Adapter, ESP32S3 based PCB Layout in KiCad 8.0
36 parts3

 JOvers26/SnekBot
sudo apt update && sudo apt install locales sudo locale-gen enUS enUS.UTF-8 sudo update-locale LCALL=enUS.UTF-8 LANG=enUS.UTF-8 export LANG=enUS.UTF-8
ESP32 PCB is an open-source printed circuit board by JOvers26, from the JOvers26/SnekBot repository on GitHub. It is a 2-layer board of 68 × 59 mm with 22 parts on 45 nets, routed with 270 tracks and 33 vias.
It is built around the ESP32-S3-WROOM-1-N8, LM1117MP-3.3 and USB4105-GF-A. Its parts include 5 capacitors, 3 resistors, 3 connectors, 2 ICs and 2 switches. It belongs with the ESP32 boards of this library.


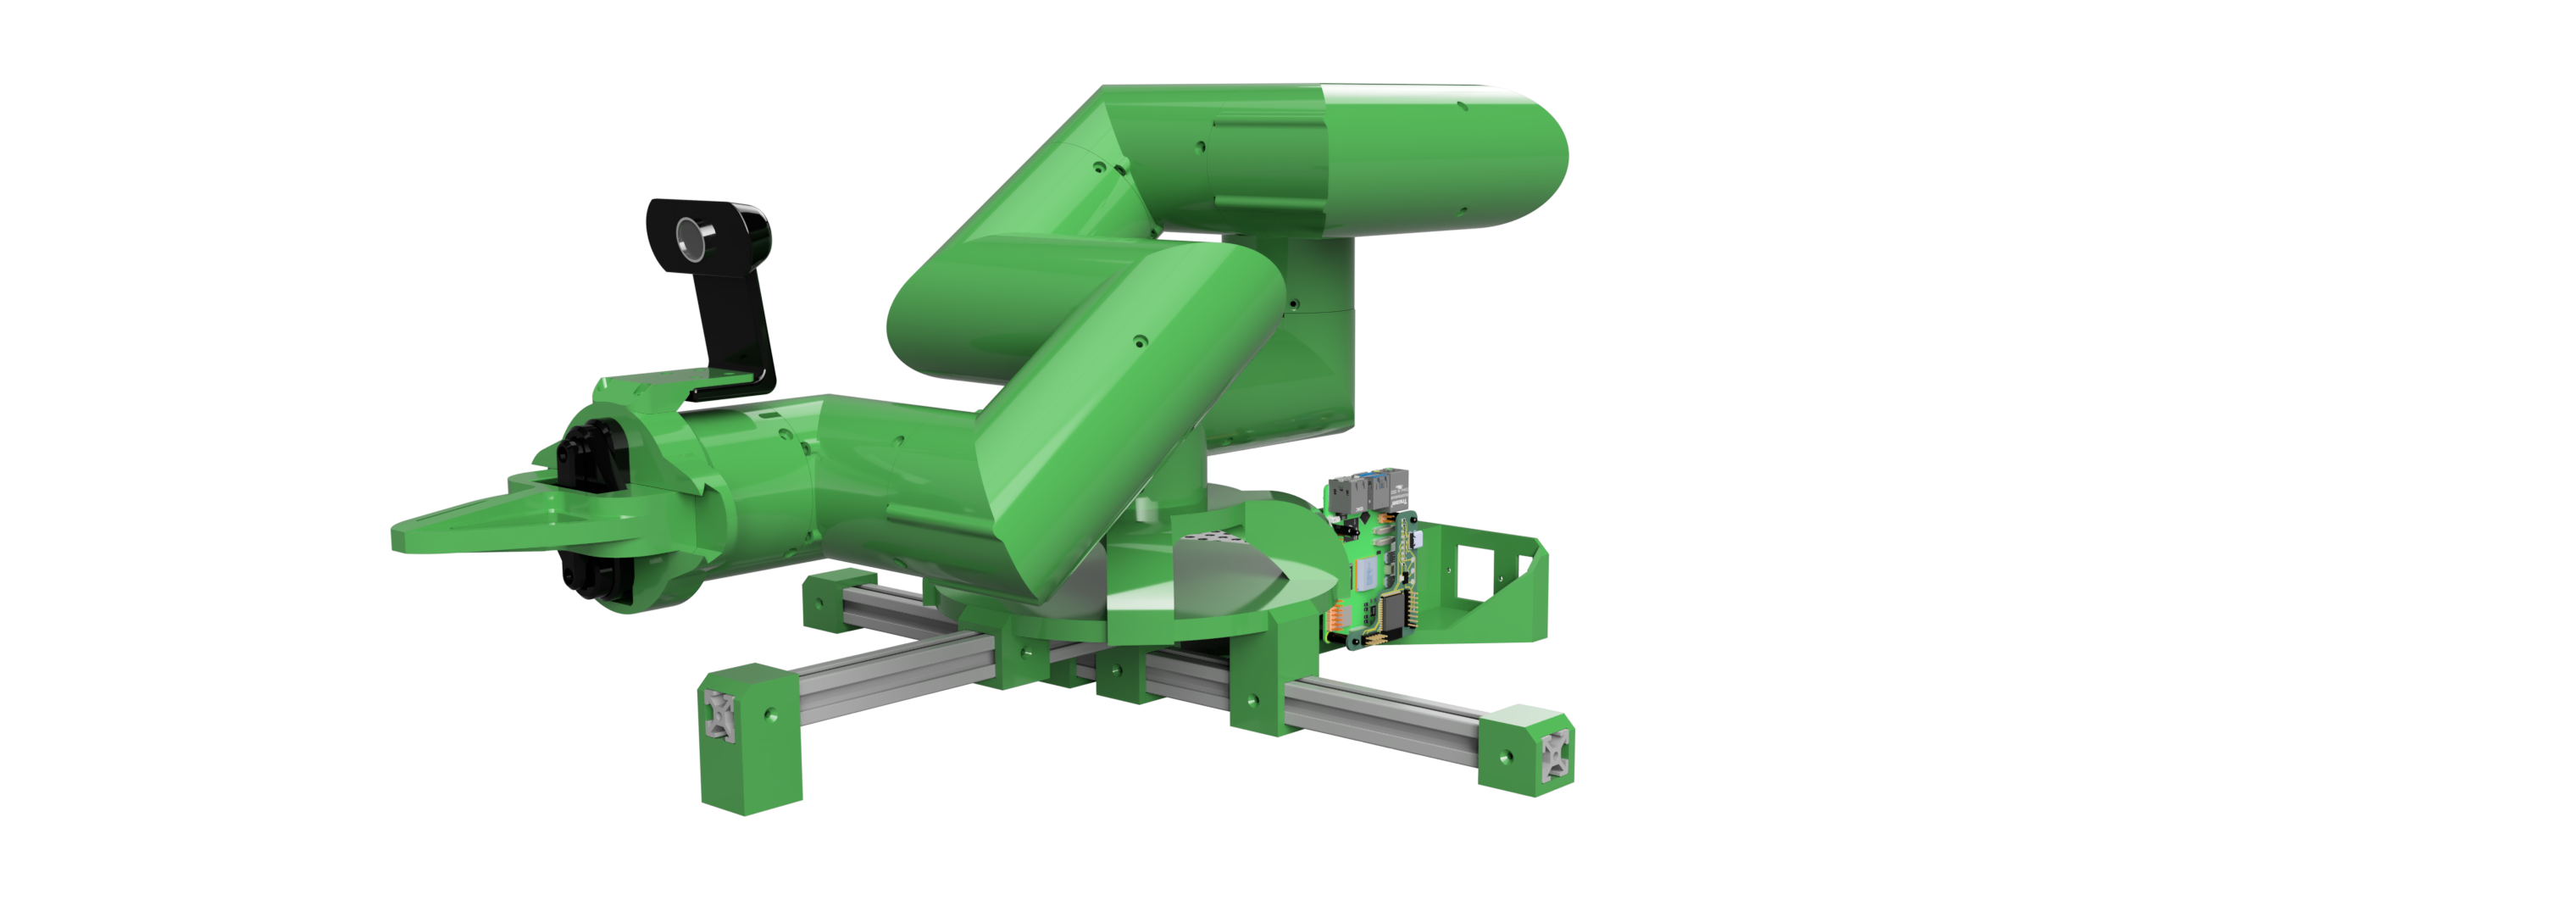
This project is a work in progress and setup is subject to change.
SnekBot is a six-axis robotic arm designed for the QUT ROAR team to use in the Australian Rover Challenge (ARCh)
Ensure Ubuntu 24.04 is flashed on the Raspberry Pi 5 and configured for remote access via SSH.
Ensure your system uses UTF-8 encoding:
locale  # Check for UTF-8

sudo apt update && sudo apt install locales
sudo locale-gen en_US en_US.UTF-8
sudo update-locale LC_ALL=en_US.UTF-8 LANG=en_US.UTF-8
export LANG=en_US.UTF-8

locale # Verify settingssudo apt install software-properties-common
sudo add-apt-repository universesudo apt update && sudo apt install curl -y
sudo curl -sSL https://raw.githubusercontent.com/ros/rosdistro/master/ros.key -o /usr/share/keyrings/ros-archive-keyring.gpgecho "deb [arch=$(dpkg --print-architecture) signed-by=/usr/share/keyrings/ros-archive-keyring.gpg] http://packages.ros.org/ros2/ubuntu $(. /etc/os-release && echo $UBUNTU_CODENAME) main" | sudo tee /etc/apt/sources.list.d/ros2.list > /dev/nullsudo apt update && sudo apt install ros-dev-toolssudo apt updatesudo apt upgradesudo apt install ros-jazzy-ros-baseEnsure ROS 2 is sourced correctly:
# Replace ".bash" with your shell if you're not using Bash
# Possible values: setup.bash, setup.sh, setup.zsh
source /opt/ros/jazzy/setup.bash
For more details, visit the official ROS 2 documentation.
git clone https://github.com/JOvers26/SnekBot
cd ~/SnekBotcd ~/SnekBot/ros2_ws
sudo rosdep init
rosdep update
rosdep install --from-paths src --ignore-src -r -ysource /opt/ros/jazzy/setup.bash
sudo apt install ros-$ROS_DISTRO-foxglove-bridgecd ~SnekBot/ros2_ws
colcon build --symlink-install
source install/setup.bashsudo apt-get install git wget flex bison gperf python3 python3-pip python3-venv cmake ninja-build ccache libffi-dev libssl-dev dfu-util libusb-1.0-0mkdir -p ~/esp
cd ~/esp
git clone -b v5.2.5 --recursive https://github.com/espressif/esp-idf.gitcd ~/esp/esp-idf
./install.sh all. $HOME/esp/esp-idf/export.shcd ~SnekBot/ESP32_Code/int32_Publisher
pip3 install catkin_pkg lark-parser colcon-common-extensions empy==3.3.4
idf.py set-target esp32s3
idf.py menuconfig
#In micro-ROS Settings ->
#Set micro-ROS-Agent IP
#Set WiFi Credentialsidf.py build
idf.py -p /dev/ttyACM0 flash
# Note if this does not work you may need to add user to the dialout group
sudo usermod -aG dialout $USER
idf.py -p /dev/ttyACM0 flashsudo apt-get install wget gpg
wget -qO- https://packages.microsoft.com/keys/microsoft.asc | gpg --dearmor > packages.microsoft.gpg
sudo install -D -o root -g root -m 644 packages.microsoft.gpg /etc/apt/keyrings/packages.microsoft.gpg
echo "deb [arch=amd64,arm64,armhf signed-by=/etc/apt/keyrings/packages.microsoft.gpg] https://packages.microsoft.com/repos/code stable main" |sudo tee /etc/apt/sources.list.d/vscode.list > /dev/null
rm -f packages.microsoft.gpg
sudo apt install apt-transport-https
sudo apt update
sudo apt install code # or code-insiderssudo apt install python3-venv
cd ~SnekBot
python3 -m venv venv
source venv/bin/activate
pip3 install pygame
pip3 install setuptools
pip3 install roboticstoolbox-python
pip3 install "numpy<2"source /opt/ros/jazzy/setup.bashcd ~SnekBot/ros2_ws
colcon build --symlink-install
source install/setup.bashros2 run micro_ros_agent micro_ros_agent udp4 --port 8888source /opt/ros/jazzy/setup.bash
ros2 run foxglove_bridge foxglove_bridge. $HOME/esp/esp-idf/export.shidf.py -p /dev/ttyACM0 flash
idf.py -p /dev/ttyACM0 monitor| Qty | Value | Footprint | References |
|---|---|---|---|
| 3 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4, C8, C9 |
| 3 | 5.1K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2, R6 |
| 3 | MountHole | MountingHole:MountingHole_3.2mm_M3 | H1, H2, H3 |
| 3 | TestPoint | TestPoint:TestPoint_Pad_D3.0mm | TP1, TP2, TP3 |
| 2 | 10uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C7 |
| 2 | SW_Push | Button_Switch_SMD:SW_Push_SPST_NO_Alps_SKRK | SW1, SW2 |
| 1 | Conn_01x08_Pin | Connector_PinHeader_2.54mm:PinHeader_1x08_P2.54mm_Vertical | J2 |
| 1 | Conn_01x10_Pin | Connector_PinHeader_2.54mm:PinHeader_2x05_P2.54mm_Vertical | J3 |
| 1 | D_Small | Diode_SMD:D_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D1 |
| 1 | ESP32-S3-WROOM-1 | RF_Module:ESP32-S3-WROOM-1 | U1 |
| 1 | LM1117MP-3.3 | Package_TO_SOT_SMD:SOT-223-3_TabPin2 | U2 |
| 1 | USB4105-GF-A | USB4105-GF-A:GCT_USB4105-GF-A | J1 |
It measures 68 × 59 mm and has 2 copper layers, 1.6 mm thick.
22 parts, built around the ESP32-S3-WROOM-1-N8, LM1117MP-3.3 and USB4105-GF-A. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the JOvers26/SnekBot repository on GitHub, at the commit this page was made from: the board is ESP32 PCB/Version 1/Version 1.kicad_pcb and its schematic ESP32 PCB/Version 1/Version 1.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask JOvers26 before reusing the design.
mgoegel/robotron-esp-vga.pcb
Robotron MDA Adapter, ESP32S3 based PCB Layout in KiCad 8.0

MrRooby/Maszyna-W-ESP32
ESP32 based project with addressable LED displays, simulating basic CPU architecture with website Websocket connectivity for real time visualization

Imdad2005/ESP32-S3-testboard
Custom 4-layer ESP32-S3 IoT testboard designed in KiCad 9, featuring USB-C, 3.3 V power regulation, environmental sensing, and QWIIC/SPI expansion.

iowlabs/camara_electroforesis
Dispositivo para la instrumentación de experimentos de electroforesis. Considera tanto el diseño de un modelo 3D para el tanque, como la electrónica para una fuente generadora de voltaje.

iowlabs/incubadora
Proyecto para confeccionar una incubadora bajo costo.


KavyanshKhaitan2/ironman-hands
A cool glove with bunch of sensors so you can interact with your computer in a different way!!