2 layers
Nrf bga
github-linguist/linguist
Language Savant. If your repository's language is being reported incorrectly, send us a pull request!
12 parts14kMIT
 gxurma/PythonCanSteering
PyQt Can Middleware for steering Elmo Cello driven BLDC drives with openpnp
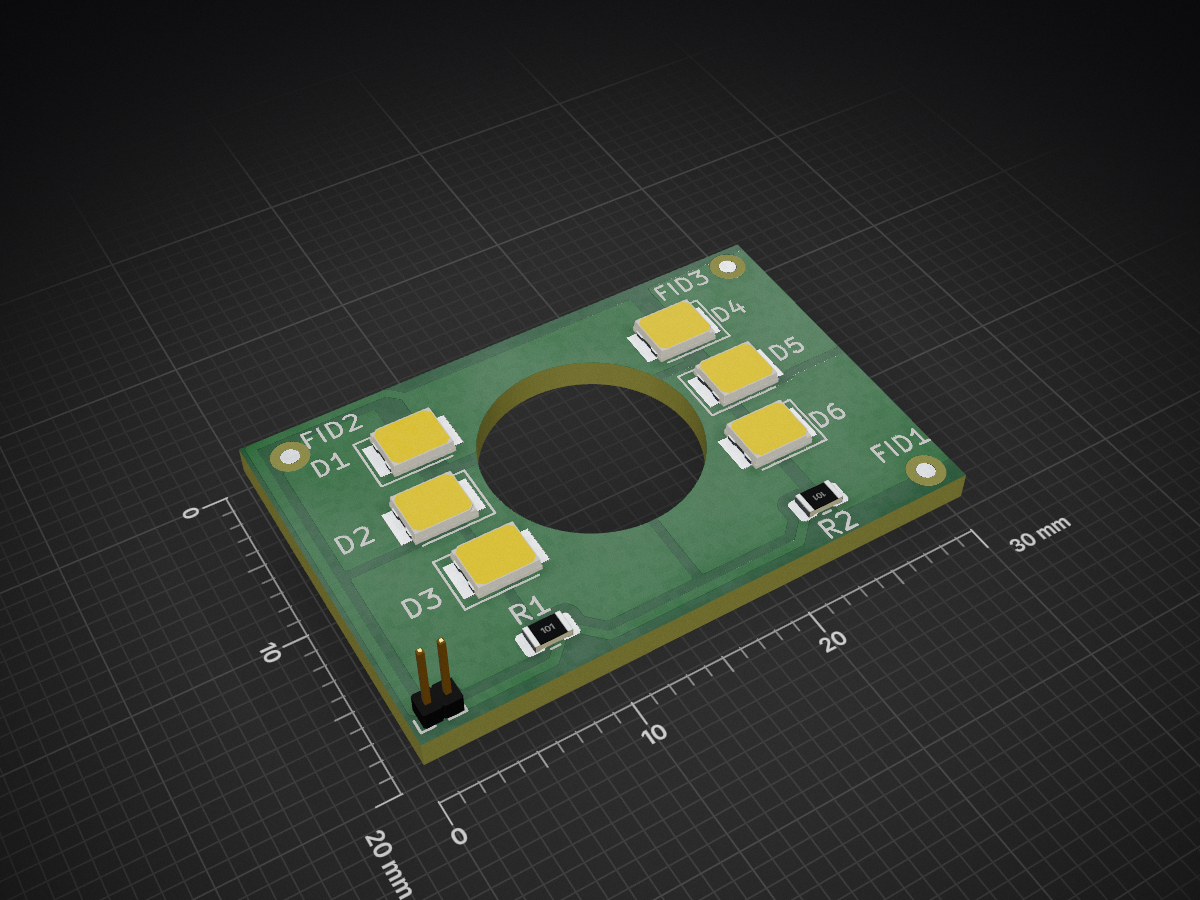
Testdruck R0805 is an open-source printed circuit board by gxurma, from the gxurma/PythonCanSteering repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 30 × 20 mm with 12 parts on 8 nets, routed with 14 tracks and 0 vias.
Its parts include 6 diodes, 2 resistors and 1 connector.
PyQt4 Kvaser Canlib Can Middleware for steering Elmo Motion Cello 10/100 driven BLDC drives with openpnp
Canlib is taken from the Kvaser Canlib SDK. It is used as a wrapper to their library.
Tested with Kvaser Leaf Light 2
The Cello are commanded over CAN bus with the SimplIQ commands.
Middleware talks to openpnp through a network socket.
The middleware periodically polls the position of all axes, and sends it to the openpnp
Middleware sends all M commands higher than 800 to the Smoothieboard.
Homing is done simultaneously on all axes at the same time, after calling init().
How does homing work:
By pressing the Home button, the axis is driven with a defined jogSpeed to a mechanical stop, then the homing function is armed and the axis is travelling in the reverse direction with searchSpeed, slowly it searches for the index pulse.
X1 and Y is getting home position 0, Z gets the home position 100000, X2 gets the home position -4000, when it sees the index pulse.
C does not do the mechanical stop search, since that axis does not have one. It gets home position 744, so the nose of my tips is looking to the left.
Since my machine has 2 X axes, where one of them is on the arm, and one of them is moving the desktop table, an algorithm had to be written to decide how to consistently and for openpnp transparently reach the specific points on the table. The goal is to extend the X travel possibilities.
It is currently set so that the table moves to 7500, 0 or -4600, depending on the overall sum X that needs to be reached.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 6 | LED | LED_SMD:LED_PLCC_2835_Handsoldering | D1, D2, D3, D4, D5, D6 |
| 3 | Fiducial | Fiducial:Fiducial_1mm_Mask2mm | FID1, FID2, FID3 |
| 2 | 100 | Resistor_SMD:R_0805_2012Metric | R1, R2 |
| 1 | Conn_01x02_Pin | Connector_PinHeader_1.00mm:PinHeader_1x02_P1.00mm_Vertical | J1 |
It measures 30 × 20 mm and has 2 copper layers, 1.6 mm thick.
12 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the gxurma/PythonCanSteering repository on GitHub, at the commit this page was made from: the board is PCB/Testdruck-R0805/Testdruck-R0805.kicad_pcb and its schematic PCB/Testdruck-R0805/Testdruck-R0805.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
github-linguist/linguist
Language Savant. If your repository's language is being reported incorrectly, send us a pull request!


google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

VoronDesign/Voron-Tap
Tap is a nozzle-based z-probe for the V2 and Trident printer designs. The entire toolhead moves to trigger an optical switch. Tap offers many advantages:

stacksmashing/pico-tpmsniffer
A simple, very experimental TPM sniffer for LPC bus