2 layers137.7 × 61.5 mm
EMG Device
Demkku/EMG-Device
Project for university course: Principles of Digital Fabrication of Oulu University
73 parts

 EthanLawlor/RobotArm
6 Degree of Freedom Articulated Robot Arm. 3D Modelled and Printed, Servo Actuators, ATmege328P based custom PCB with BLE Communications, Custom Android APK for Controls.
RobotArmMK1.2 is an open-source printed circuit board by EthanLawlor, from the EthanLawlor/RobotArm repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 50.9 × 36.5 mm with 25 parts on 37 nets, routed with 191 tracks and 26 vias.
It is built around the ATMEGA328P-PU, HC-05 and AMS1117. Its parts include 7 connectors, 5 capacitors, 4 resistors, 2 ICs and 1 diode. It belongs with the robots and motor control and radio and wireless boards and the AVR (ATmega, ATtiny) boards of this library.


A compact, fully customizable desktop robot arm designed for small-scale automation tasks. Developed as part of a Bachelor of Engineering in Mechatronics at Technological University Dublin, this project integrates 3D-printed components, servo motor actuation, custom electronics, Arduino-based firmware, Bluetooth control, and an Android app interface.
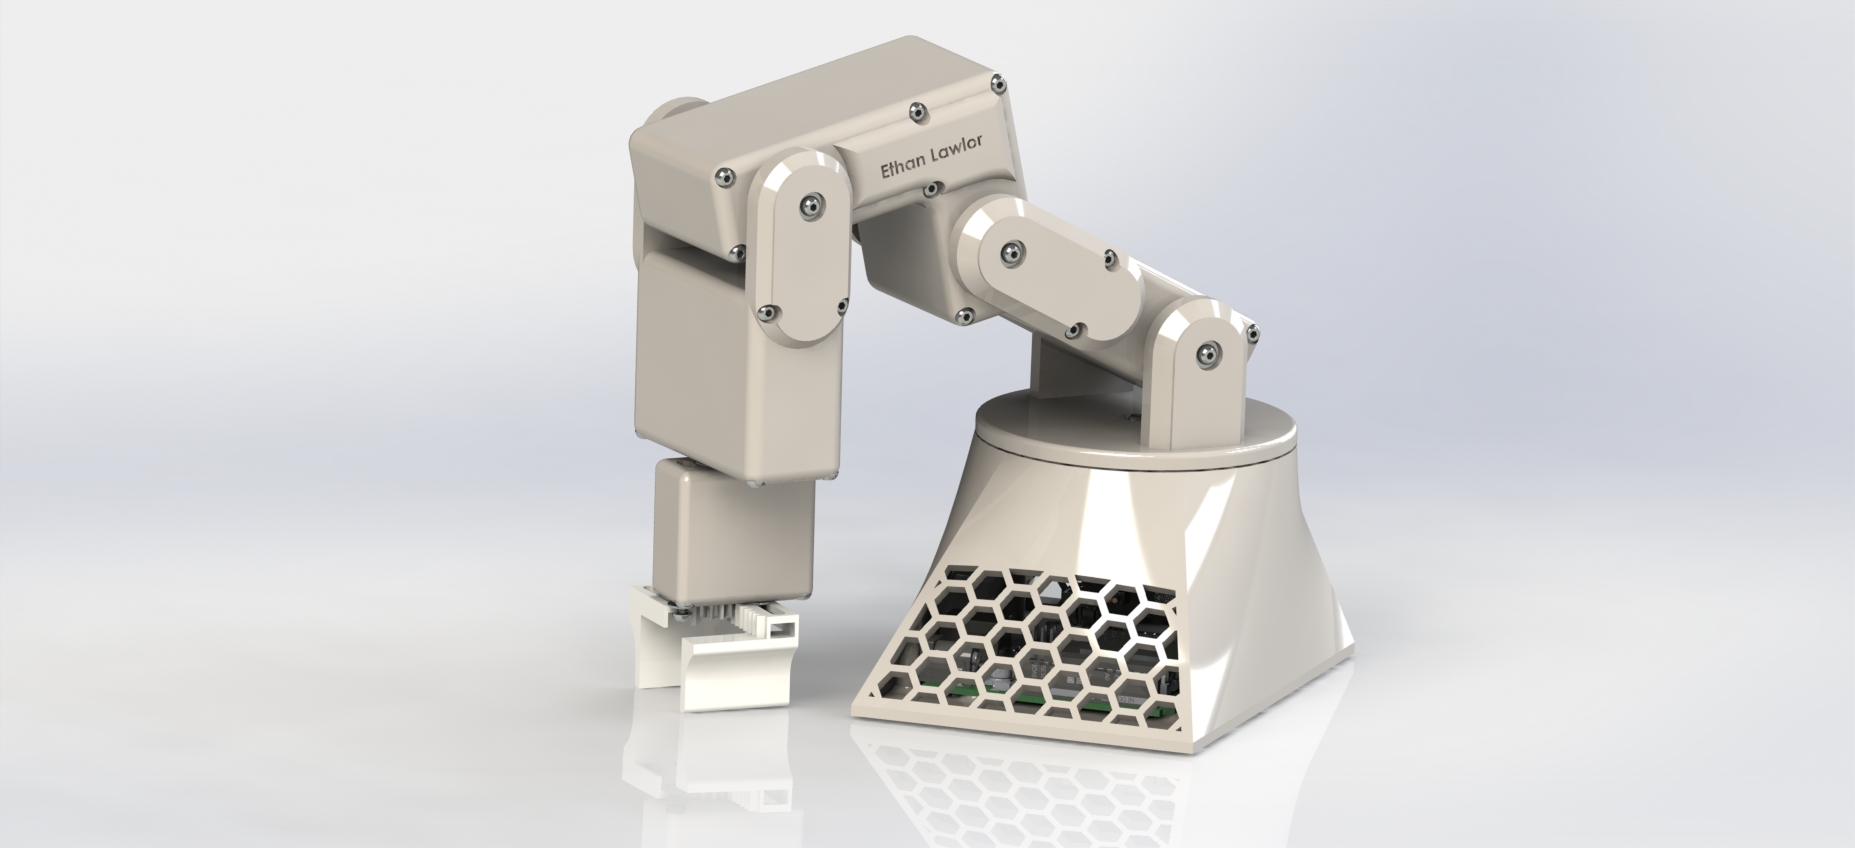
Figure: CAD render of the assembled Desktop Robot Arm
Documentation
RobotArm-ProjectReport.pdf – Full project report with design, testing, and resultsElectrical
KiCAD-PCB/ – Circuit schematics, custom PCB layout, and Gerber filesMechanical
STL-Files/ – 3D-printable mechanical componentsSoftware
Arduino-Firmware/ – Code for ATmega328P (Arduino)MIT-App-Inventor/ – Android app .aia source and .apk installerHome, Ready, Wave, Screwdriver, Circles, Diagonals, Worm, Demo90,90,90,90,90,90*)Demo, Home, etc.)0#/100#)STL-Files/ folder.Arduino-Firmware/ to your ATmega328P.MIT-App-Inventor/ (.apk) or open .aia to modify.📄 Full design details, diagrams, testing results, and methodology can be found in the Project Report (PDF).
This project is open-source and distributed under the terms of the GNU General Public License v3.0 (GPL-3.0).
Ethan Lawlor
B.Eng. Mechatronics
Technological University Dublin
| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2 | H1, H2, H3, H4 |
| 2 | 1K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R2, R4 |
| 2 | 22pF | Capacitor_SMD:C_0201_0603Metric_Pad0.64x0.40mm_HandSolder | C3, C4 |
| 1 | 100nF | Capacitor_SMD:C_0201_0603Metric_Pad0.64x0.40mm_HandSolder | C5 |
| 1 | 100uF | PCBFootprints:TAJB_AVX-M | C1 |
| 1 | 10K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R3 |
| 1 | 10uF | Capacitor_SMD:C_1206_3216Metric_Pad1.33x1.80mm_HandSolder | C2 |
| 1 | 16MHz OSC | Oscillator:Oscillator_SMD_ECS_2520MV-xxx-xx-4Pin_2.5x2.0mm | Y1 |
| 1 | 2K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1 |
| 1 | AMS1117 | Package_TO_SOT_SMD:TO-252-2 | U2 |
| 1 | ATmega328P-P | Package_QFP:TQFP-32_7x7mm_P0.8mm | U1 |
| 1 | FTDi | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-6_1x06_P2.54mm_Horizontal | J2 |
| 1 | HC-05 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-6_1x06_P2.54mm_Horizontal | J1 |
| 1 | LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1 |
| 1 | Neopixel | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-4_1x04_P2.54mm_Horizontal | J6 |
| 1 | Power | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-2_1x02_P2.54mm_Horizontal | J7 |
| 1 | S1 S2 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-2_1x02_P2.54mm_Horizontal | J3 |
| 1 | S3 S4 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-2_1x02_P2.54mm_Horizontal | J4 |
| 1 | S5 S6 | TerminalBlock_TE-Connectivity:TerminalBlock_TE_282834-2_1x02_P2.54mm_Horizontal | J5 |
| 1 | SW_Push_Dual | Button_Switch_SMD:SW_Push_1P1T_NO_6x6mm_H9.5mm | Reset1 |
It measures 50.9 × 36.5 mm and has 2 copper layers, 1.6 mm thick.
25 parts, built around the ATMEGA328P-PU, HC-05 and AMS1117. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the EthanLawlor/RobotArm repository on GitHub, at the commit this page was made from: the board is 1.Electrical/RobotArmMK1.2/RobotArmMK1.2.kicad_pcb and its schematic 1.Electrical/RobotArmMK1.2/RobotArmMK1.2.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
Demkku/EMG-Device
Project for university course: Principles of Digital Fabrication of Oulu University

alazifi/baby-incubator-tester
Berikut pasangan versi yang diimplementasikan untuk menghasilkan kinerja alat yang optimal.

ataweg/DataLogger
DataLogger using "Arduino UNO" board and Greiman SdFat library

NYDEREK/LineFollower_GRUZIK2.0-light
GRUZIK2.0 is simple light construction made for "line follower light" competition


duongngochoan/Self_balancing_robot_PID
Used a PID control algorithm and MPU605 sensor to balance a two-wheeled robot.

leikoilja/muscle-imbalance-detection
A device to assist patients with the rehabilitation of the knee joint after a knee surgery using EMG biofeedback. The device can reliably detect muscle activity and display it in an easy-to-use mobile application.

xtarke/automated_buggy
This shield connects microcontroller (MSP-EXP430FR2355) pins to the car's power board. Go to Power Board for more hardware information.