2 layers74.4 × 51.2 mm
Esp32-wroom timer
AlessandroAU/Chorus32-ESP32LapTimer
This is an ESP32 port of the popular Chorus RF Laptimer
66 parts102GPL-3.0

 e-abdi/SMaRT
Sensor Management and Relay Tool for underwater gliders
SMaRT is an open-source printed circuit board by e-abdi, from the e-abdi/SMaRT repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 40 × 105 mm with 36 parts on 70 nets, routed with 505 tracks and 109 vias.
It is built around the MP1584EN. Its parts include 14 connectors, 5 ICs and 1 resistor. It belongs with the sensors and measurement and computers and single-board computers boards and the RP2040 boards of this library.
Sensor Management and Relay Tool
This tool is designed to facilitate easier sensor integration on gliders, and it replaces this board. The idea is to have a mainboard that hosts popular, easy-to-source modules in order to create a man-in-the-middle board for custom sensor integration on Seaglider or to fully use the capabilities of the Slocum BackSeatDriver without the need for power-hungry boards such as the Raspberry Pi or other single-board computers.
Hardware
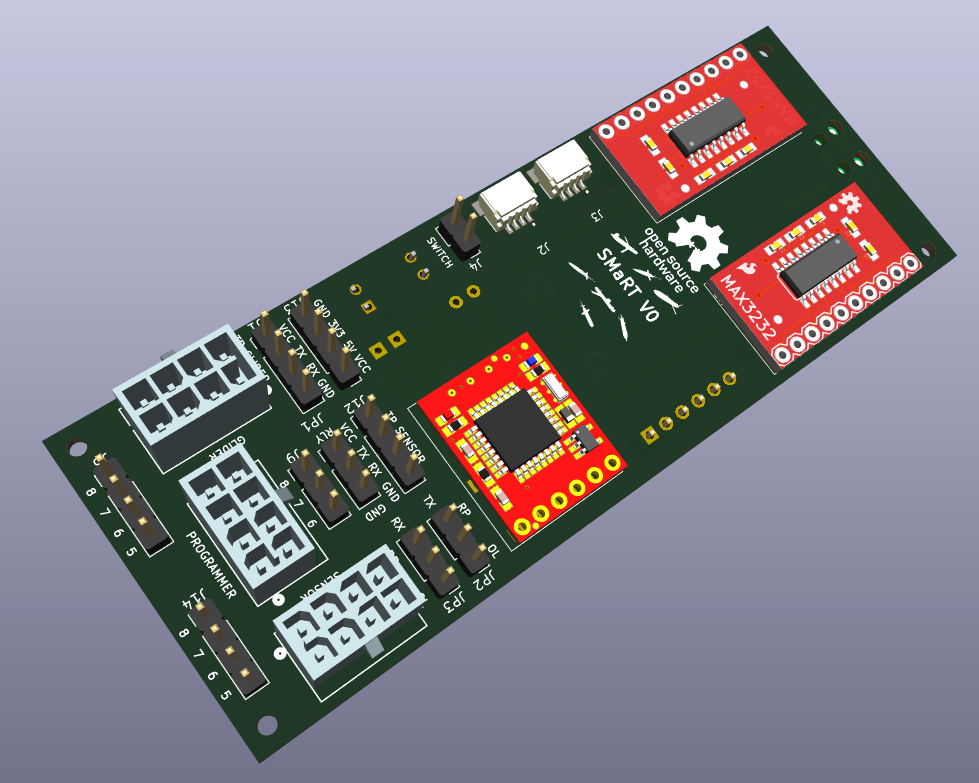
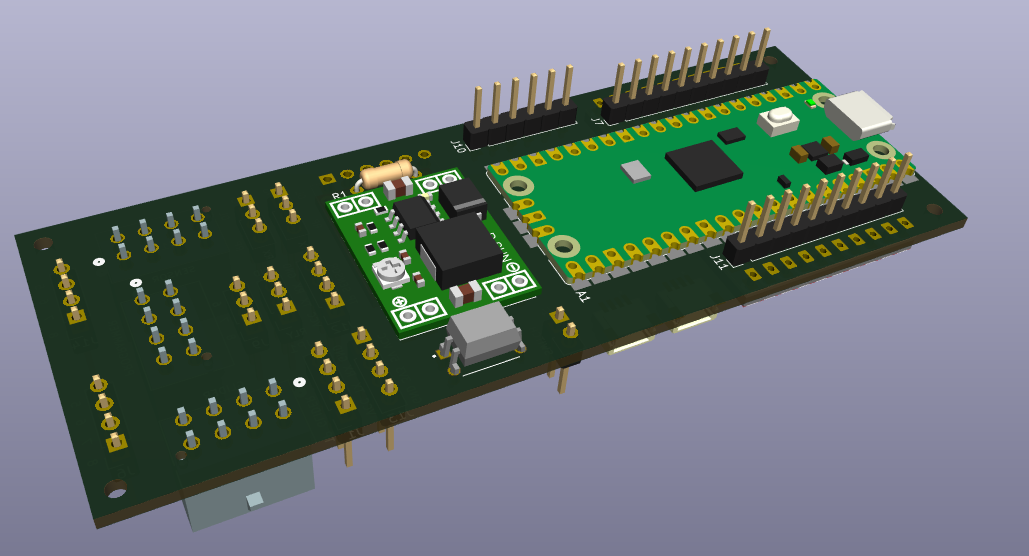
The form factor is also just small enough to fit inside a 1000 m rated 2" x 150 mm Blue Robotics housing, so it could be used as an external interface, which was the original idea. It could also be used as a simple logger with a single end connection to a sensor.
Firmware
The firmware is based on Zephyr, a modern open-source real-time operating system hosted by the Linux Foundation and originally initiated by Intel. It follows industry best practices for safety, security, and modularity, and benefits from a broad, vendor-neutral ecosystem. Unlike many traditional RTOS solutions that are tightly coupled to a single vendor, Zephyr is highly portable and hardware-agnostic, making it well suited for flexible and scalable embedded system design.
The firmware (see firmware/README.md) supports both Slocum (Backseat Driver) and Seaglider (logdev). Each glider + sensor integration is a profile under firmware/profiles/: a configuration file plus the matching glider-side file (extctl.ini or .cnf), so most new sensors need no code. Profiles are included for the UVP6 on both gliders. The original Slocum UVP6 firmware is kept in legacy/uvp6_slocum_v1.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | LOGO | LOGO | G1, G2, G3, G4, G5, G6, G7, G8 |
| 4 | MountingHole_2mm | MountingHole:MountingHole_2mm | H1, H2, H3, H4 |
| 3 | Jumper_3_Open | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | JP1, JP2, JP3 |
| 2 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J6, J14 |
| 2 | Conn_01x10 | Connector_PinHeader_2.54mm:PinHeader_1x10_P2.54mm_Vertical | J7, J11 |
| 2 | MAX3232_SPARKFUN | MAX3232:MAX3232_Sparkfun | U2, U4 |
| 2 | Qwiic_Connector | Qwiic:Qwiic | J2, J3 |
| 1 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J4 |
| 1 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J9 |
| 1 | Glider | MolexLib:CONN_2068320000-SD_08_MOL | J5 |
| 1 | MP1584 | MPT1684:MPT1584EN_Module | U1 |
| 1 | OPENLOG | OpenLog:OpenLog | U5 |
| 1 | Power_TP | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J10 |
| 1 | Programmer | MolexLib:CONN_2068320000-SD_08_MOL | J8 |
| 1 | R | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1 |
| 1 | RaspberryPi_Pico | Module:RaspberryPi_Pico_SMD_HandSolder | A1 |
| 1 | Sensor | MolexLib:CONN_2068320000-SD_08_MOL | J13 |
| 1 | TestPins_Glider | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J1 |
| 1 | TestPins_Sensor | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J12 |
| 1 | ~ | G3VM-41AY1:G3VM-41AY1 | U3 |
It measures 40 × 105 mm and has 2 copper layers, 1.6 mm thick.
36 parts, built around the MP1584EN. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the e-abdi/SMaRT repository on GitHub, at the commit this page was made from: the board is hardware/SMaRT/SMaRT.kicad_pcb and its schematic hardware/SMaRT/SMaRT.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
AlessandroAU/Chorus32-ESP32LapTimer
This is an ESP32 port of the popular Chorus RF Laptimer

langpie/langpie
An Opensource Raspberry Pi Based Smart Car Project (ORPSC Project) - 树莓派开源智能车项目

ghent360/PrntrBoardV2
32-bit 3D Printer controller board using STM32F407 and replaceable TMC2660/2209 stepper drivers.

4rynv/Eklavya_Gantry
an attempt to automate screwing out and in of screw holes arranged in a matrix formation


kavers1/wirebender
3D designs are shared in STL format. The 3D model is available as a Fusion 360 project Wire bender

merlindorin/esp32-fan-controller
A small KiCad board to keep my home server cabinet cool. 4 PWM fans, 4 temperature probes, one ESP32.