2 layers185.6 × 220.5 mm
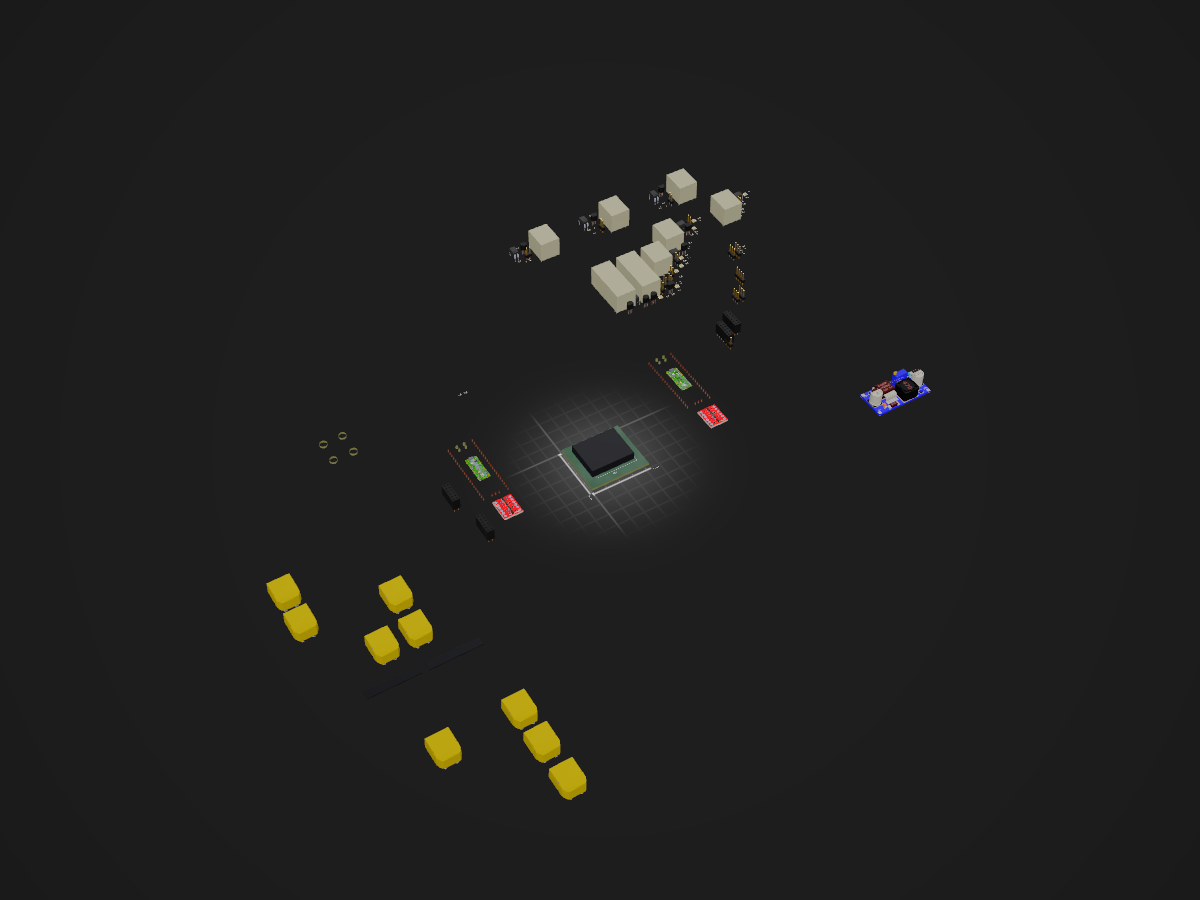
 dylanballback/RoboBoat_PCB
RoboBoatPCB_V1
RoboBoat PCB 2 is an open-source printed circuit board by dylanballback, from the dylanballback/RoboBoat_PCB repository on GitHub, published under the MIT licence. It is a 2-layer board of 42.8 × 38.9 mm with 129 parts on 162 nets.
Its parts include 35 resistors, 29 connectors, 23 diodes, 20 transistors and 11 switches. It belongs with the RP2040 boards of this library.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 20 | 1K | Resistor_SMD:R_0805_2012Metric | R1, R2, R3, R10, R11, R12, R13, R14, R15, R16, R17, R18, R19, R20, R21, R34 +4 |
| 10 | 100K | Resistor_SMD:R_0805_2012Metric | R24, R25, R26, R27, R28, R29, R30, R31, R32, R33 |
| 10 | LED2 | LED_SMD:LED_0402_1005Metric | D1, D2, D3, D4, D8, D14, D15, D16, D17, D22 |
| 10 | ~ | Diode_SMD:D_1210_3225Metric | D9, D10, D11, D12, D13, D18, D19, D20, D21, D23 |
| 10 | ~ | Relay_THT:Relay_SPDT_Finder_36.11 | K1, K2, K3, K4, K5, K6, K7, K8, K9, K11 |
| 10 | ~ | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J11, J12, J13, J14, J15, J16, J17, J18, J19, J29 |
| 10 | ~ | Package_TO_SOT_THT:TO-92_Inline | Q6, Q7, Q8, Q9, Q10, Q15, Q16, Q17, Q18, Q20 |
| 10 | ~ | dylan:DIP762W50P254L650H458Q4B | Q1, Q2, Q3, Q4, Q5, Q11, Q12, Q13, Q14, Q19 |
| 4 | MountingHole | MountingHole:MountingHole_5.3mm_M5 | H1, H2, H3, H4 |
| 3 | 300 | Resistor_SMD:R_0603_1608Metric | R6, R7, R8 |
| 3 | LED | LED_SMD:LED_0402_1005Metric | D5, D6, D7 |
| 2 | 24V IN | dylan:AMASS_XT60PW-M | J20, J21 |
| 2 | 24V Out | dylan:AMASS_XT60PW-M | J22, J23 |
| 2 | 3555-2 | dylan:FUSE_3555-2 | F1, F2 |
| 2 | Level Shifter | dylan:CONV_BOB-12009 | U1, U8 |
| 1 | 10k | Resistor_SMD:R_0805_2012Metric | R22 |
| 1 | 12V IN | dylan:AMASS_XT60PW-M | J25 |
| 1 | 12V OUT Router | dylan:AMASS_XT60PW-M | J27 |
| 1 | 12V OUT WaterPump | dylan:AMASS_XT60PW-M | J28 |
| 1 | 12V OUT Xavier | dylan:AMASS_XT60PW-M | J26 |
| 1 | 12V TO 5V LM2596 (3A) | dylan:DCDC_StepDown_LM2596 | U6 |
| 1 | 15k | Resistor_SMD:R_0805_2012Metric | R23 |
| 1 | 24V 80A E-Stop Relay | dylan:JD2912-1H-24VDC 80A 28VDC | K10 |
| 1 | 24V Out To DC-DC Converter | dylan:AMASS_XT60PW-M | J24 |
| 1 | Auto_PICO_Power/Coms | Connector_PinSocket_2.54mm:PinSocket_2x06_P2.54mm_Vertical | J7 |
| 1 | Autonomous Pico | dylan:RPi_Pico_SMD_TH | U4 |
| 1 | BackMotorOutput | Connector_PinSocket_2.54mm:PinSocket_2x06_P2.54mm_Vertical | J10 |
| 1 | BackServoOutput | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J8 |
| 1 | FrontMotorOutput | Connector_PinSocket_2.54mm:PinSocket_2x06_P2.54mm_Vertical | J9 |
| 1 | FrontServoOutput | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J2 |
| 1 | LED | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | RC Pico | dylan:RPi_Pico_SMD_TH | U3 |
| 1 | RC Reciever | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J3 |
| 1 | RC_PICO_Power/Coms | Connector_PinSocket_2.54mm:PinSocket_2x06_P2.54mm_Vertical | J1 |
| 1 | TurretServoOutput_1 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J4 |
| 1 | TurretServoOutput_2 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |


jackw01/pi-tin
Open source raspberry pi handheld retro gaming console

BathroomEpiphanies/KiCAD-Keyboard-Tutorial
Tutorial on making keyboard PCB layouts in KiCAD


It measures 42.8 × 38.9 mm and has 2 copper layers, 1.6 mm thick.
129 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the dylanballback/RoboBoat_PCB repository on GitHub, at the commit this page was made from: the board is RoboBoat PCB 2.kicad_pcb and its schematic PowerManagement.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).