2 layers116.8 × 30 mm
Type d
google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards
14 parts3kApache-2.0

 DiezelBrown/RC-Crawler-Control-Telemetry-Platform1
Custom 1/10 scale RC crawler integrating embedded systems, ESP32 telemetry, wireless monitoring, and a custom-fabricated steel chassis.
RC Crawler Telemetry PCB is an open-source printed circuit board by DiezelBrown, from the DiezelBrown/RC-Crawler-Control-Telemetry-Platform repository on GitHub. It is a 2-layer board of 77 × 99 mm with 14 parts on 36 nets, routed with 67 tracks and 0 vias.
Its parts include 8 connectors and 2 resistors. It belongs with the ESP32 boards of this library.
Project Status: ✅ Completed — Fully Operational
Custom 1/10-scale RC crawler integrating a custom KiCad PCB, ESP32 firmware, real-time sensor acquisition, Bluetooth Low Energy (BLE), and a Flutter mobile telemetry dashboard.
| Custom RC Crawler | Live Telemetry Dashboard |
|---|---|
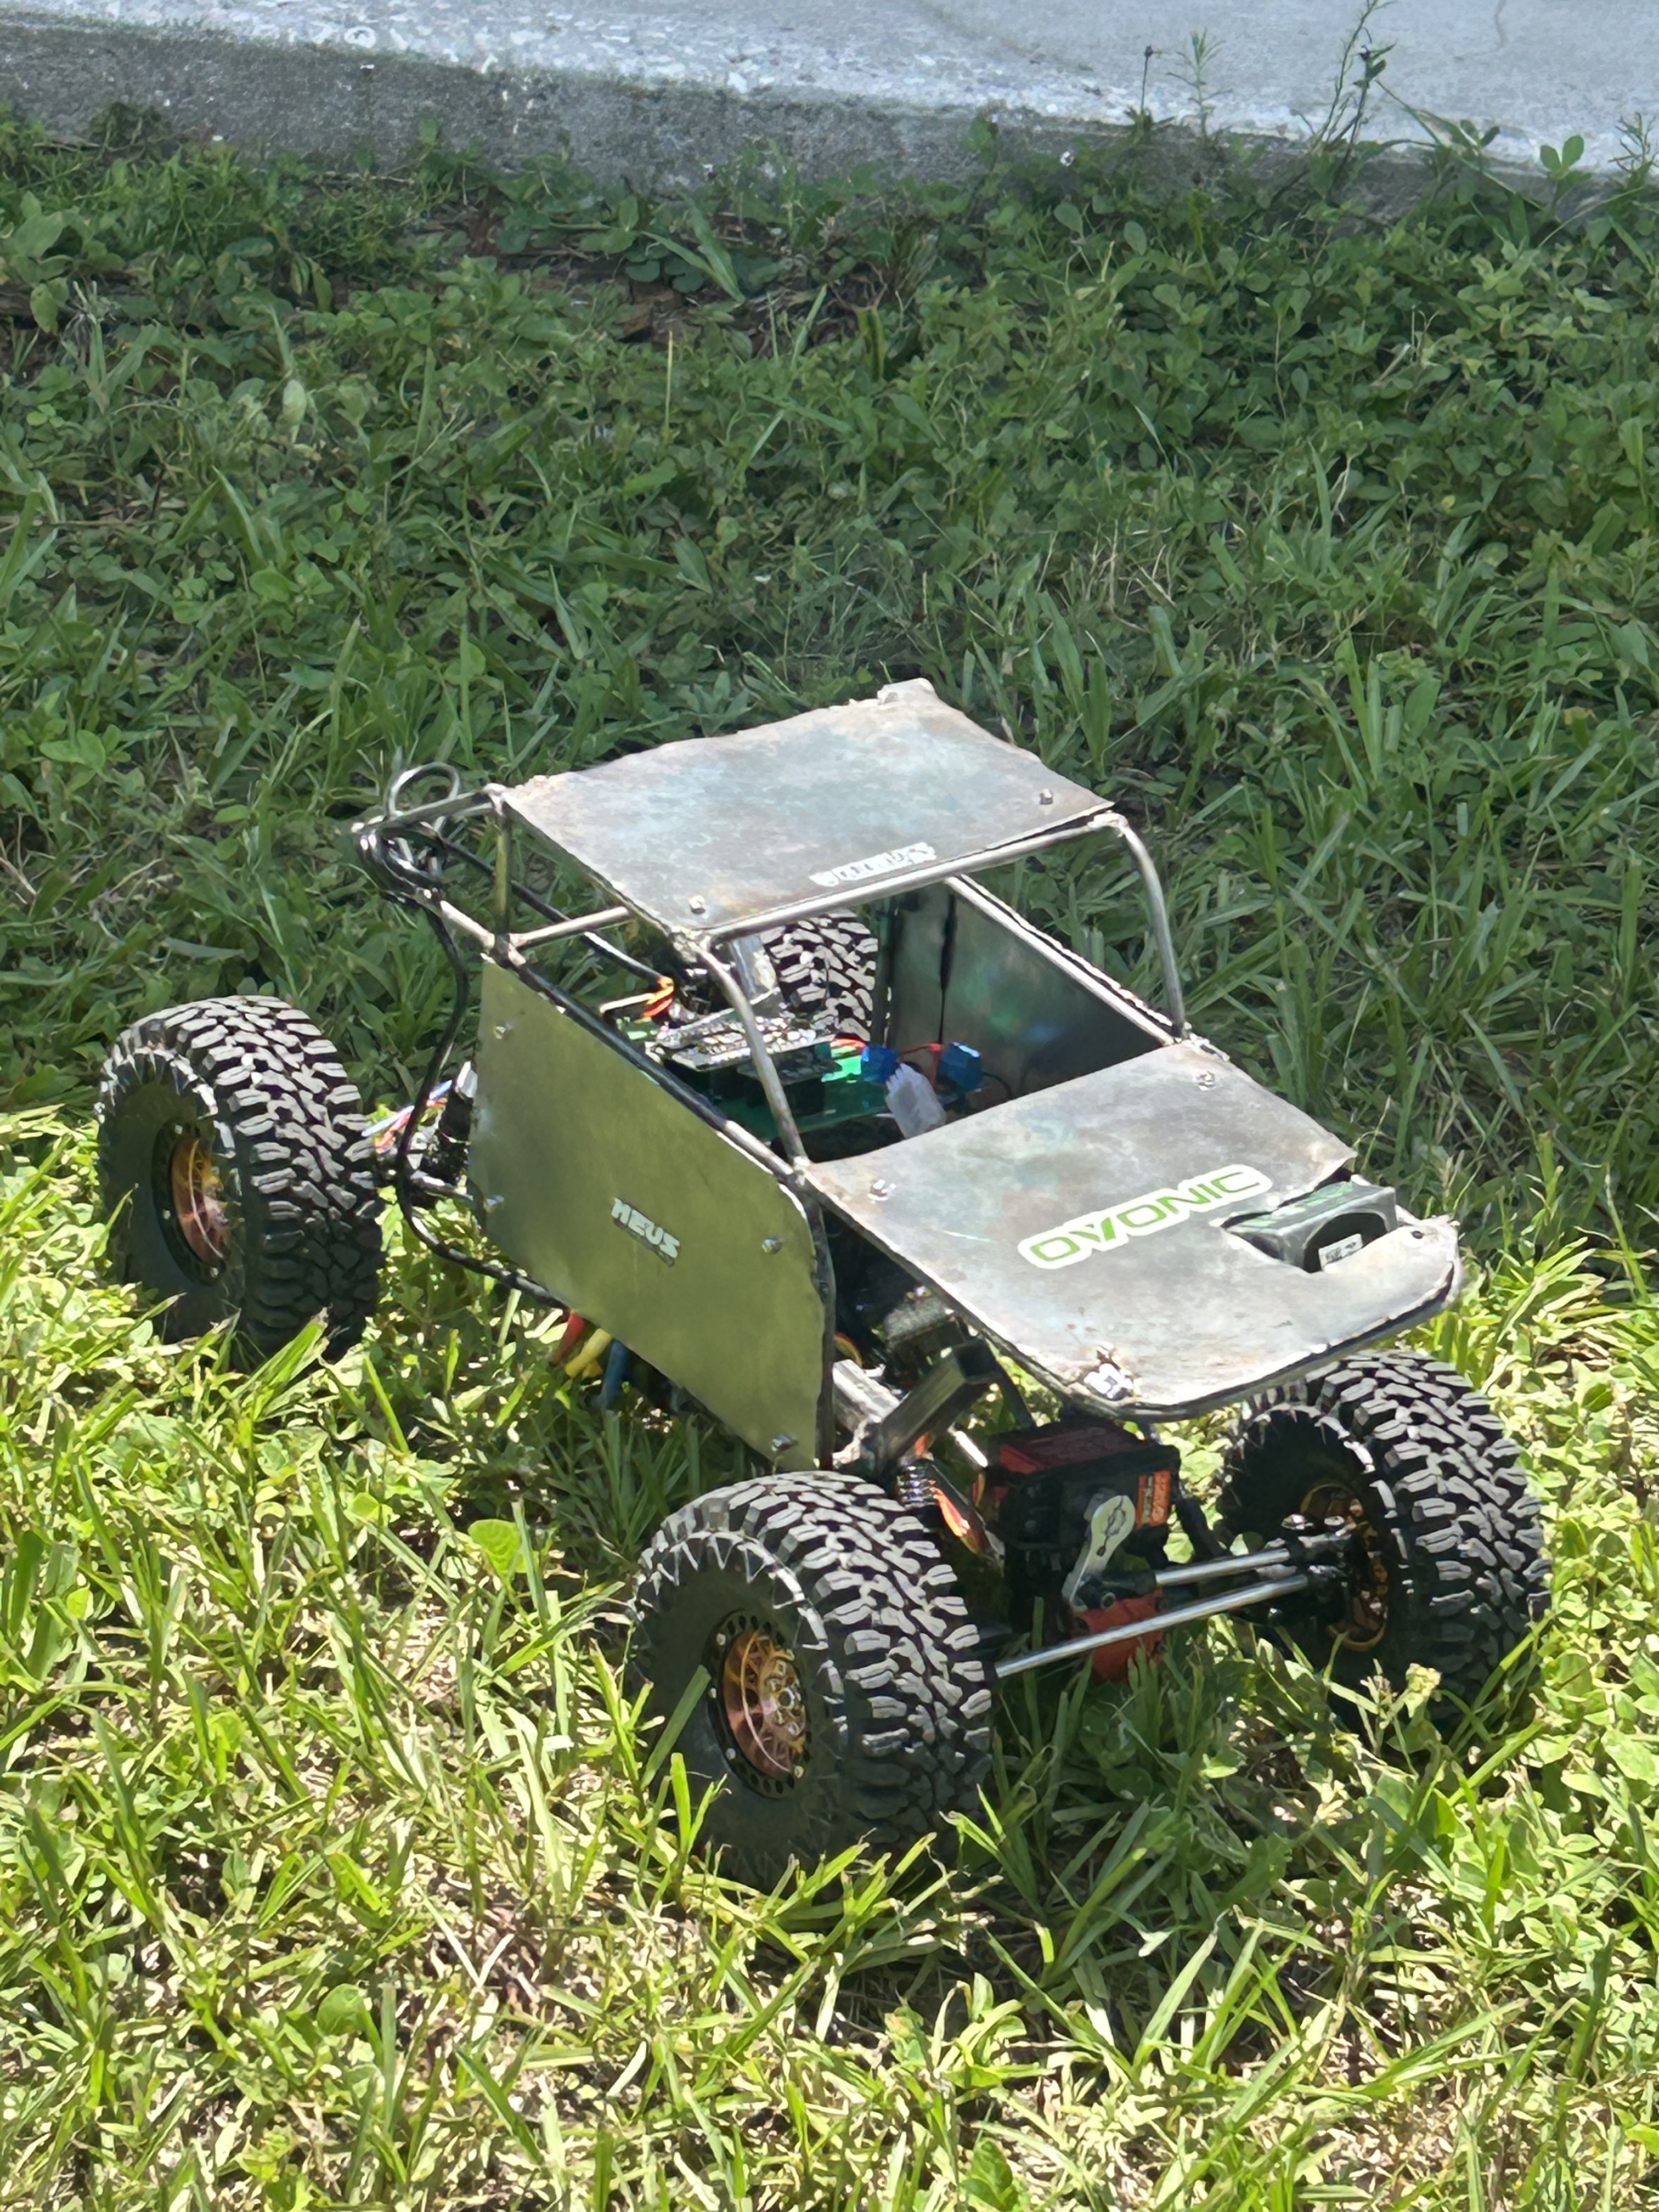 | 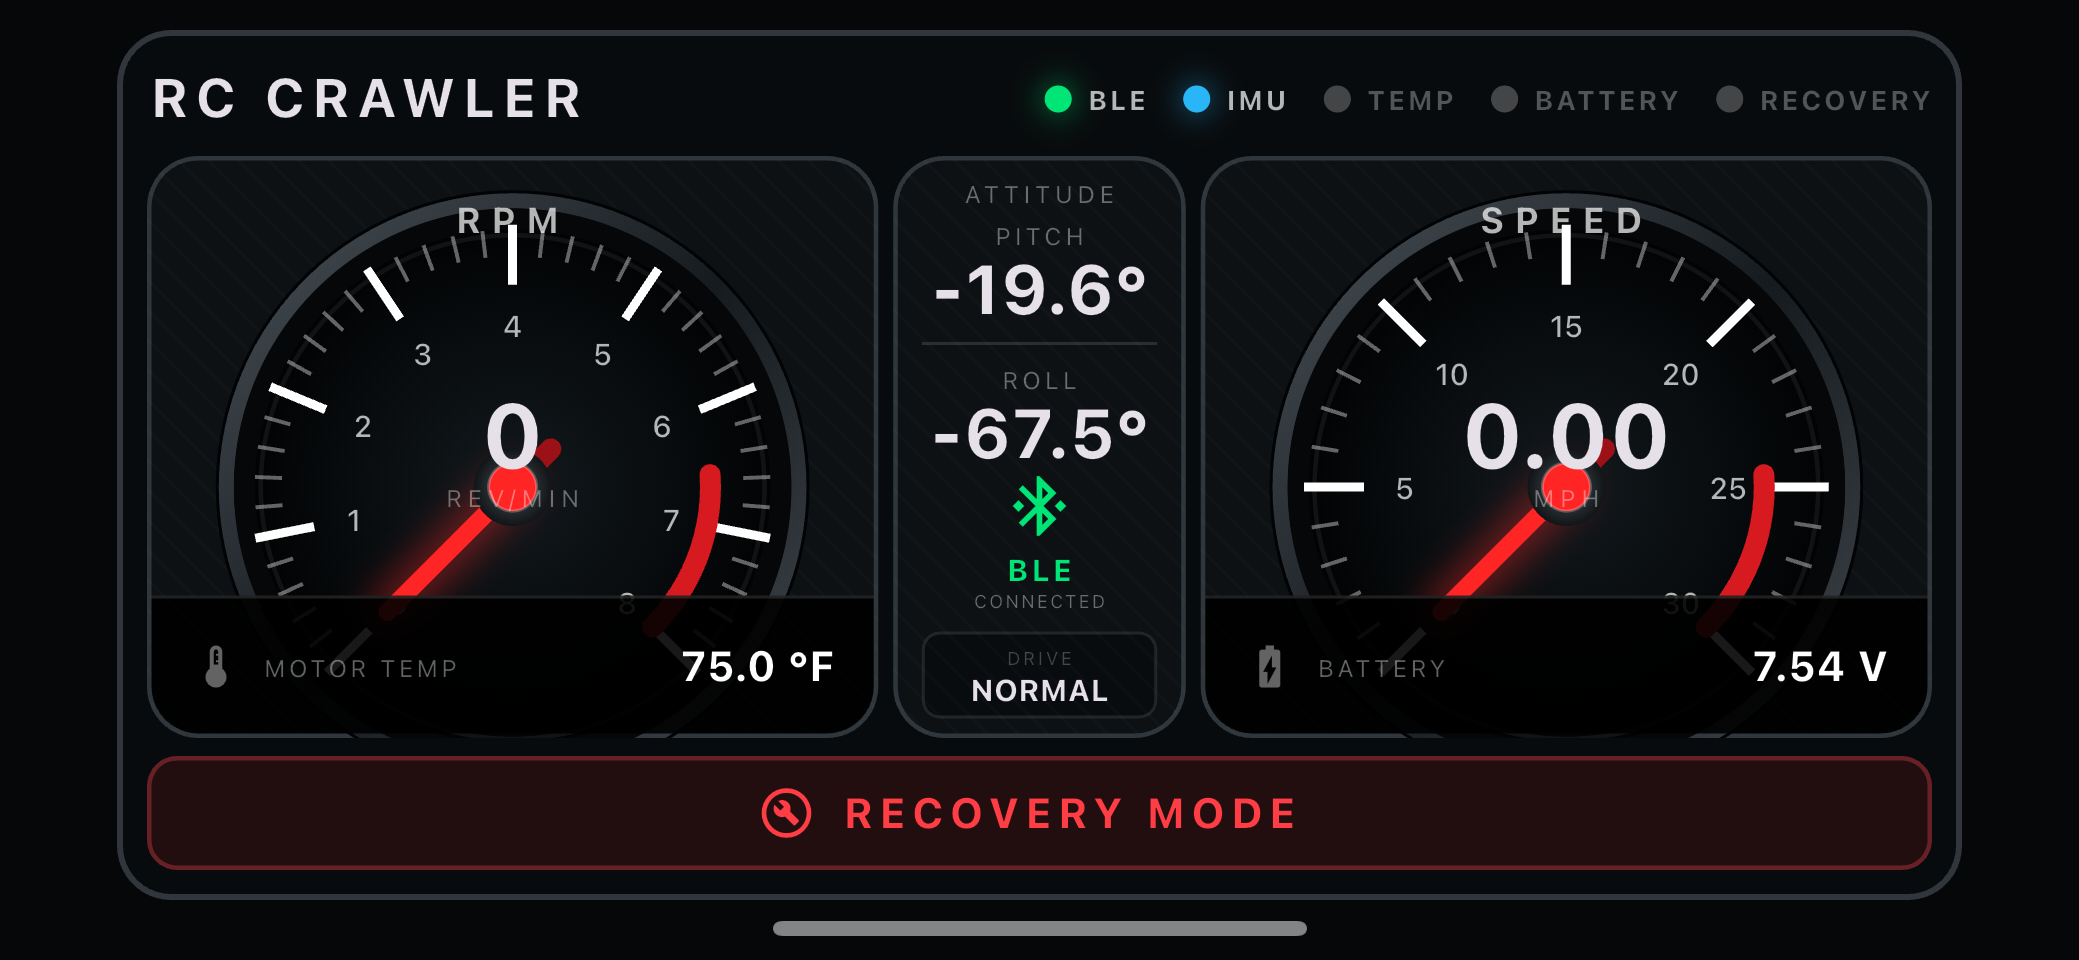 |
The RC Crawler Telemetry Platform is a complete embedded system designed to collect and display real-time vehicle data during operation.
An ESP32 integrated with a custom-designed KiCad PCB collects battery voltage, motor temperature, wheel RPM, and vehicle orientation. The firmware processes the sensor data, calculates vehicle speed, and transmits telemetry over Bluetooth Low Energy (BLE) to a custom Flutter/Dart mobile application.
The project covers the complete engineering workflow from mechanical fabrication and PCB design to embedded firmware, mobile development, hardware debugging, and real-world vehicle testing.
Hobby-scale RC vehicles provide limited visibility into important operating data such as temperature, battery voltage, speed, and vehicle orientation.
I built this platform to provide real-time onboard diagnostics through a wireless mobile dashboard.
Battery Voltage ─┐
Motor Temp ──────┤
Wheel RPM ───────┼──> ESP32 + Custom PCB ──> BLE ──> Flutter Dashboard
Pitch / Roll ────┘| Measurement | Sensor / Method |
|---|---|
| Battery Voltage | Voltage Sensor |
| Motor Temperature | DS18B20 |
| Wheel RPM | Hall-Effect Sensor |
| Vehicle Speed | Calculated from Wheel RPM |
| Pitch & Roll | BNO055 IMU |
| Wireless Telemetry | ESP32 BLE |
Real-world vehicle test demonstrating the custom PCB, ESP32 firmware, onboard sensors, BLE telemetry, and Flutter dashboard operating together on the crawler.
▶ Watch Ground Test on YouTube
Controlled drivetrain test demonstrating live RPM, calculated speed, battery voltage, motor temperature, pitch, and roll telemetry.
Maximum Calculated Unloaded Wheel Speed: 17.28 mph
▶ Watch Lifted-Wheel Telemetry Test on YouTube
Note: 17.28 mph represents unloaded calculated wheel speed, not verified ground speed.
During vehicle integration, the ESP32 began overheating and eventually stopped communicating. After replacing the ESP32, the same failure occurred again.
I systematically isolated the problem using a digital multimeter by:
Testing revealed that the PCB's original two-resistor voltage divider was not reducing the battery-sense voltage correctly, allowing excessive voltage to reach the ESP32.
I replaced the original voltage-divider implementation with the external voltage-sensor module used during the project's prototype stage. The module safely scales the battery voltage before the signal reaches the ESP32 ADC.
After implementing the fix, I restored and validated the complete telemetry system.
Result: Identified a repeated hardware failure, isolated the faulty subsystem, modified the circuit, and restored full system operation through measurement-driven troubleshooting.
Embedded: C++, ESP32, PlatformIO, Arduino Framework
Wireless: Bluetooth Low Energy (BLE)
Sensors: BNO055, DS18B20, Hall-effect sensor, voltage sensing
PCB: KiCad, schematic capture, PCB layout, soldering
Mobile: Flutter, Dart
Mechanical: MIG welding, custom steel chassis fabrication
Tools: Git, GitHub, VS Code, digital multimeter
├── firmware/       # ESP32 C++ firmware
├── hardware/       # KiCad PCB files, BOM, pinout & wiring
├── mobile_app/     # Flutter/Dart telemetry application
├── docs/           # Development & testing documentation
├── photos/         # Build and system photos
├── Videos/         # Demonstration videos
└── README.mdSuccessfully designed, fabricated, programmed, debugged, and tested a complete embedded telemetry platform capable of collecting, processing, transmitting, and displaying real-time vehicle data during operation.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 100k | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R1 |
| 1 | 47K | Resistor_THT:R_Axial_DIN0207_L6.3mm_D2.5mm_P7.62mm_Horizontal | R2 |
| 1 | BATTERY_SENSE | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J9 |
| 1 | BNO055_left | Connector_PinSocket_2.54mm:PinSocket_1x06_P2.54mm_Vertical | J4 |
| 1 | BNO055_right | Connector_PinSocket_2.54mm:PinSocket_1x04_P2.54mm_Vertical | J5 |
| 1 | Buck_5V_IN | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-2_1x02_P5.00mm_Horizontal | J1 |
| 1 | ESP32_LEFT | Connector_PinSocket_2.54mm:PinSocket_1x15_P2.54mm_Vertical | J2 |
| 1 | ESP32_right | Connector_PinSocket_2.54mm:PinSocket_1x15_P2.54mm_Vertical | J3 |
| 1 | Hall Sensor | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MKDS-1,5-3_1x03_P5.00mm_Horizontal | J7 |
| 1 | Temp sensor DS18B20 | Connector_PinSocket_2.54mm:PinSocket_1x03_P2.54mm_Vertical | J6 |
The 10 most common of 14 parts.
It measures 77 × 99 mm and has 2 copper layers, 1.6 mm thick.
14 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the DiezelBrown/RC-Crawler-Control-Telemetry-Platform repository on GitHub, at the commit this page was made from: the board is hardware/PCB/RC_Crawler_Telemetry_PCB/RC_Crawler_Telemetry_PCB.kicad_pcb and its schematic hardware/PCB/RC_Crawler_Telemetry_PCB/RC_Crawler_Telemetry_PCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask DiezelBrown before reusing the design.
google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


Twotoz/C5VRX
Ultra-minimal, zero-CPU 5.8 GHz analog FPV video receiver using ESP32-C5 Wi-Fi 6 PHY MODEM_DIAG, BitScrambler WBFM demodulation & resistor DAC CVBS

