2 layers62.7 × 70.3 mm
Mini robot car
bharathimurugesan-hue/mini-robot-car-pcb
Mini robot car PCB design developed using KiCad.
34 parts
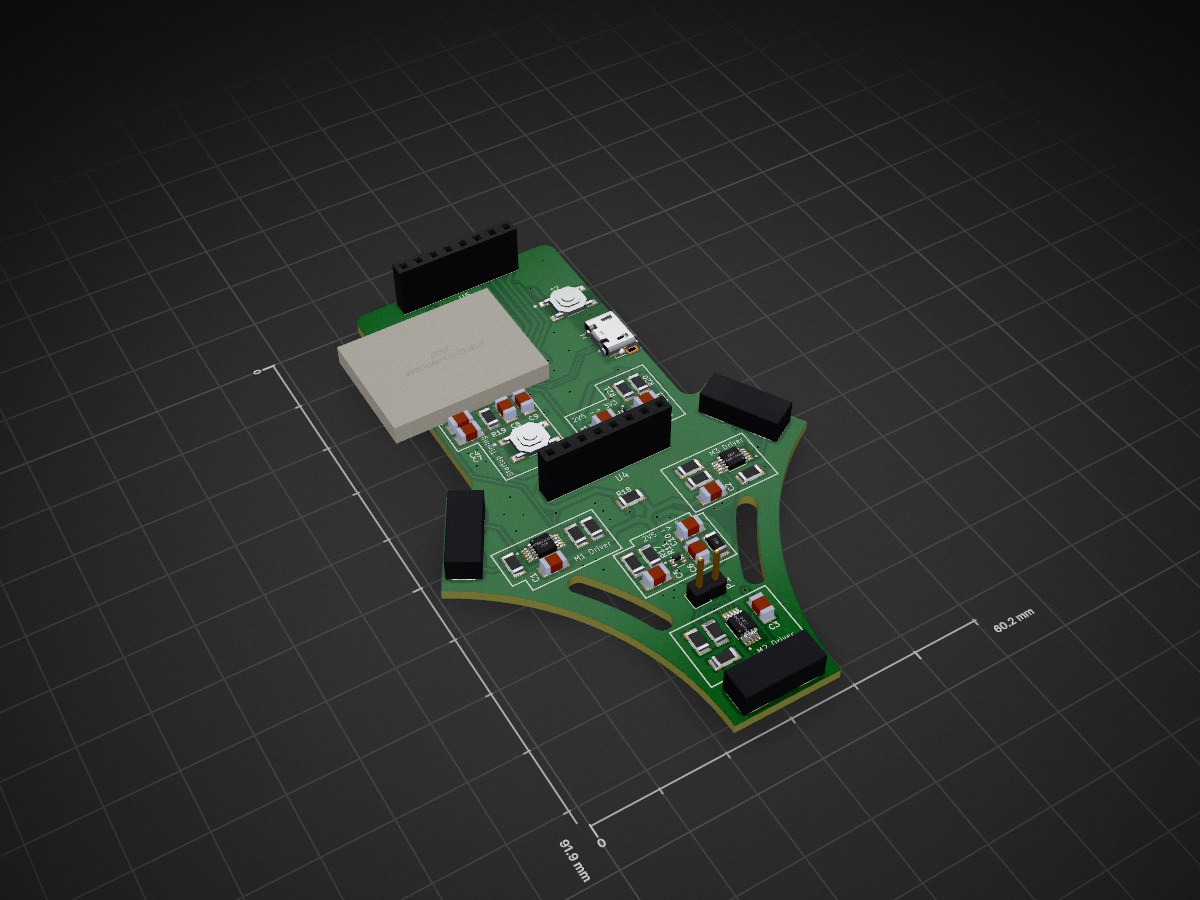
 devbyesh/rover
A rover built on the ESP32 chip coded with the ESPIDF framework. Can be controlled remotely and has an omniwheel setup to move in all directions without rotating.
Rover is an open-source printed circuit board by devbyesh, from the devbyesh/rover repository on GitHub. It is a 2-layer board of 60.2 × 91.9 mm with 45 parts on 75 nets, routed with 365 tracks and 62 vias.
It is built around the ESP32-S3-WROOM-1-N4, DRV8832DGQR and SKQGAFE010. Its parts include 15 resistors, 13 capacitors, 8 ICs, 5 connectors and 2 switches. It belongs with the robots and motor control boards and the ESP32 boards of this library.


A rover built on the ESP32 chip coded with the ESPIDF framework. Can be controlled remotely and has an omniwheel setup to move in all directions without rotating. There is a gyroscope to further prevent unwanted rotation.
There is also a v2 underway. I have only figured out the electronics and havent had time to fabricate it yet.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | 10uF | Library:CAPC3216X140N | C1, C2, C3, C5, C11 |
| 5 | 22uF | Library:CAPC3216X140N | C6, C7, C10, C12, C13 |
| 4 | 10kOhms | Library:RESC3116X65N | R7, R8, R9, R19 |
| 3 | 2.87kOhms | Library:RESC3116X65N | R1, R2, R3 |
| 3 | 400mOhms | Library:RESC3116X65N | R4, R5, R6 |
| 3 | DRV8832DGQR | Library:IC_XTR111AIDGQR | U1, U2, U3 |
| 3 | ~ | Library:twopad | P2, P3, P4 |
| 2 | .1uF | Library:CAPC3216X140N | C4, C9 |
| 2 | 1uH | LQM31PN1R0M00L:INDC3216X95N | L1, L2 |
| 2 | SKQGAFE010 | SKQGAFE010:SW_SKQGAFE010 | S1, S2 |
| 2 | TPS61023DRLT | TPS61023DRLT:SOT50P160X60-6N | U6, U8 |
| 2 | ~ | Library:gyro | U4, U5 |
| 1 | 0Ohms | Library:RESC3116X65N | R18 |
| 1 | 100kOhms | Library:RESC3116X65N | R17 |
| 1 | 1050170001 | 1050170001:MOLEX_1050170001 | J1 |
| 1 | 150kOhms | Library:RESC3116X65N | R21 |
| 1 | 1uF | Library:CAPC3216X140N | C8 |
| 1 | 680kOhms | Library:RESC3116X65N | R20 |
| 1 | 732kOhms | Library:RESC3116X65N | R11 |
| 1 | ESP32-S3-WROOM-1-N4 | ESP32-S3-WROOM-1-N4:XCVR_ESP32-S3-WROOM-1-N4 | U7 |
| 1 | ~ | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | P1 |
It measures 60.2 × 91.9 mm and has 2 copper layers, 1.6 mm thick.
45 parts, built around the ESP32-S3-WROOM-1-N4, DRV8832DGQR and SKQGAFE010. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the devbyesh/rover repository on GitHub, at the commit this page was made from: the board is rover_elec/rover.kicad_pcb and its schematic rover_elec/rover.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask devbyesh before reusing the design.
bharathimurugesan-hue/mini-robot-car-pcb
Mini robot car PCB design developed using KiCad.

mmccoyd/hillside
Family of split ergonomic keyboards with three rows of six or five keys and a generous thumb arc


famichu/MagLevSwitch_ReferenceKeyboard
The reference keyboard for the MagLev Switch MX

johflo/Seeed-LoRa-E5_BME680
Seeed Wio E5 LoraWan BME680 node without seperate MCU. Data from the BM680 is sent through the Helium LoraWan network to Cayenne to visualize the measured data


jayis1/hacker-devices
Full-cycle hardware designs for security research devices — each device is a subfolder with its own README, schematics, PCB layout, and software stack