
Final Version
elshazlio/ecng4504-maze-solver_team_5
ECNG 4504 (AUC, Spring 2026): autonomous maze-learning & solving robot — MCU (Arduino), Python BLE host app, KiCAD/docs, team deliverables. Single monorepo per course charter.

A multipurpose rover PCB for arduino projects using ESP32
Rover robot is an open-source printed circuit board by deuteros76, from the deuteros76/rover-robot-PCB repository on GitHub. It is a 2-layer board of 63.8 × 47.8 mm with 20 parts on 31 nets, routed with 169 tracks and 0 vias.
It is built around the L298N and TCRT5000. It belongs with the robots and motor control boards and the ESP32 boards of this library.
This is a multipurpose PCB for Arduino projects using ESP32. The main objective is to create a board to make robots easily but it can be used also to create different types of DIY projects such as a weather station.
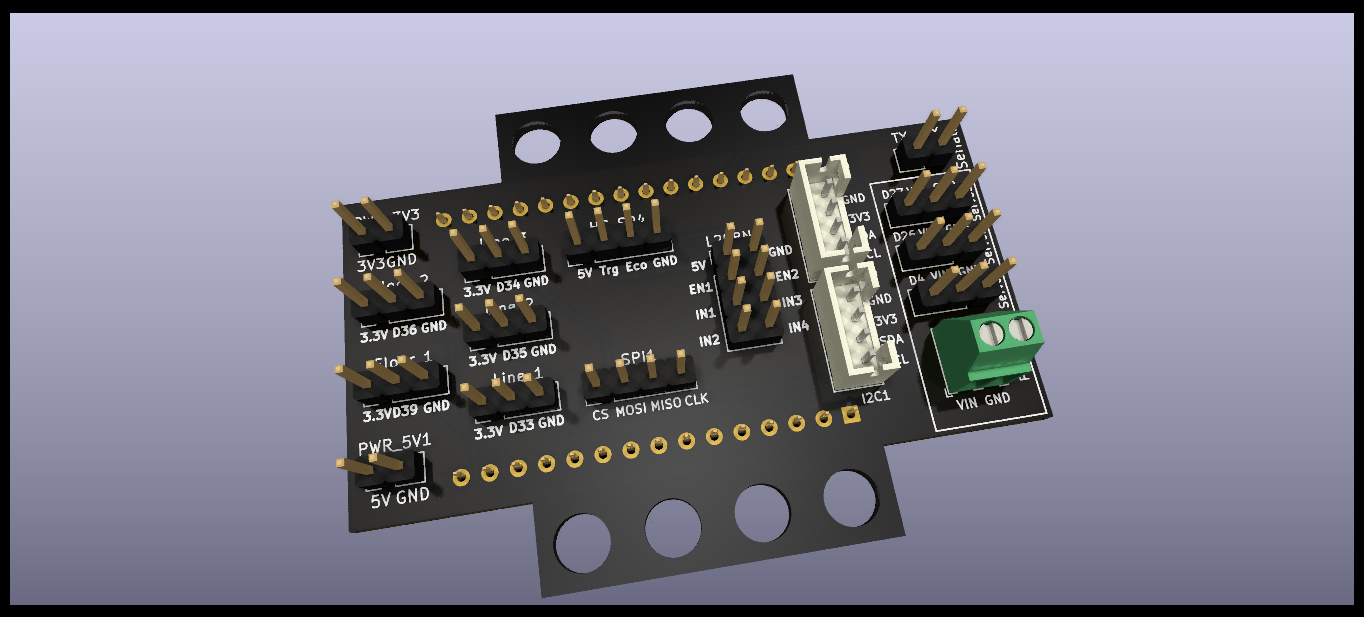
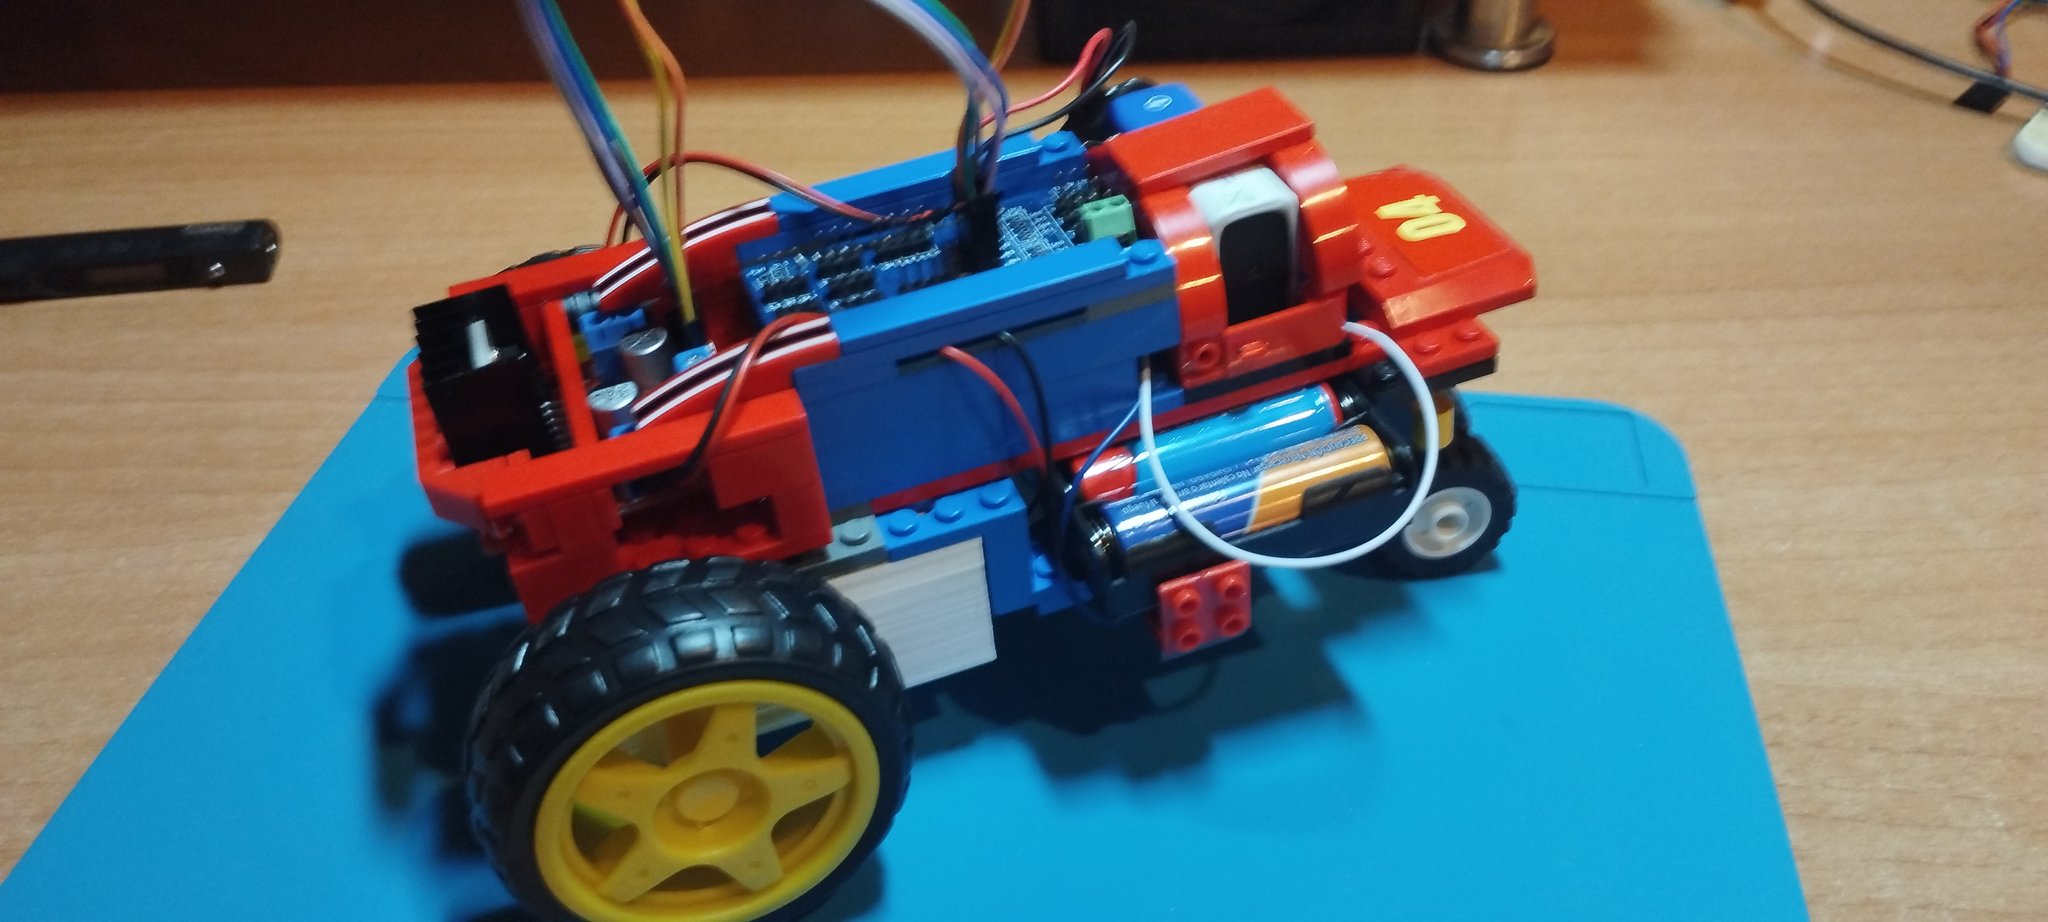
It could be programmed using PlatformIO, Pictoblox, Arduinoblocks, etc. Then, it can be mounted in a structure made of universal/compatible toy bricks. This makes this board a good option for educational purposes with kids.
Currently I'm working on a remote controlled vehicle programmed in Pictoblox. I'm constantly modifying the design and you can follow the updates in my X account:
This repository will contain the latest version of the PCB and soon, examples of source code for robots, remote controlled vehicles and perhaps other kind of inventions.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 5 | TCRT5000 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | Floor_1, Floor_2, Line_1, Line_2, Line_3 |
| 3 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | Servo1, Servo2, Servo3 |
| 2 | I2C | Connector_JST:JST_PH_B4B-PH-K_1x04_P2.00mm_Vertical | I2C1, I2C2 |
| 1 | Conn_01x04_Pin | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | SPI1 |
| 1 | Conn_3V3 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | PWR_3V3 |
| 1 | Conn_5V | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | PWR_5V1 |
| 1 | ESP32_DevKit_V1_DOIT | ESP32_DevKit_V1_DOIT:esp32_devkit_v1_doit_simplified | ESP32_DevKit_V1_DOIT1 |
| 1 | HC SR04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | HC_SR4 |
| 1 | KiCad-Logo2_5mm_SilkScreen | Symbol:KiCad-Logo2_5mm_SilkScreen | KiCad |
| 1 | L298N | Connector_PinHeader_2.54mm:PinHeader_2x04_P2.54mm_Vertical | L298N1 |
| 1 | Screw_Terminal_01x02 | TerminalBlock_Phoenix:TerminalBlock_Phoenix_MPT-0,5-2-2.54_1x02_P2.54mm_Horizontal | Power1 |
| 1 | Serial | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | Serial1 |
The 19 most common of 20 parts.

elshazlio/ecng4504-maze-solver_team_5
ECNG 4504 (AUC, Spring 2026): autonomous maze-learning & solving robot — MCU (Arduino), Python BLE host app, KiCAD/docs, team deliverables. Single monorepo per course charter.

Squalius-cephalus/OpenRidingController
D.I.Y horse riding controller for the PC.


xtarke/automated_buggy
This shield connects microcontroller (MSP-EXP430FR2355) pins to the car's power board. Go to Power Board for more hardware information.

Amrlxyz/esp-lfr-buggy
2nd Year Embedded Systems Project (ESP) - Line Following Robot Buggy


ciiiutnfrc/eduromaa
Versión educativa del robot móvil RoMAA (EduRoMAA)

billtsol/Maze
This project demonstrates how to use an Arduino board, IR sensors, and a motor driver shield to create a maze-solving robot.
It measures 63.8 × 47.8 mm and has 2 copper layers, 1.6 mm thick.
20 parts, built around the L298N and TCRT5000. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the deuteros76/rover-robot-PCB repository on GitHub, at the commit this page was made from: the board is Rover robot/Rover robot.kicad_pcb and its schematic Rover robot/Rover robot.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask deuteros76 before reusing the design.