2 layers50 × 35 mm

 DBG-Robots/PI5-HAT-relocator
A simple, shallow KiCad board that lets the Kinematics Kit HAT fit into a narrow robot frame: female connectors on top, male connectors on bottom.
MotorControllerHeader is an open-source printed circuit board by DBG-Robots, from the DBG-Robots/PI5-HAT-relocator repository on GitHub, published under the GPL-2.0 licence. It is a 2-layer board of 50.3 × 56 mm with 17 parts on 11 nets, routed with 55 tracks and 417 vias.

A simple, shallow KiCad board that lets the Kinematics Kit HAT fit into a narrow robot frame: female connectors on top, male connectors on bottom.
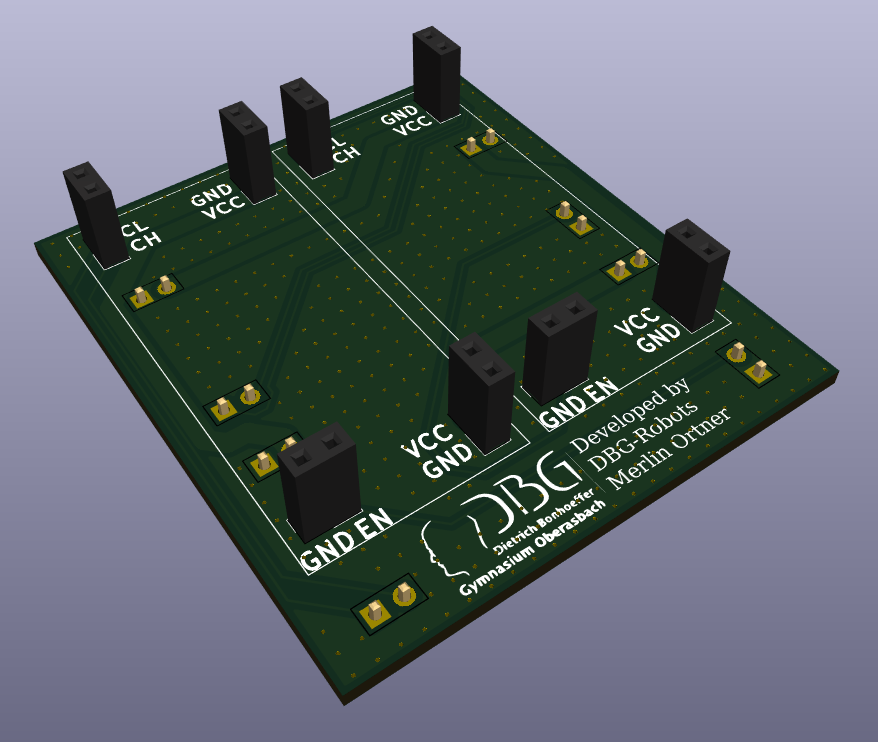
Our robot uses the Kinematics Kit by Eduard as its motor and drive electronics. In its canonical layout, the motor connectors stick out on the sides of the HAT. That is fine for most builds, but it costs width, and width is exactly what we do not have.
This board relocates the connectors of the HAT. Rotating the top part of the Kinematics Kit HAT by 90° brings the motor connectors out of the side-protruding position, so the entire Kinematics Kit fits fully inside our frame while staying within the 30 cm width limit and the low profile we need.
The board is intentionally simple:
| File | Description |
|---|---|
MotorControllerHeader.kicad_pro / .kicad_sch / .kicad_pcb | KiCad project, schematic and PCB layout |
PI5-HAT-relocator.step | 3D model of the assembled board |
production/ | Fabrication outputs (BOM, positions, netlist, zip) |
SketchPi2PHeaders.dxf | Mechanical sketch / outline reference |
Developed by DBG-Robots, Merlin Ortner (Dietrich-Bonhoeffer-Gymnasium Oberasbach). Kinematics Kit by Eduard.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1, J3, J5, J7, J9, J11, J13, J15 |
| 8 | Conn_01x02_Socket | Connector_PinSocket_2.54mm:PinSocket_1x02_P2.54mm_Vertical | J2, J4, J6, J8, J10, J12, J14, J16 |
| 1 | LOGO | LOGO | G*** |


hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

DDeGonge/OS-ARM
This arm is not industrial and it will not be fast, but that is not my goal. But it will hopefully be a very nice looking arm fully capable of 6dof motion, cheap enough to keep it accessable but capable enough to…


It measures 50.3 × 56 mm and has 2 copper layers, 1.6 mm thick.
17 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the DBG-Robots/PI5-HAT-relocator repository on GitHub, at the commit this page was made from: the board is MotorControllerHeader.kicad_pcb and its schematic MotorControllerHeader.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).