2 layers60.1 × 41.3 mm
Storper bumper
concretedog/stoRPer
stoRPer, a modular adaptable AWD Pico based robot rover
12 parts60CERN-OHL-P-2.0

 concretedog/stoRPer60
stoRPer, a modular adaptable AWD Pico based robot rover
Storper v0.2 is an open-source printed circuit board by concretedog, from the concretedog/stoRPer repository on GitHub, published under the CERN-OHL-P-2.0 licence. It is a 2-layer board of 64 × 86 mm with 36 parts on 42 nets, routed with 213 tracks and 9 vias.
Its parts include 8 resistors, 7 connectors, 5 ICs, 4 capacitors and 1 diode. It belongs with the robots and motor control boards of this library.
stoRPer, a modular adaptable AWD Pico based robot rover
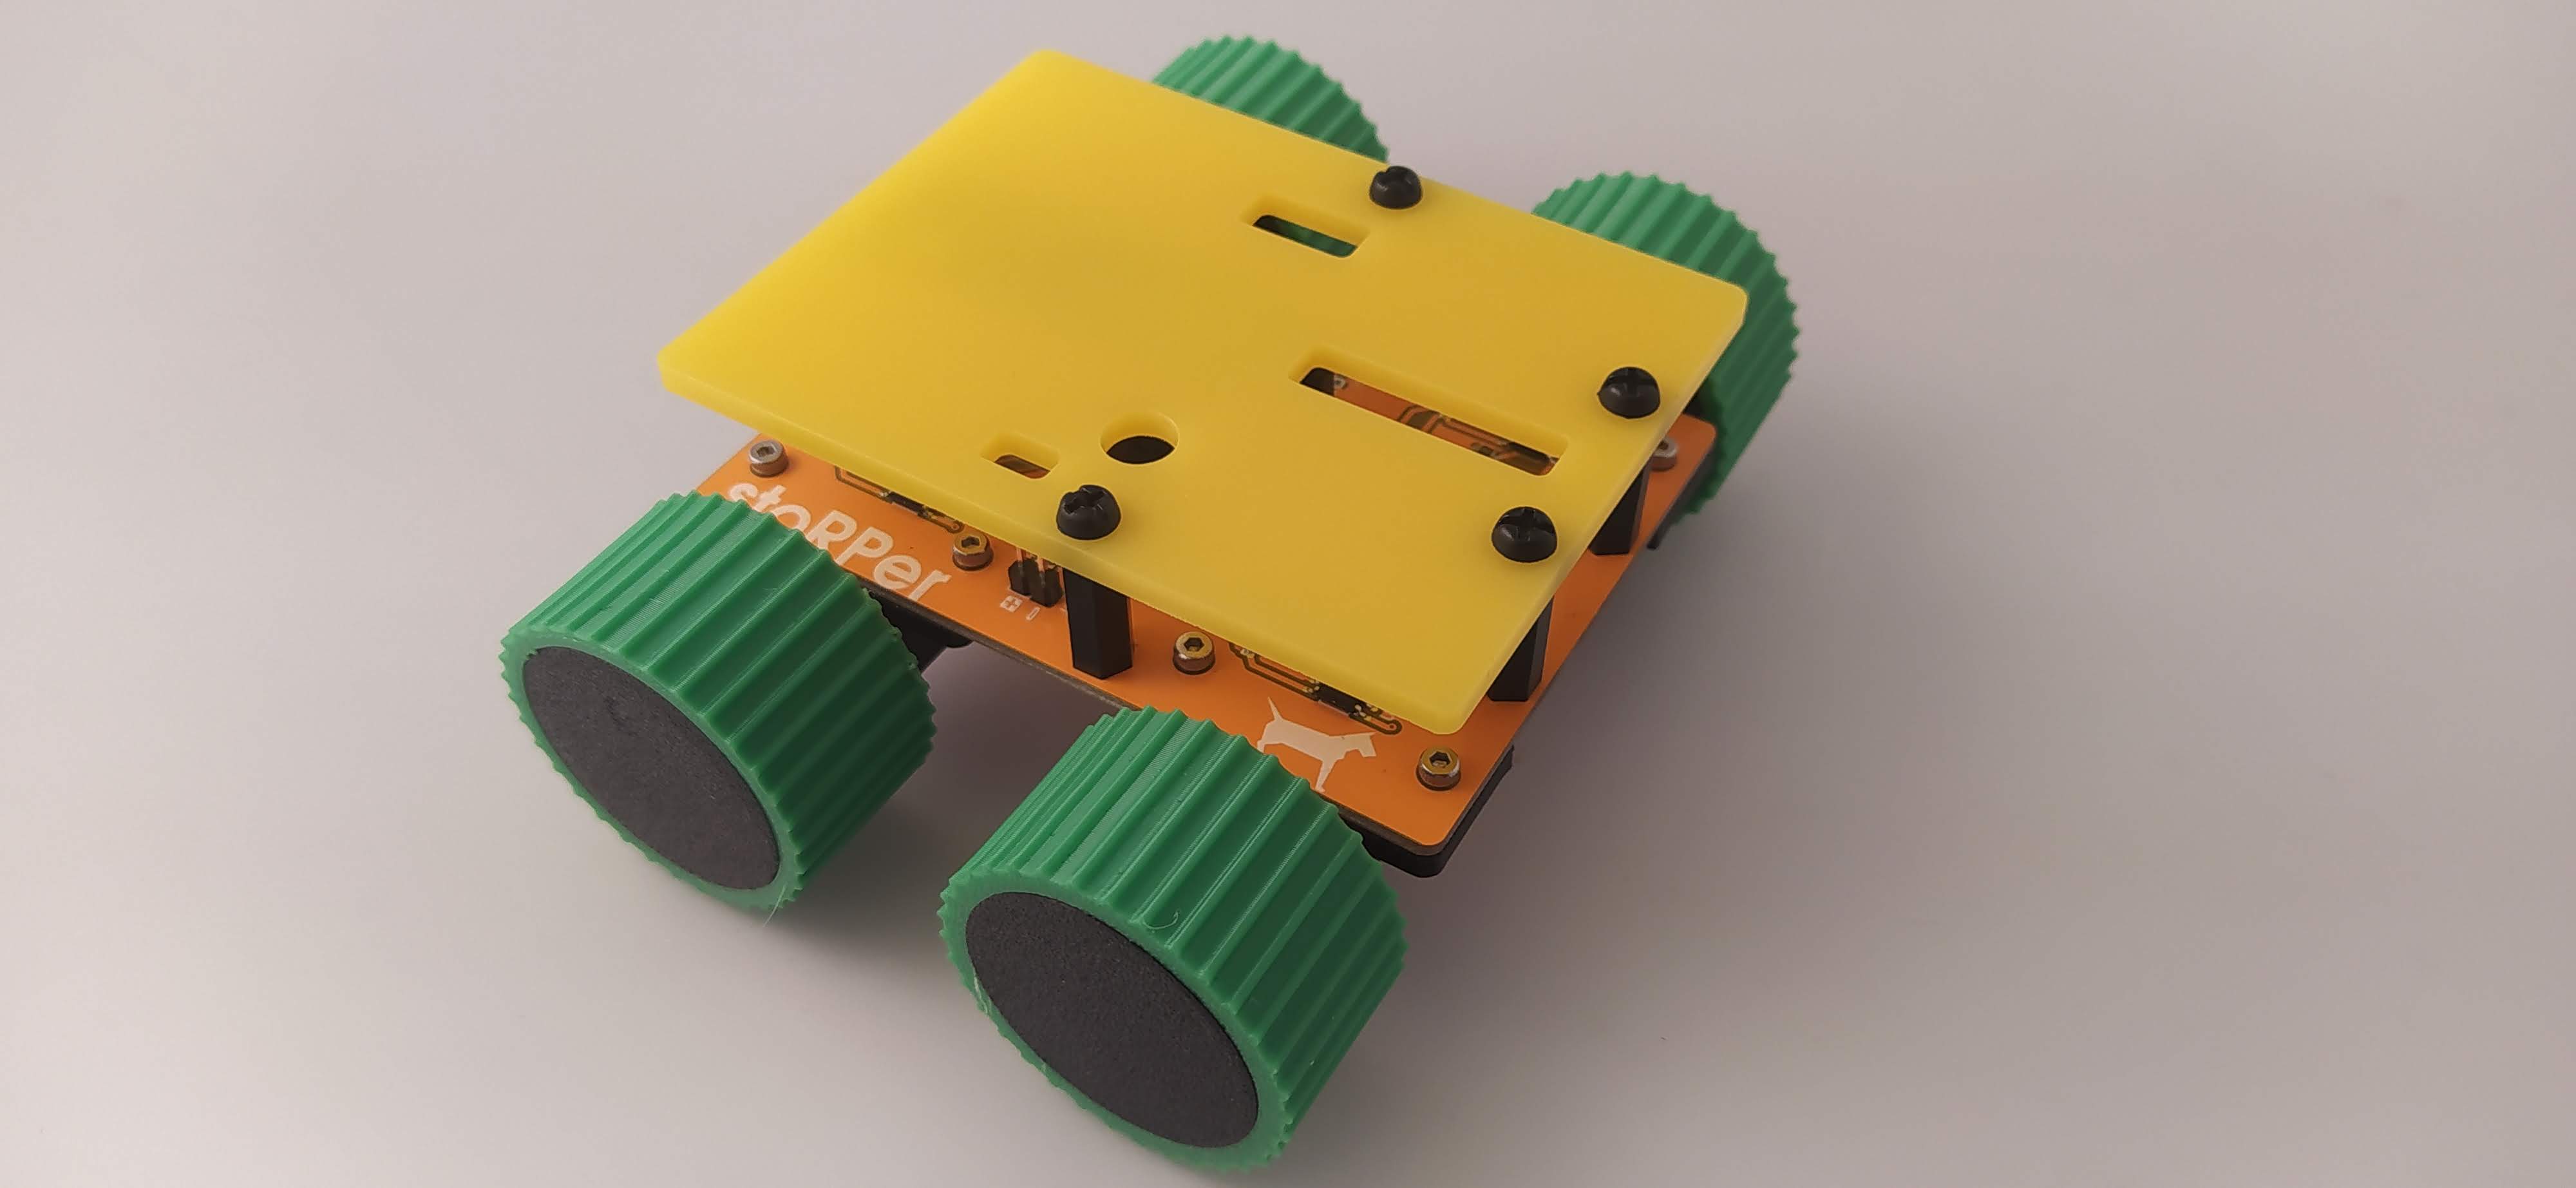
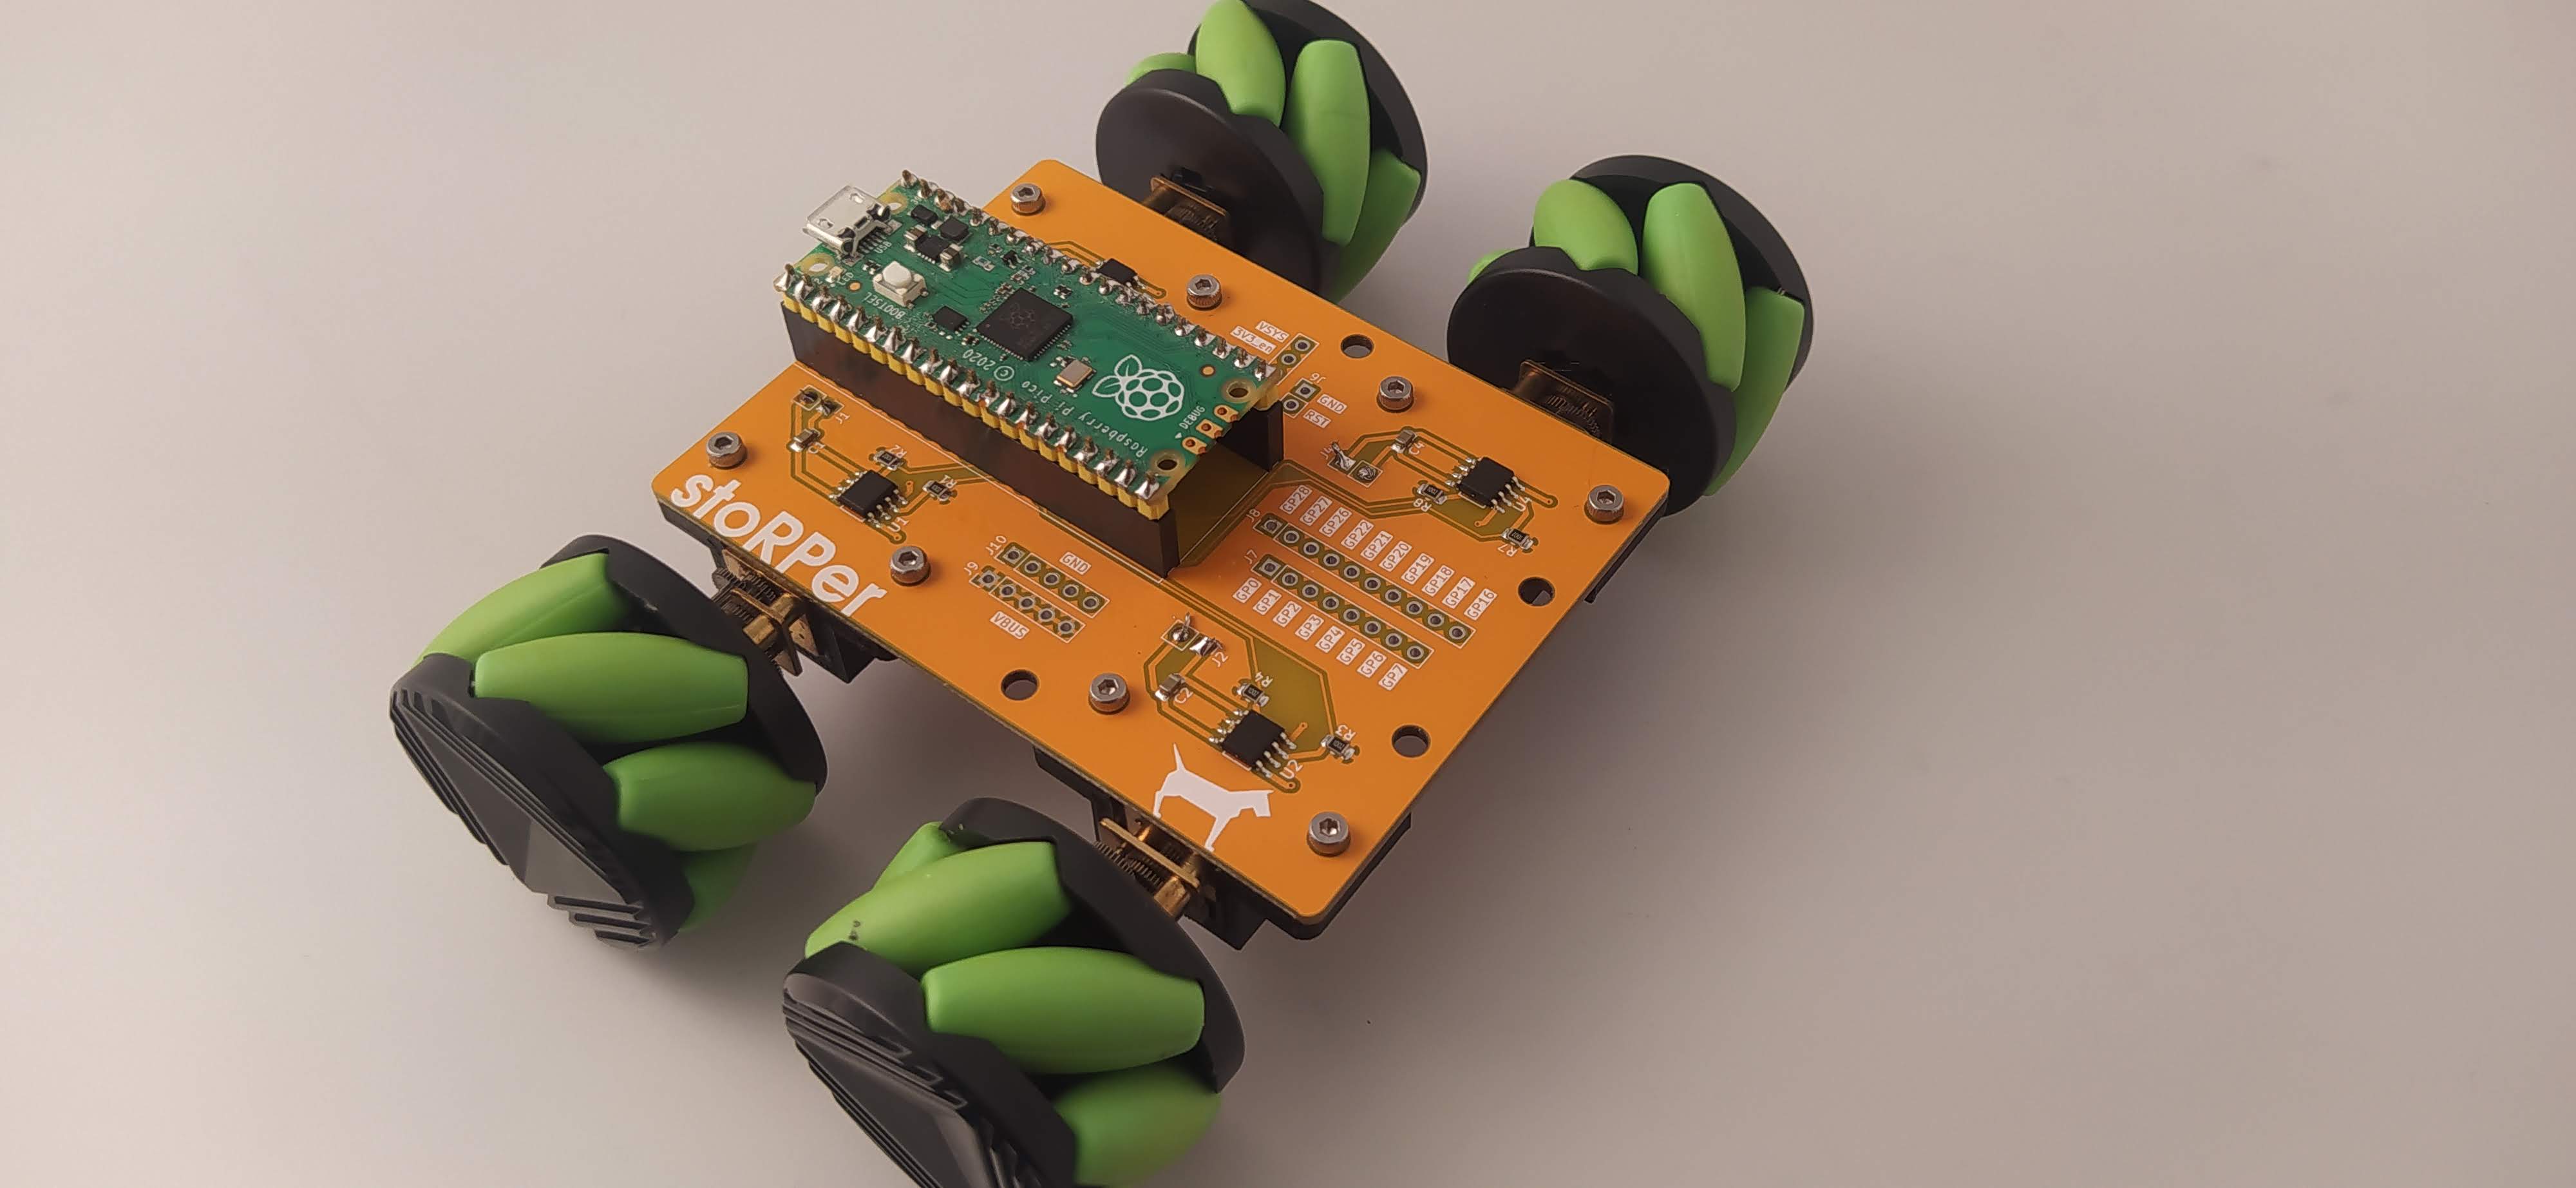
Check out the youtube video with details about the design and the design thinking, at the moment it's probably the best documentation!
Basic Bill Of Materials, This is just a guide for a basic build as you could build up the PCB in any way you can imagine!
But that's just a guide, you could use different items or design to the basic PCB/chassis in different ways.
All the KiCad files in the repo were originally made in version 7.xx.
Update 28-05-2024
Added an Addons folder which currently contains 2 new PCB designs.
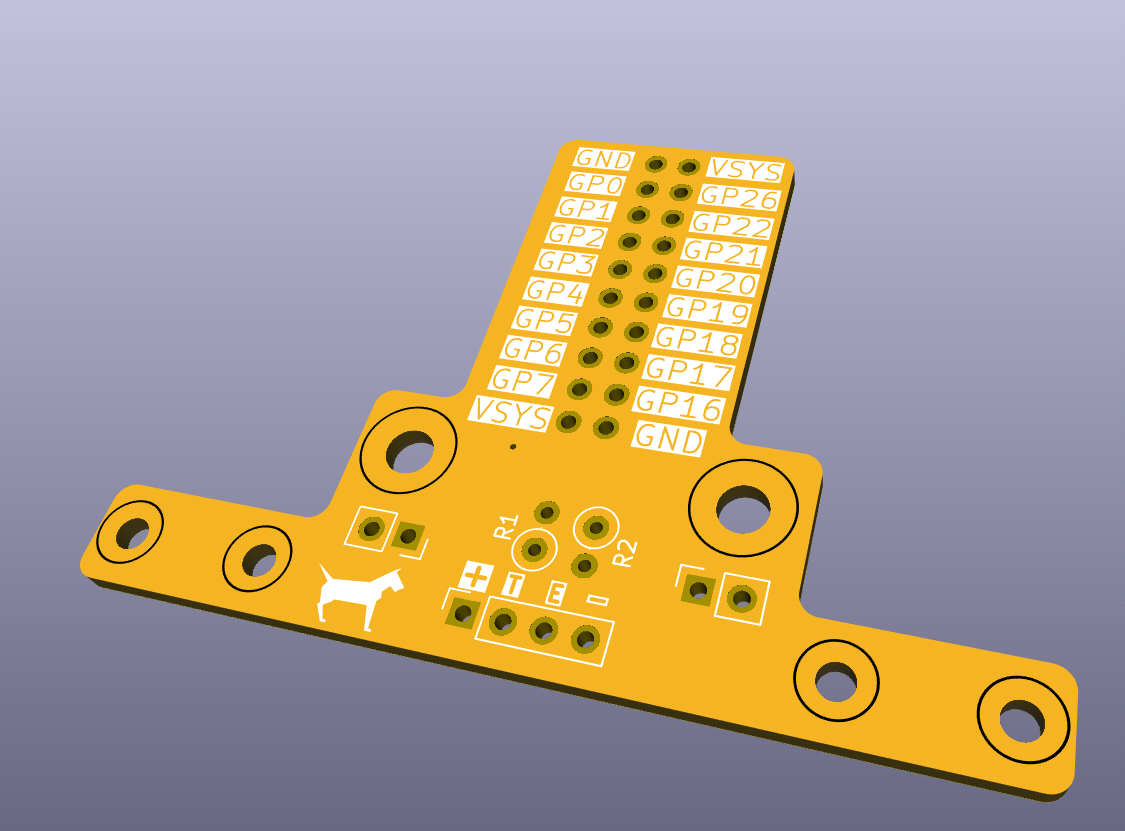
Bumper can receive an ultrasonic module (HC-SR04) and also have 2 bump switches connected.
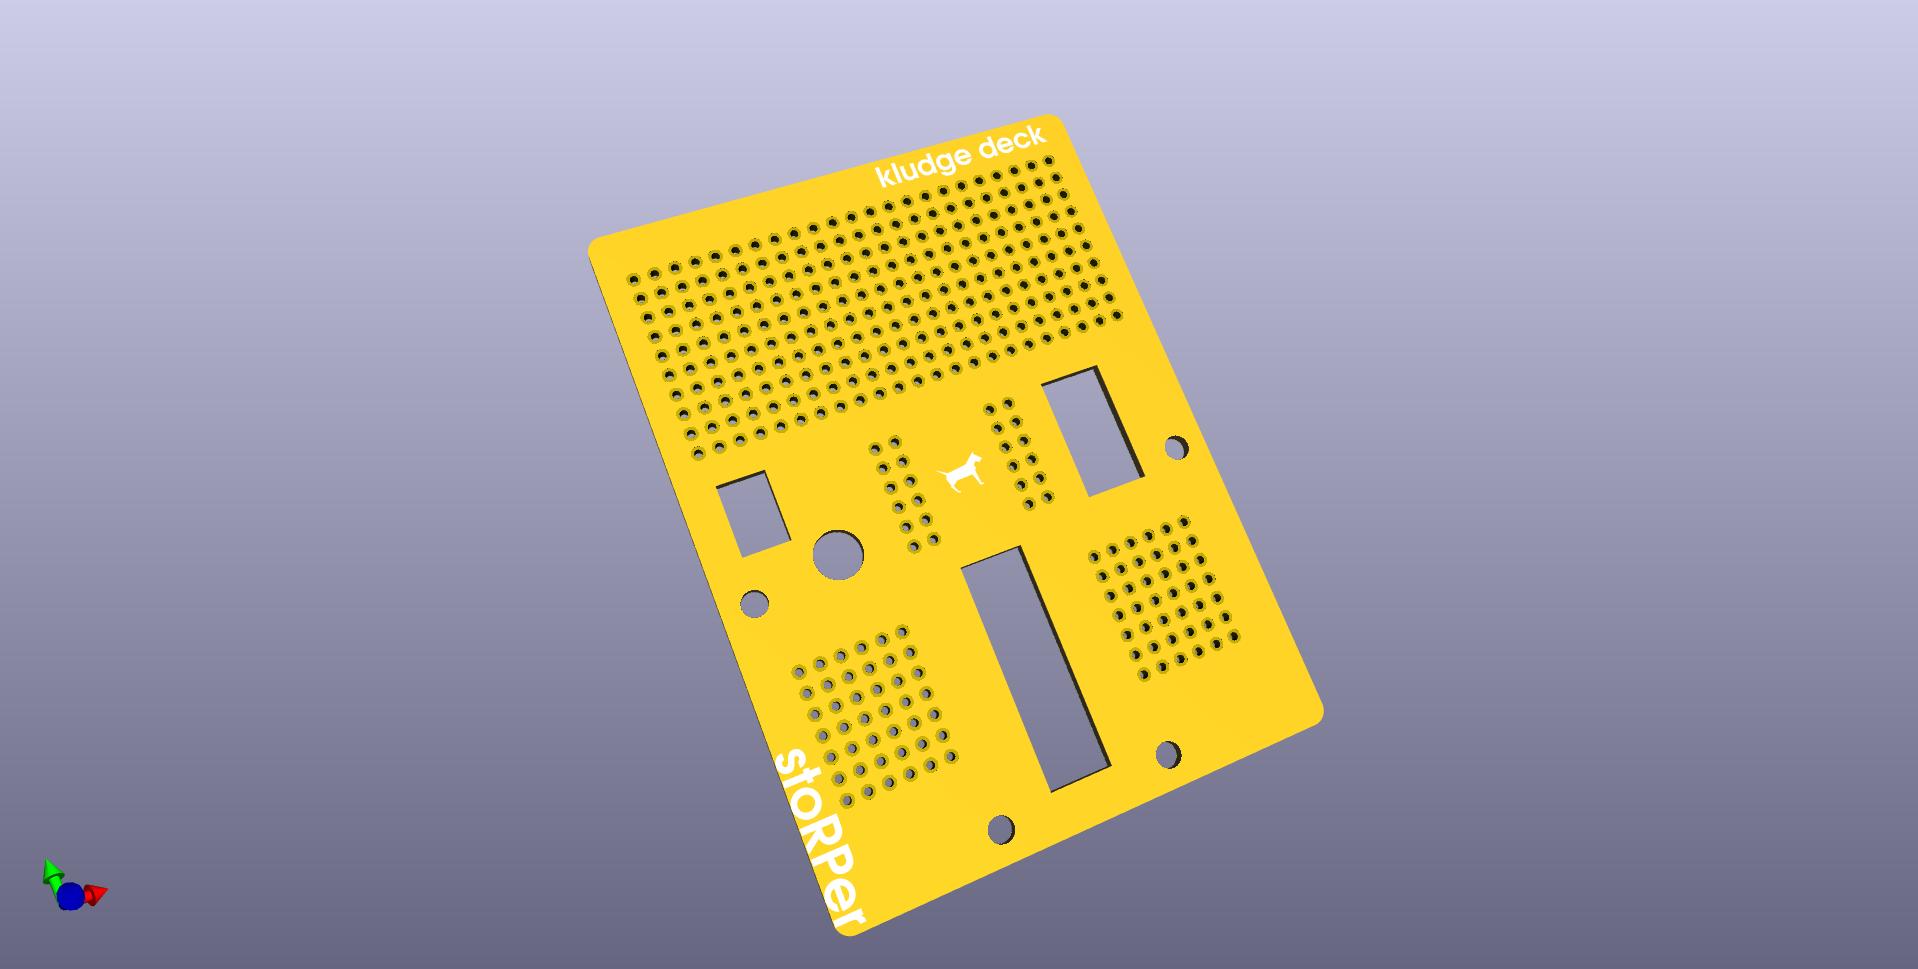
The Kludge Deck conforms to the StoRPer main PCB layout with lots of prototyping space and extra holes for mounting stuff!
Bumpers can be added above or below the main PCB with lots of different mount options. Therefore you might need to buy a range of standoffs to accomodate and support your design. If however you have access to a 3D printer there is a FreeCAD file in the 3D models section called STANDOFFS which you can simply adjust the length of a standoff tube that will slot over an M3 bolt. You can make custom lengths to suit your build.
Tiny Update 29-06-25
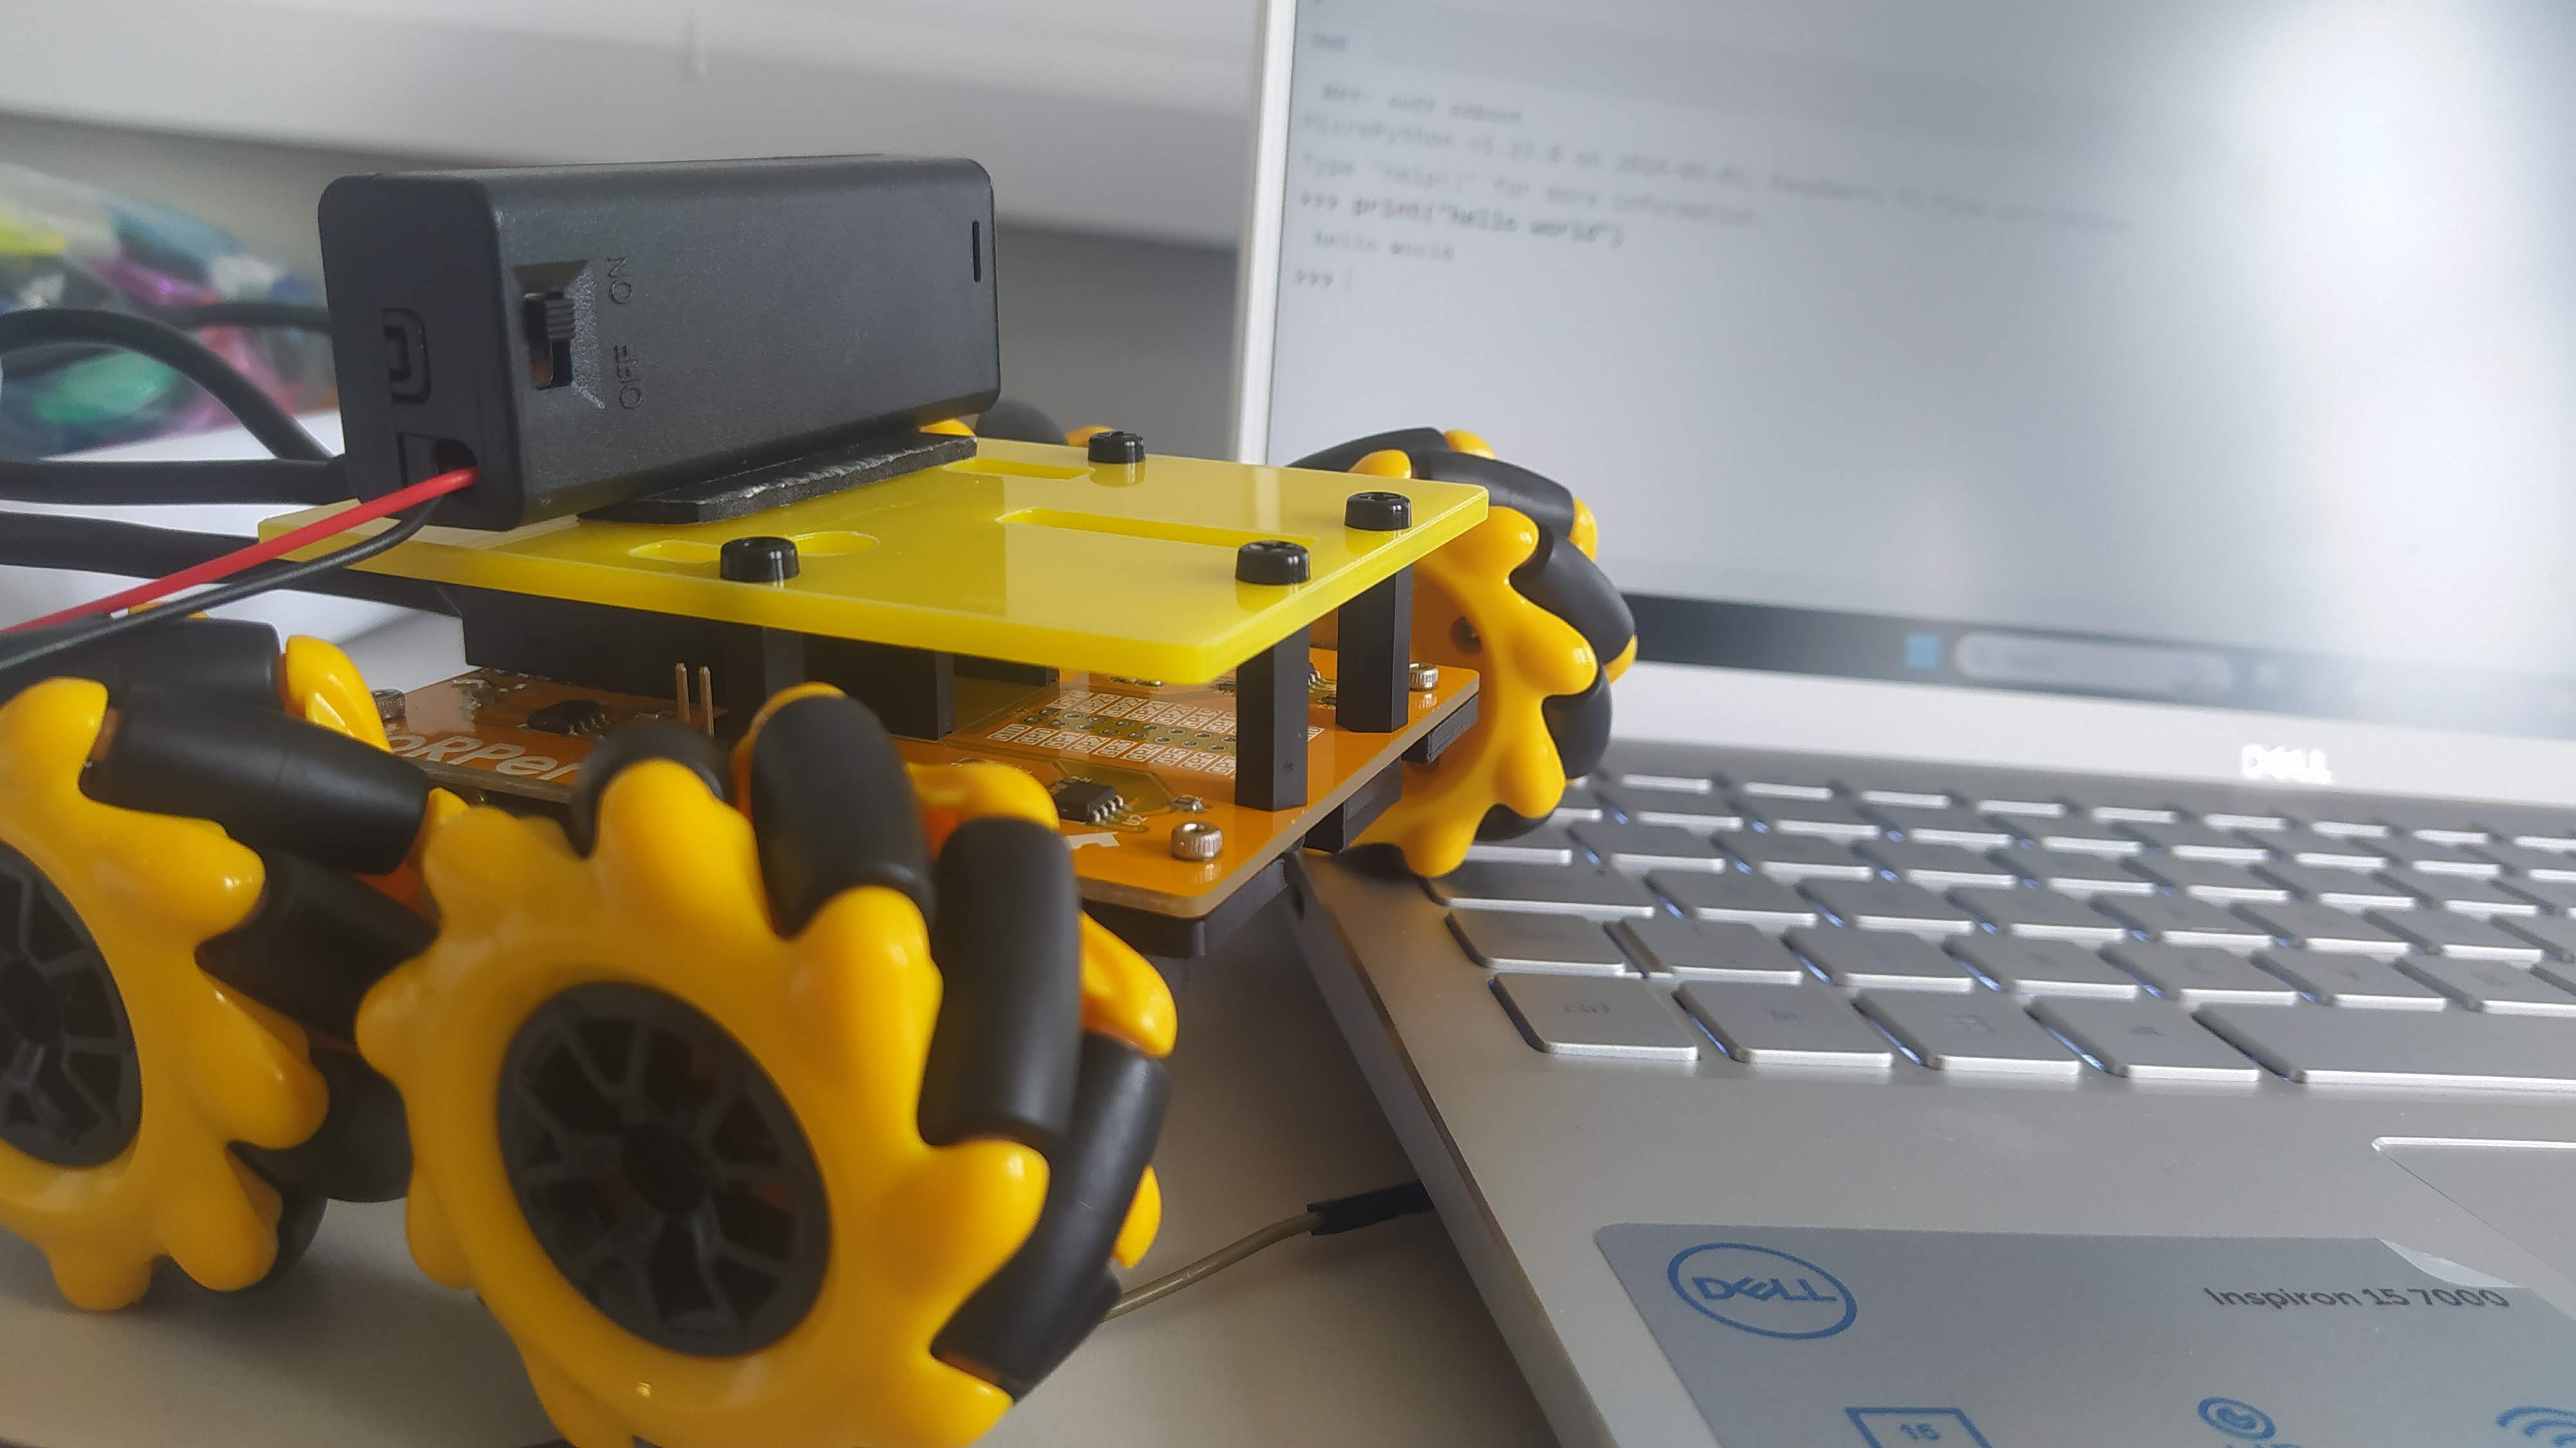
Added a small hex adaptor part to the 3D models section. I ran a workshop recently and wanted to use more affordable mecanum wheels and found some cheap 48mm mecanum wheels available on places like aliexpress etc. However they have a hexagonal axle mount. After numerous iterations and dialling in the 3D printing I made a super simple slip on adaptor part that sits inside the wheel and slots on snugly to the N20 motor mount. Useful for stoRPer of course, but useful for any N20 motor project.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | 10k | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2, R3, R4, R5, R6, R7, R8 |
| 5 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J1, J2, J3, J4, J11 |
| 4 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C2, C3, C4 |
| 4 | L9110_Motor_Driver | CDOG:L9110S_SOP-8_L4.9-W3.9-P1.27-LS6.0-BL | U1, U2, U3, U4 |
| 1 | Conn_02x05_Counter_Clockwise | CDOG:StoRPer_small_breakout | J5 |
| 1 | Conn_02x10_Counter_Clockwise | CDOG:stoRPer_breakout | J12 |
| 1 | D | CDOG:Diode_Schottky_SMB(DO-214AA) | D1 |
| 1 | ~ | CDOG:RP_Pico | U5 |
The 25 most common of 36 parts.
concretedog/stoRPer
stoRPer, a modular adaptable AWD Pico based robot rover

hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!


tardate/LittleArduinoProjects
a collection of "Little Electronic & Arduino Projects", most involving electronics or an Arduino in one way or another!


Neumi/open_echo
Open Source echo sounder / depth sounder / SONAR for bathymetry and research. Arduino based and compatible.


It measures 64 × 86 mm and has 2 copper layers, 1.6 mm thick.
36 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the concretedog/stoRPer repository on GitHub, at the commit this page was made from: the board is storper_v0.2/storper_v0.2.kicad_pcb and its schematic addons/ultrasonic_switch_bumper/storper_bumper.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the CERN-OHL-P-2.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).