2 layers213 × 65.1 mm
 ComNets-Bremen/WolfNet
The hardware / firmware for the mAInZaun project
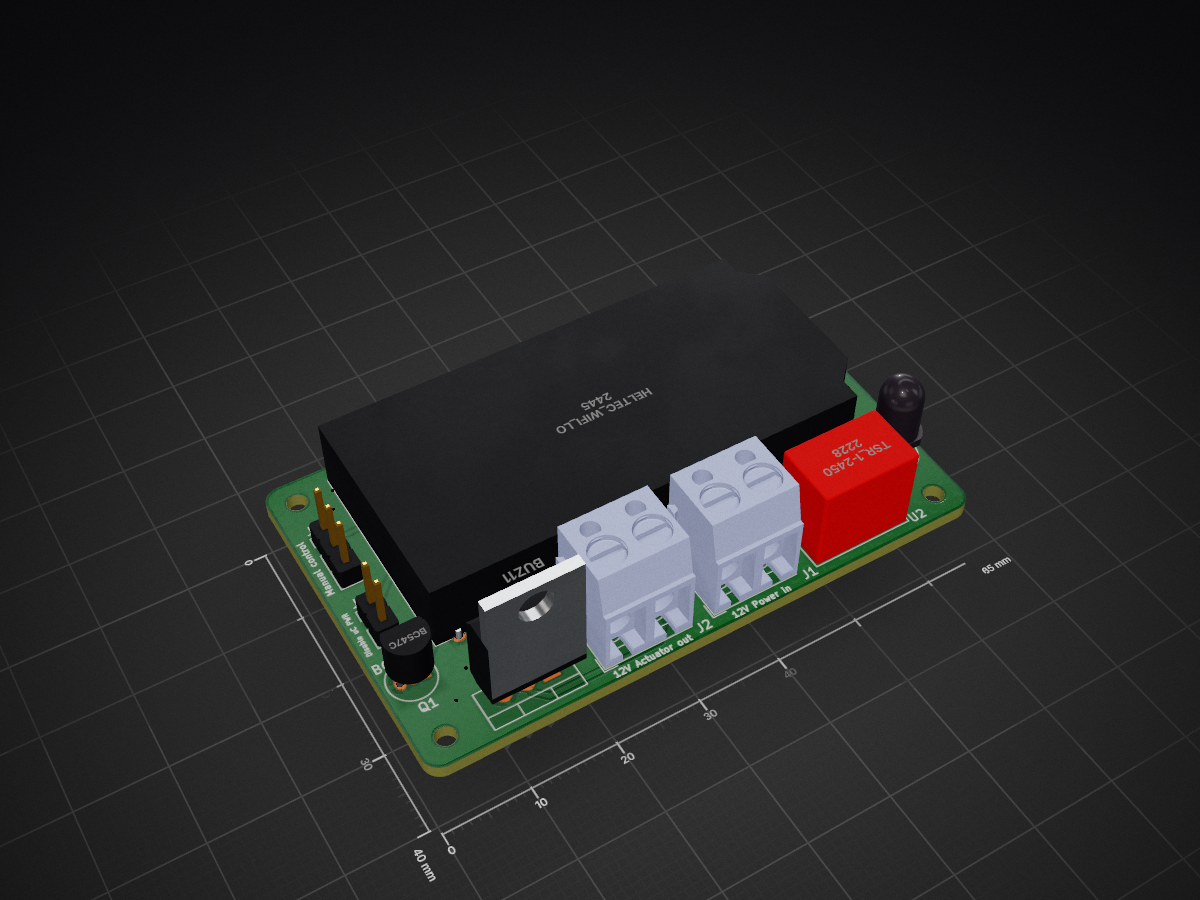
Actuator v2 is an open-source printed circuit board by ComNets-Bremen, from the ComNets-Bremen/WolfNet repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 65 × 40 mm with 19 parts on 41 nets, routed with 60 tracks and 39 vias.
It is built around the TSR 1-2450 and BC547C. Its parts include 6 resistors, 2 ICs, 2 transistors, 2 connectors and 1 diode. It belongs with the robots and motor control boards of this library.


The mAInZaun-Project is aiming on extending existing fence by using adaptive deterrents to scare away predators.
This part implements a simple protocol for the sensors and actuators: How can the deterrents be activated wirelessly if a predator is detected?
For that, we created our own, hand-crafted protocol using LoRa. The main packet formats are described in the file packets.md in this directory.
The complete stack is written in Micropython and using Heltec WiFi LoRa 32 v2 nodes. A migration to Heltec WiFi LoRa 32 v3 is planned in this issue.
Programming is done in Visual Studio Code using the pymakr-plugin. If you are getting an error while running the pymakr-plugin: Make sure you have installed NodeJS!
The idea is to have a box for the management of the complete (LoRa) system. It should have a touchscreen and basic interface for changing parameters like beaconing intervals or reading out the battery state.
Collection of all relevant datasheets
Contains the schematics as KICad files -- currently mainly the ones for the actuator boxes.
General tools which might be handy for debugging
The firmware itself which makes the sensors and the actuators communicate. It is a Visual Studio Code project and using the Pymakr-plugin.
The known issues can be found in the github issue tracker
The license of the code can be found in the LICENSE file.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 100 | Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_Horizontal | R3 |
| 1 | 10k | Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_Horizontal | R1 |
| 1 | 120 | Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_Horizontal | R6 |
| 1 | 12V Actuator out | TerminalBlock_RND:TerminalBlock_RND_205-00001_1x02_P5.00mm_Horizontal | J2 |
| 1 | 12V Power in | TerminalBlock_RND:TerminalBlock_RND_205-00001_1x02_P5.00mm_Horizontal | J1 |
| 1 | 15k | Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_Horizontal | R4 |
| 1 | 2k7 | Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_Horizontal | R5 |
| 1 | 4k7 | Resistor_THT:R_Axial_DIN0411_L9.9mm_D3.6mm_P12.70mm_Horizontal | R2 |
| 1 | BC547C | Package_TO_SOT_THT:TO-92_Inline | Q1 |
| 1 | BUZ11 | Package_TO_SOT_THT:TO-220-3_Vertical | Q2 |
| 1 | Disable uC PWR | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | JP1 |
| 1 | Heltec_Wifi_LoRa_V1 | Heltec_Wifi_Lora_v1:Heltec_WiFi_LoRa_V1 | U1 |
| 1 | LED | LED_THT:LED_D5.0mm_IRGrey | D1 |
| 1 | Manual control | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | JP2 |
| 1 | TSR_1-2450 | Converter_DCDC:Converter_DCDC_TRACO_TSR-1_THT | U2 |
The 15 most common of 19 parts.
It measures 65 × 40 mm and has 2 copper layers, 1.6 mm thick.
19 parts, built around the TSR 1-2450 and BC547C. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ComNets-Bremen/WolfNet repository on GitHub, at the commit this page was made from: the board is Schematic/Actuator_v2/Actuator_v2.kicad_pcb and its schematic Schematic/Actuator_v1/Actuator_v1.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).

curiouselectric/Lapse-O-Matic
This is code, PCB and enclosure design for an ESP32_CAM based wildlife camera

FabianGmeiner/BMW_E30_SI_Board
Reverse engineering and improving the BMW E30 service indicator board

sebastianbeyer/KOSMO_ladderfilter
KOSMO Version of the Kassutronics Transistor Ladderfilter

PhilmacFLy/kenwood-tnc
Simple TNC PCB to use a radio with a kenwood ptt connector with a pc to do packet radio

Ansel84/BMW-E30-Gauge-Cluster-Early-Model
This project is the documentation of reverse engineering the BMW E30 gauge cluster for pre 1988 model years.


almirpangor/VIHR-30-EFI
Блок управления впрыском и зажиганием для лодочного мотора «Вихрь-30»