6 layers140 × 70 mm
High speed
NBence0/JedlikBots
Welcome to the official GitHub page of JedlikBots! 🎓🤖 We are the dedicated team of software development and robotics students from the Jedlik Ányos Technical School in Győr, Hungary.
274 parts
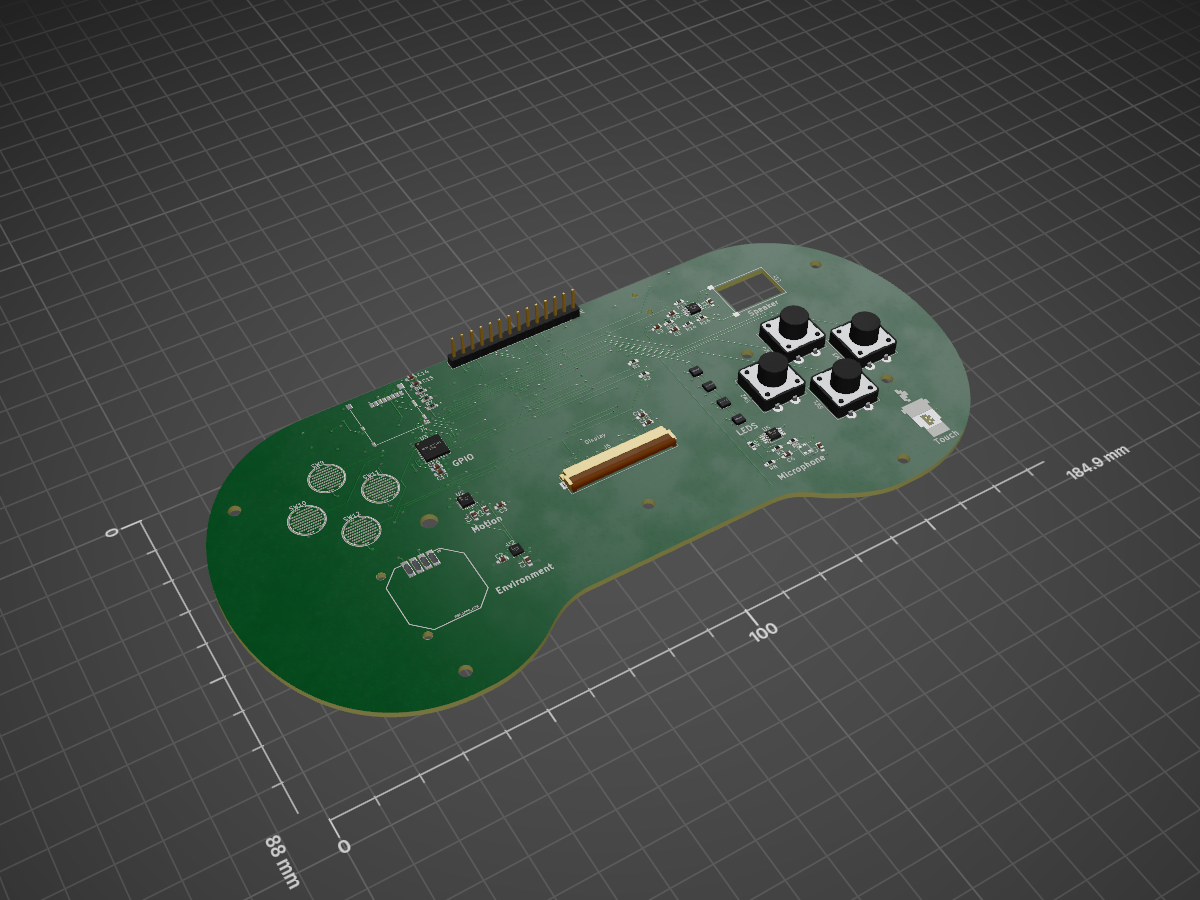
 bytebarista/controller_pcb3
Workshop controller is an open-source printed circuit board by bytebarista, from the bytebarista/controller_pcb repository on GitHub. It is a 4-layer board of 184.9 × 88 mm with 66 parts on 92 nets, routed with 982 tracks and 221 vias.
It is built around the BME280, LM358 and TPA6203A1DGN, with the MPU-9250 among its other parts. Its parts include 17 capacitors, 13 resistors, 12 switches, 7 connectors and 6 ICs.


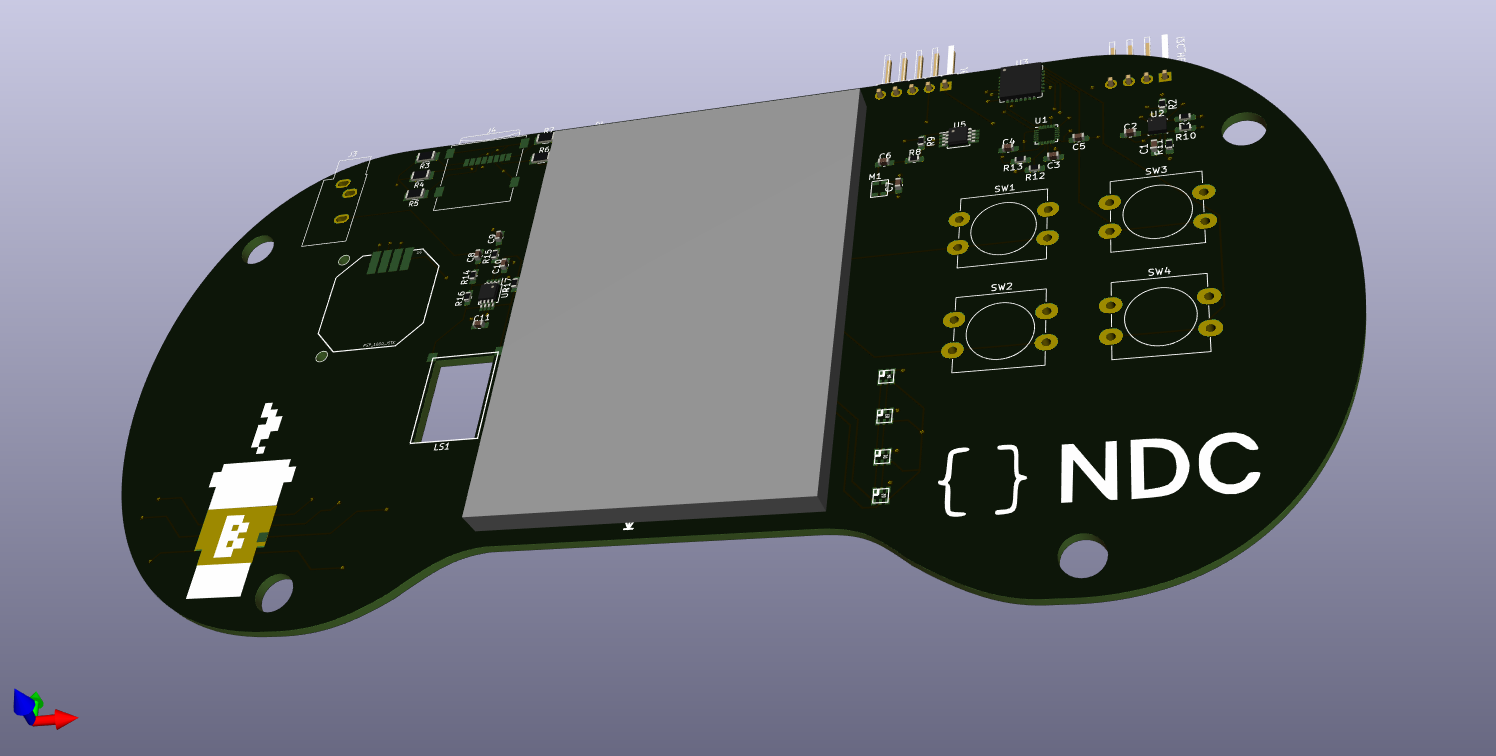
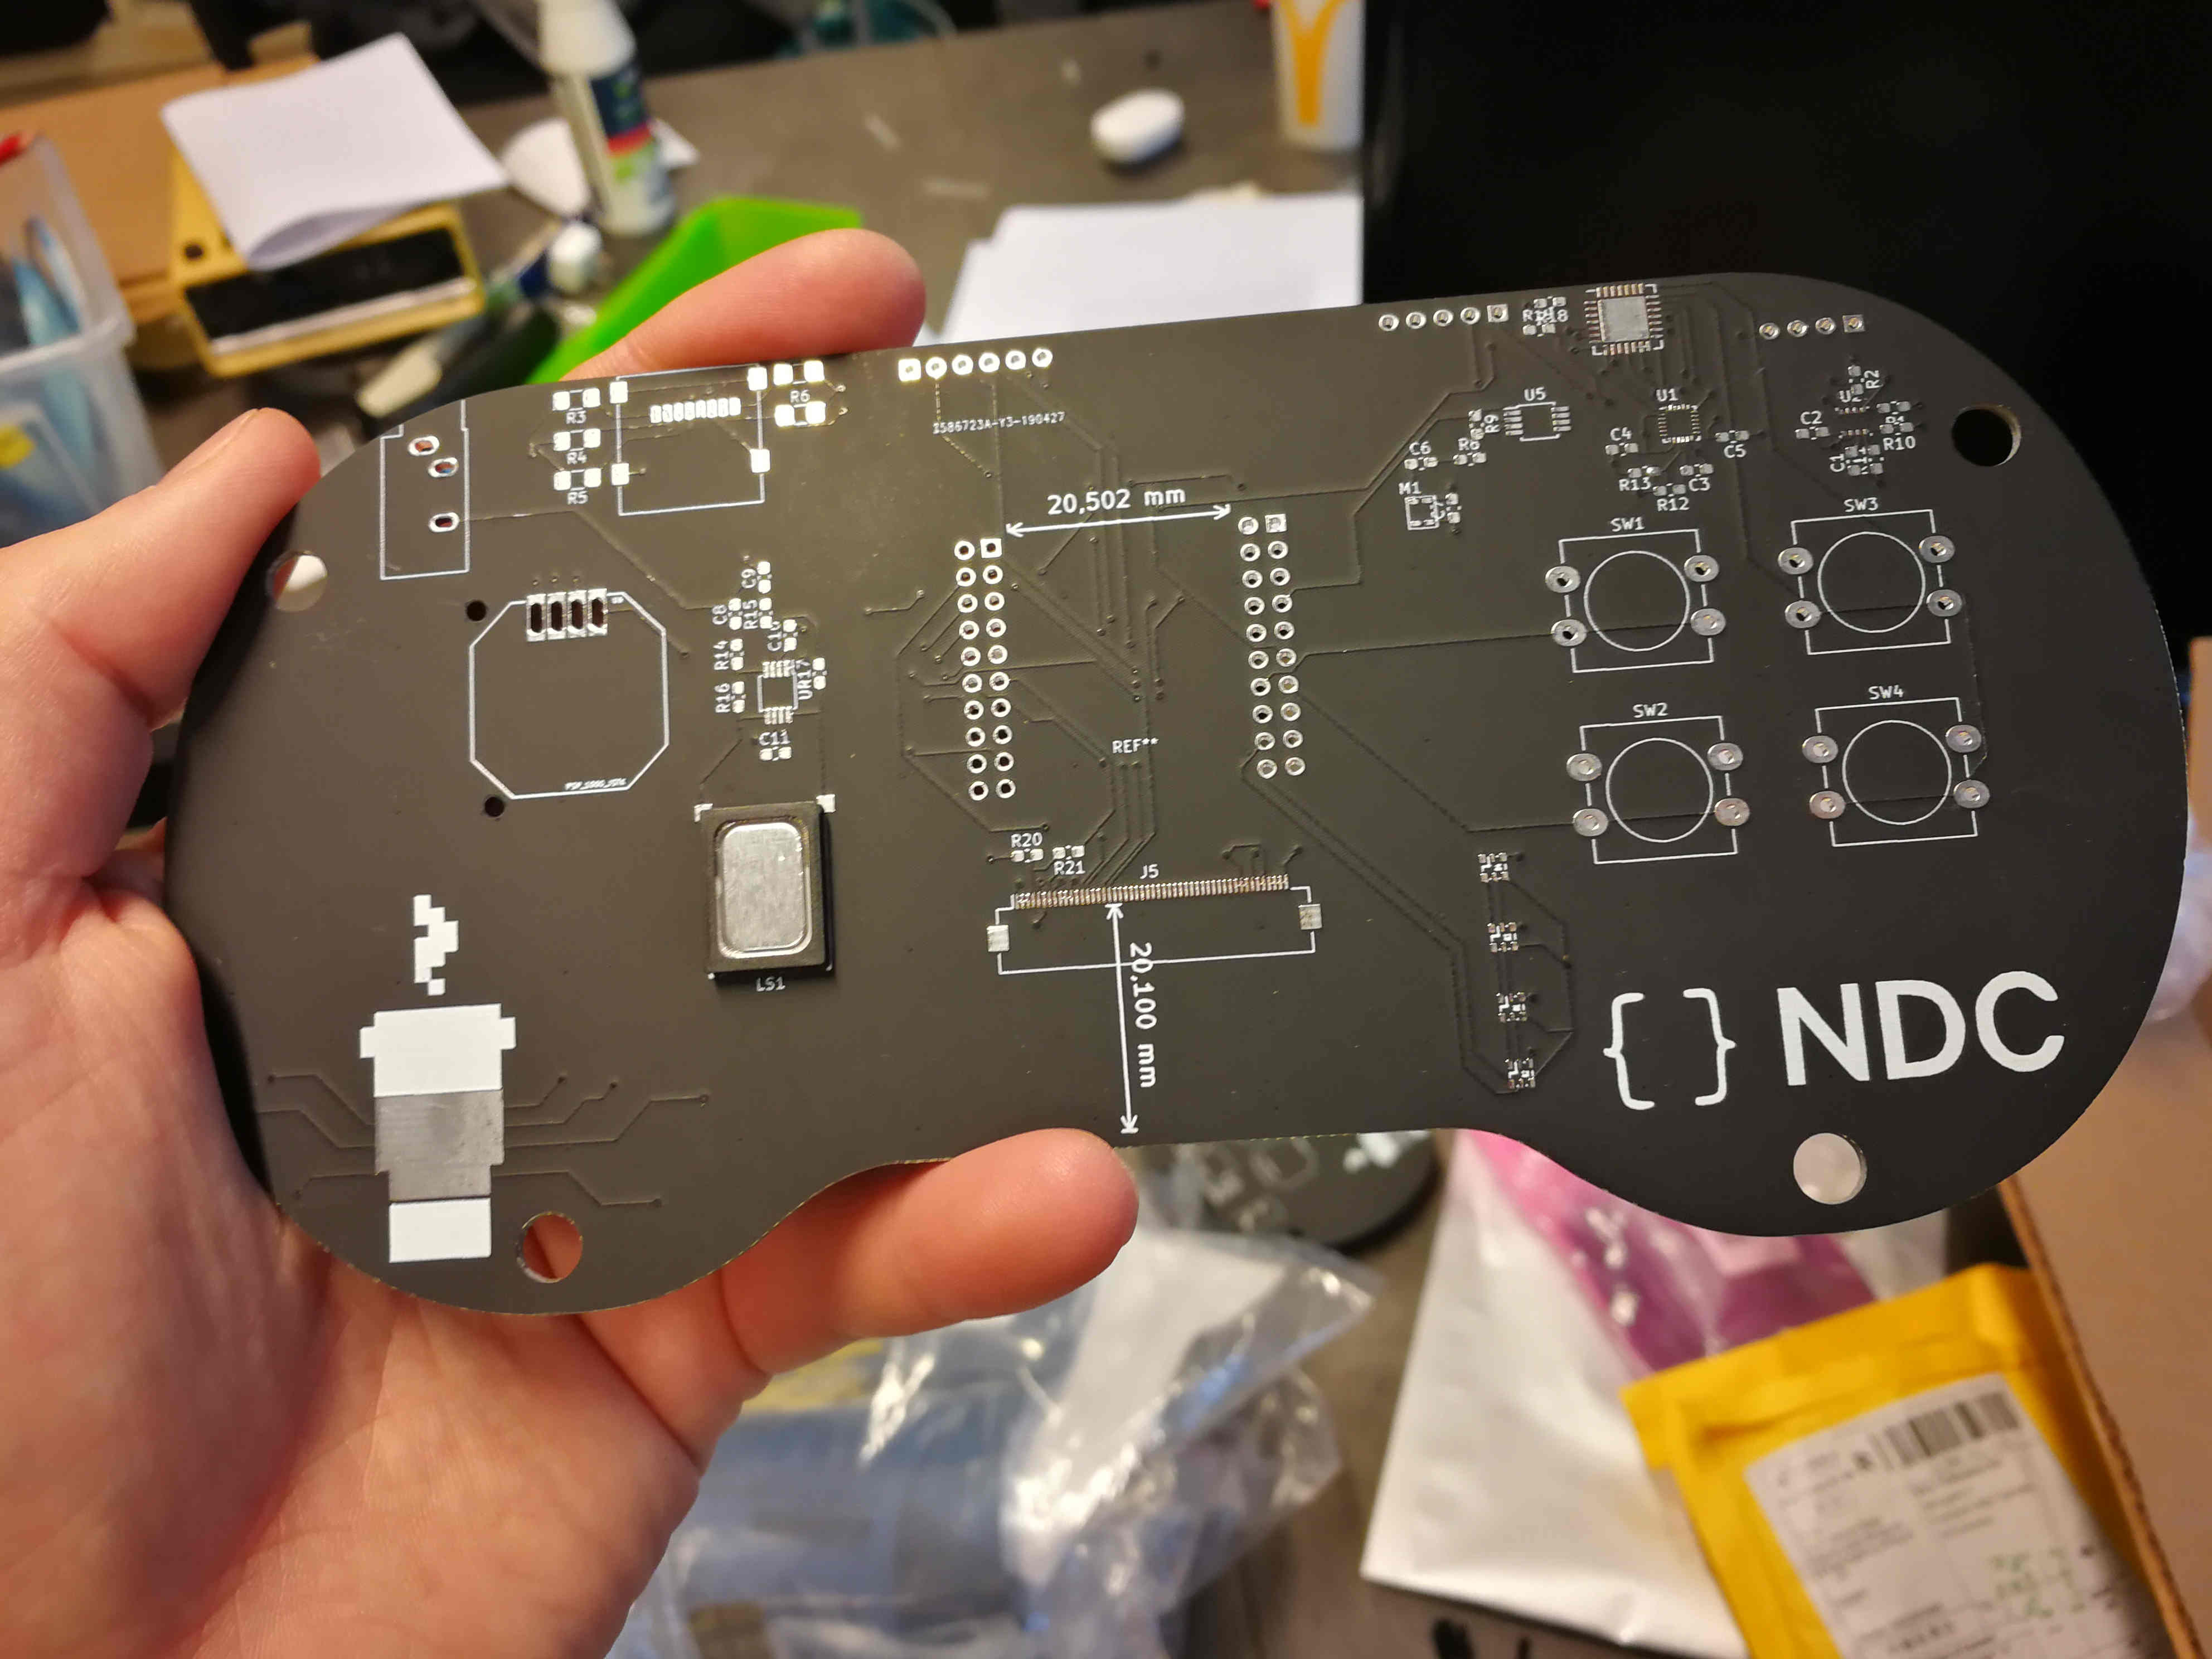
Info coming soon!
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | SW_Push | Hackheim_logo:contact_snes_button | SW5, SW6, SW7, SW8, SW9, SW10, SW11, SW12 |
| 5 | 0.1µF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C3, C5, C6, C7, C10 |
| 5 | 100nF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C1, C2, C12, C14, C16 |
| 4 | ?Ω | Resistor_SMD:R_0603_1608Metric_Pad1.05x0.95mm_HandSolder | R3, R5, R8, R9 |
| 4 | APA102 | GSG:APA102-2020 | D1, D2, D3, D4 |
| 4 | SW_Push | Button_Switch_THT:SW_PUSH-12mm_Wuerth-430476085716 | SW1, SW2, SW3, SW4 |
| 3 | 2.2µF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C13, C15, C17 |
| 3 | 50kΩ | Resistor_SMD:R_0603_1608Metric_Pad1.05x0.95mm_HandSolder | R4, R6, R7 |
| 2 | 10kΩ | Resistor_SMD:R_0603_1608Metric_Pad1.05x0.95mm_HandSolder | R14, R15 |
| 2 | 30kΩ | Resistor_SMD:R_0603_1608Metric_Pad1.05x0.95mm_HandSolder | R16, R17 |
| 2 | 4.7kΩ | Resistor_SMD:R_0603_1608Metric_Pad1.05x0.95mm_HandSolder | R1, R2 |
| 2 | 470nF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C8, C9 |
| 2 | Conn_01x06_Female | Connector_PinSocket_2.54mm:PinSocket_2x03_P2.54mm_Vertical_SMD | GPIO_EX1, SPI_HEADER1 |
| 2 | Conn_02x10_Odd_Even | Connector_PinHeader_2.54mm:PinHeader_2x10_P2.54mm_Vertical_SMD | J1, J2 |
| 1 | 10nF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C4 |
| 1 | 1µF | Capacitor_SMD:C_0603_1608Metric_Pad1.05x0.95mm_HandSolder | C11 |
| 1 | 2201778-1 | Hackheim_logo:TE_2201778-1microsd | J4 |
| 1 | AudioJack4 | Connector_Audio:Jack_3.5mm_PJ320D_Horizontal | J3 |
| 1 | BME280 | Package_LGA:Bosch_LGA-8_2.5x2.5mm_P0.65mm_ClockwisePinNumbering | U2 |
| 1 | Conn_01x04_Female | Connector_PinSocket_2.54mm:PinSocket_2x03_P2.54mm_Vertical_SMD | I2C_HEADER1 |
| 1 | Conn_01x14_MountingPin | Connector_PinHeader_2.54mm:PinHeader_1x14_P2.54mm_Vertical | J6 |
| 1 | Conn_02x25_Odd_Even | Connector_FFC-FPC:Hirose_FH12-50S-0.5SH_1x50-1MP_P0.50mm_Horizontal | J5 |
| 1 | Display | Hackheim_logo:Display | Display |
| 1 | LM358 | Package_SO:MSOP-8_3x3mm_P0.65mm | U5 |
| 1 | LOGO_TOUCH | Hackheim_logo:LOGO_SMD | J7 |
| 1 | MCP23017_ML | Package_DFN_QFN:QFN-28-1EP_6x6mm_P0.65mm_EP4.25x4.25mm | U3 |
| 1 | MPU-9250 | Package_DFN_QFN:QFN-24-1EP_3x3mm_P0.4mm_EP1.75x1.6mm | U1 |
| 1 | Microphone4 | Hackheim_logo:CMM-3125AT-42316-TR | M1 |
| 1 | PSP_1000_JSTK | Hackheim_logo:JOYSTICK-PSP1000-THROUGHHOLE | U6 |
| 1 | Speaker | Hackheim_logo:Speaker_SMD_CUI | LS1 |
| 1 | TPA6203A1 | Package_SO:MSOP-8-1EP_3x3mm_P0.65mm_EP1.68x1.88mm | U4 |
| 1 | qr_bytebarista | Hackheim_logo:qr_bytebarista | Start Learning! |
It measures 184.9 × 88 mm and has 4 copper layers, 1.6 mm thick.
66 parts, built around the BME280, LM358, TPA6203A1DGN and MPU-9250. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the bytebarista/controller_pcb repository on GitHub, at the commit this page was made from: the board is workshop_controller.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask bytebarista before reusing the design.
NBence0/JedlikBots
Welcome to the official GitHub page of JedlikBots! 🎓🤖 We are the dedicated team of software development and robotics students from the Jedlik Ányos Technical School in Győr, Hungary.

crnicholson/StratoSoar-MK2
StratoSoar is an engineering project that aims to be able to fly a glider (dropped from a high-altitude balloon), down to any selected coordinates.

dakriy/Rosario-ROV
This project is to create a working ROV with features such as live video for the WWU Rosario Beach Marine Laboratory.


ApoapsisHGV/CanSat2019-electronics
Circuit and PCB design files related to our 2019 CanSat competition


jonasbjurel/open_telemetry_HW
The OFT001v1 card has an L80-M39 GPS with a built-in patch antenna, and an optional connector for an external 50 Ohm active antenna; an MP-9250 3D axis for each of: Accelerometer, Gyroscope and Magnetometer; and a…
