32 layers121.9 × 53.3 mm
Documentary
XasWorks/Hexa-Bot
Public repository of all necessary files for the Kolleg St. Thomas Robo-Cup participating Robot.
24 parts6GPL-3.0
 XasWorks/Hexa-Bot6
Public repository of all necessary files for the Kolleg St. Thomas Robo-Cup participating Robot.
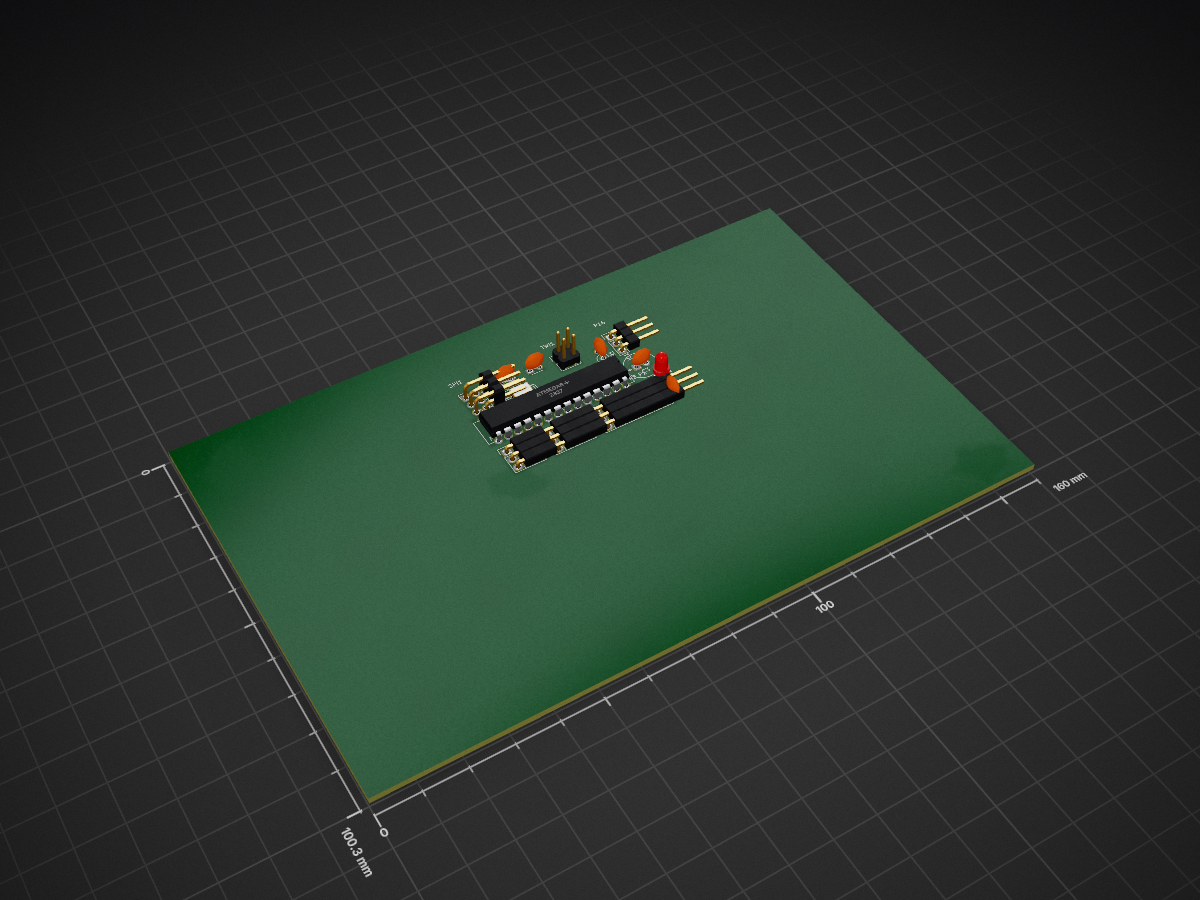
Sensor is an open-source printed circuit board by XasWorks, from the XasWorks/Hexa-Bot repository on GitHub, published under the GPL-3.0 licence. It is a 2-layer board of 160 × 100.3 mm with 25 parts on 26 nets.
Its parts include 15 connectors, 3 capacitors, 2 resistors, 1 IC and 1 diode. It belongs with the sensors and measurement and robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.
All required files, both .scad files for 3D Models aswell as the source files for the Arduino programming and the circuit plans for custom electronics (motor controller, special sensors, display etc.)
For documentation, see the "documentation" folder. Most importantly the scematics can be found under "KiCAD".
To program a robot, open Eclipse with working AVR Plugin, and "import existing project", with the folder being EclipseWS/Zephyr_Functional The used PORTS can be changed inside the Code/System/Robot.h file.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 15 | CONN_01X03 | Pin_Headers:Pin_Header_Straight_1x03 | P1, P2, P3, P4, P5, P6, P7, P9, P10, P11, P12, P13, P14, P15, P16 |
| 2 | C_Small | Capacitors_ThroughHole:C_Disc_D3_P2.5 | C1, C2 |
| 1 | ATMEGA8-P | Housings_DIP:DIP-28_W7.62mm | IC1 |
| 1 | CONN_02X02 | Pin_Headers:Pin_Header_Straight_2x02 | TWI1 |
| 1 | CONN_02X03 | Pin_Headers:Pin_Header_Angled_2x03 | SPI1 |
| 1 | CP | Discret:C1V8 | C3 |
| 1 | Crystal | Crystals:Crystal_HC52-U_Vertical | Y1 |
| 1 | Led_Small | LEDs:LED-3MM | D1 |
| 1 | R | Discret:R1 | R1 |
| 1 | R_Small | Discret:R1 | R2 |
XasWorks/Hexa-Bot
Public repository of all necessary files for the Kolleg St. Thomas Robo-Cup participating Robot.

google/mozc-devices
Circuit diagrams and firmware source code for Gboard DIY keyboards

davidphilipbarr/Sweep
Sweep - a small promicro based keyboard inspired by the Ferris.


hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

xyphro/UsbGpib
Versatile, cheap and portable USB to GPIB converter (USBTMC class based)


jes/scamp-cpu
A homebrew 16-bit CPU with a homebrew Unix-like-ish operating system.

It measures 160 × 100.3 mm and has 2 copper layers, 1.6 mm thick.
25 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the XasWorks/Hexa-Bot repository on GitHub, at the commit this page was made from: the board is Documentary/KiCad/Sensor/Sensor.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).