2 layers57 × 55.2 mm
LogicAnalyzer
gusmanb/logicanalyzer
24 channel, 100Msps logic analyzer hardware and software
10 parts5.1kGPL-3.0

 VSSUT-Robotics-Society/PID-Seesaw
A simple project to understand the basics of a PID Controller.
PID Seesaw is an open-source printed circuit board by VSSUT-Robotics-Society, from the VSSUT-Robotics-Society/PID-Seesaw repository on GitHub. It is a 2-layer board of 42 × 59.5 mm with 10 parts on 31 nets, routed with 27 tracks and 0 vias.
It belongs with the AVR (ATmega, ATtiny) boards of this library.
The PID Seesaw project demonstrates the application of a Proportional-Integral-Derivative (PID) controller to balance a seesaw (inverted pendulum) system. The objective is to maintain the ball's position by dynamically adjusting the control input based on real-time feedback from the system.
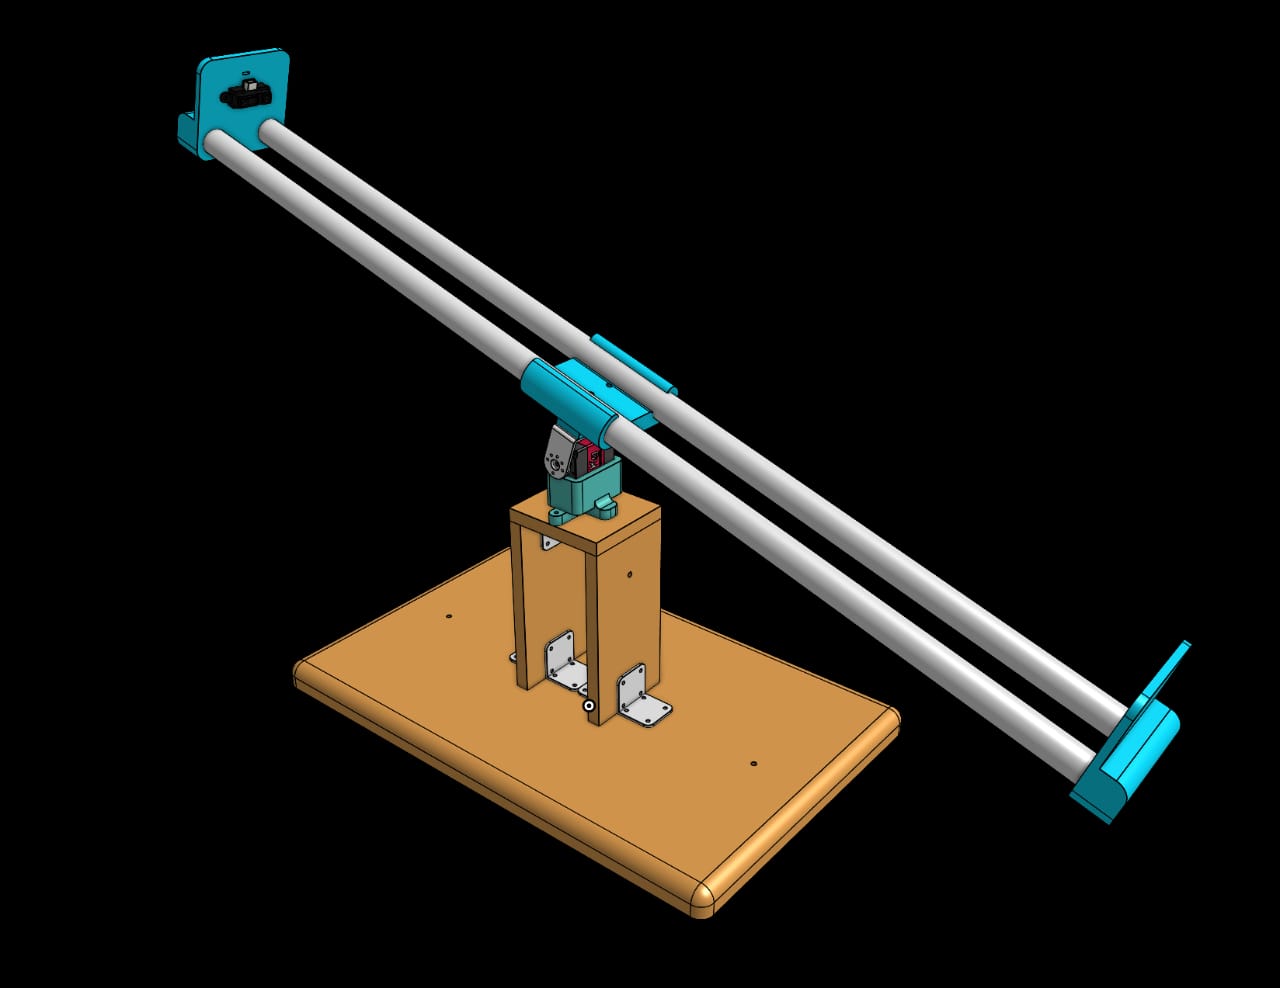
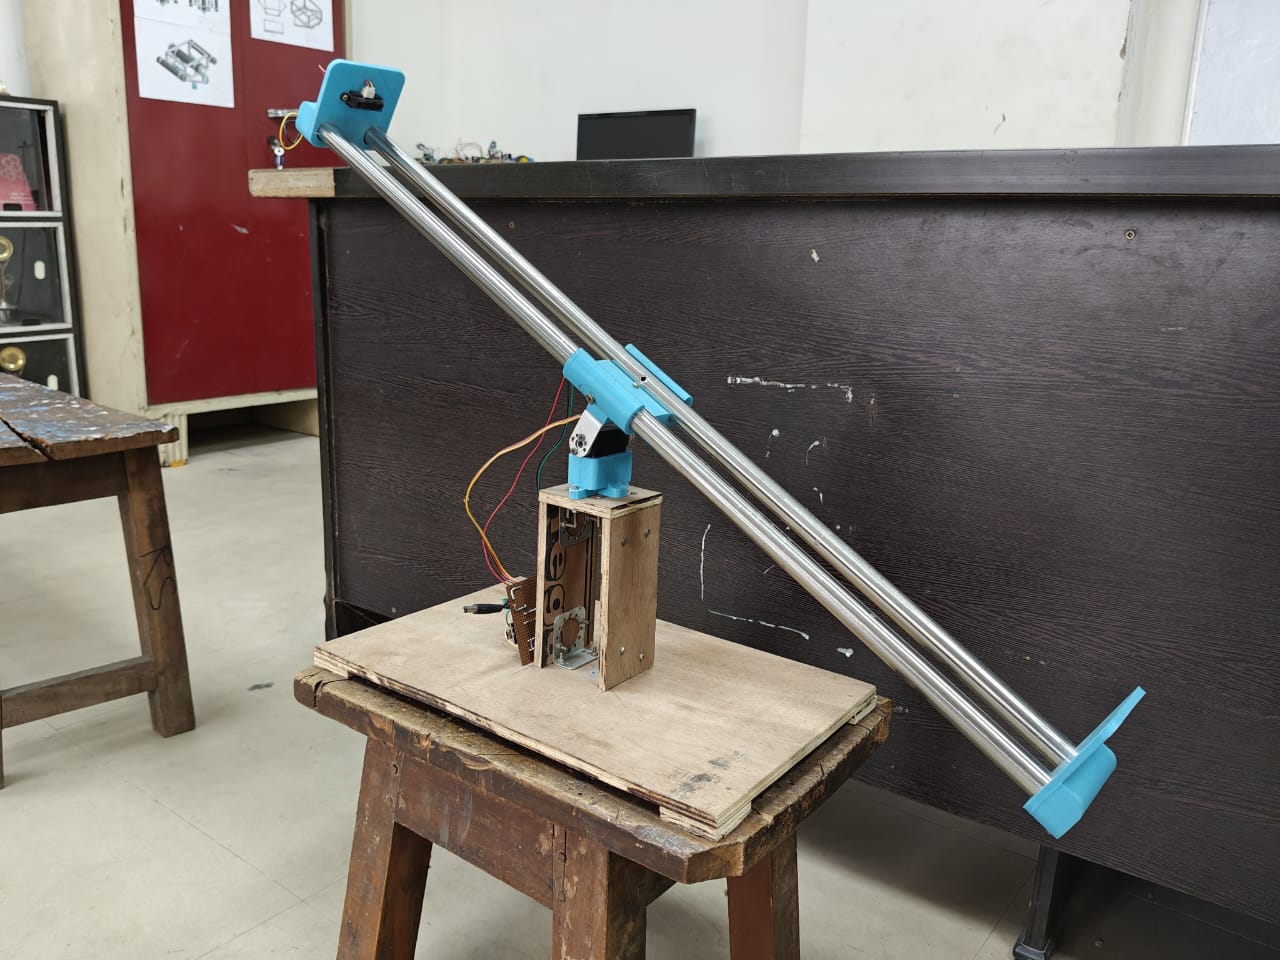
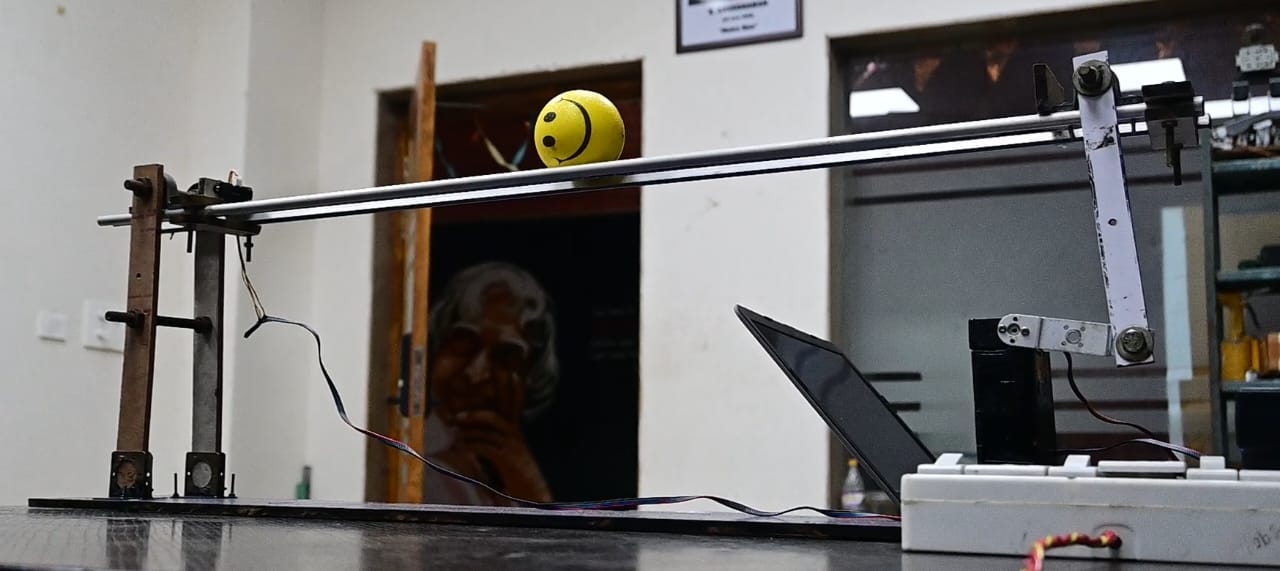
The PID controller output is given by:
u(t) = Kp * e(t) + Ki * ∫e(t)dt + Kd * de(t)/dtWhere:
e(t): Error signal (desired position - measured position)Kp: Proportional gain (reacts to current error)Ki: Integral gain (reacts to accumulated error)Kd: Derivative gain (reacts to rate of error change)Tuning these gains is essential for achieving a balance between responsiveness and stability.
Kp, Ki, and Kd to minimize overshoot, settling time, and steady-state error.PID Seesaw - Report - A detailed report on the PID Seesaw project, including mathematical modeling, implementation details, and experimental results.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 1 | 12V_IN | TerminalBlock:TerminalBlock_bornier-2_P5.08mm | J8 |
| 1 | Arduino_Nano_v3.x | Module:Arduino_Nano | A1 |
| 1 | LOGO | RS Branding:RS Logo (10mm) | G*** |
| 1 | Servo | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J7 |
| 1 | Sharp0 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J5 |
| 1 | Sharp1 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6 |
| 1 | VIN+ | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J1 |
| 1 | VIN- | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J2 |
| 1 | VOUT+ | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J4 |
| 1 | VOUT- | Connector_PinHeader_2.54mm:PinHeader_1x01_P2.54mm_Vertical | J3 |
gusmanb/logicanalyzer
24 channel, 100Msps logic analyzer hardware and software

byrantech/laptop
anyon_e, a highly integrated, high end, open source laptop. Attempt the impossible.

joeycastillo/Sensor-Watch
A board replacement for the classic Casio F-91W wristwatch


OLIMEX/OLINUXINO
OLINUXINO is Open Source / Open Hardware, low cost from EUR 24 Linux Industrial grade Single Board Computer capable to operate -25+85C

rusefi/rusefi
rusefi - GPL internal combustion engine control unit

VoronDesign/Voron-Hardware
Cool Hardware designed by the Voron Design group

hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI
It measures 42 × 59.5 mm and has 2 copper layers, 1.6 mm thick.
10 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the VSSUT-Robotics-Society/PID-Seesaw repository on GitHub, at the commit this page was made from: the board is PCB/PID Seesaw.kicad_pcb and its schematic PCB/PID Seesaw.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask VSSUT-Robotics-Society before reusing the design.