2 layers53.1 × 93.3 mm

 Tomnwol/drone-robotech1
Git du projet drone de Robotech 2025 / 2026
Manette drone Robotech is an open-source printed circuit board by Tomnwol, from the Tomnwol/drone-robotech repository on GitHub. It is a 2-layer board of 164.2 × 95 mm with 22 parts on 32 nets, routed with 110 tracks and 66 vias.
Its parts include 2 resistors, 2 diodes and 2 connectors. It belongs with the robots and motor control boards and the AVR (ATmega, ATtiny) boards of this library.
ESP32-based 5" drone built by the Robotech team. Attitude is estimated from a 9-axis IMU, then converted into motor commands through a PID loop. Control and telemetry go over the ESP32's built-in Wi-Fi (UDP).
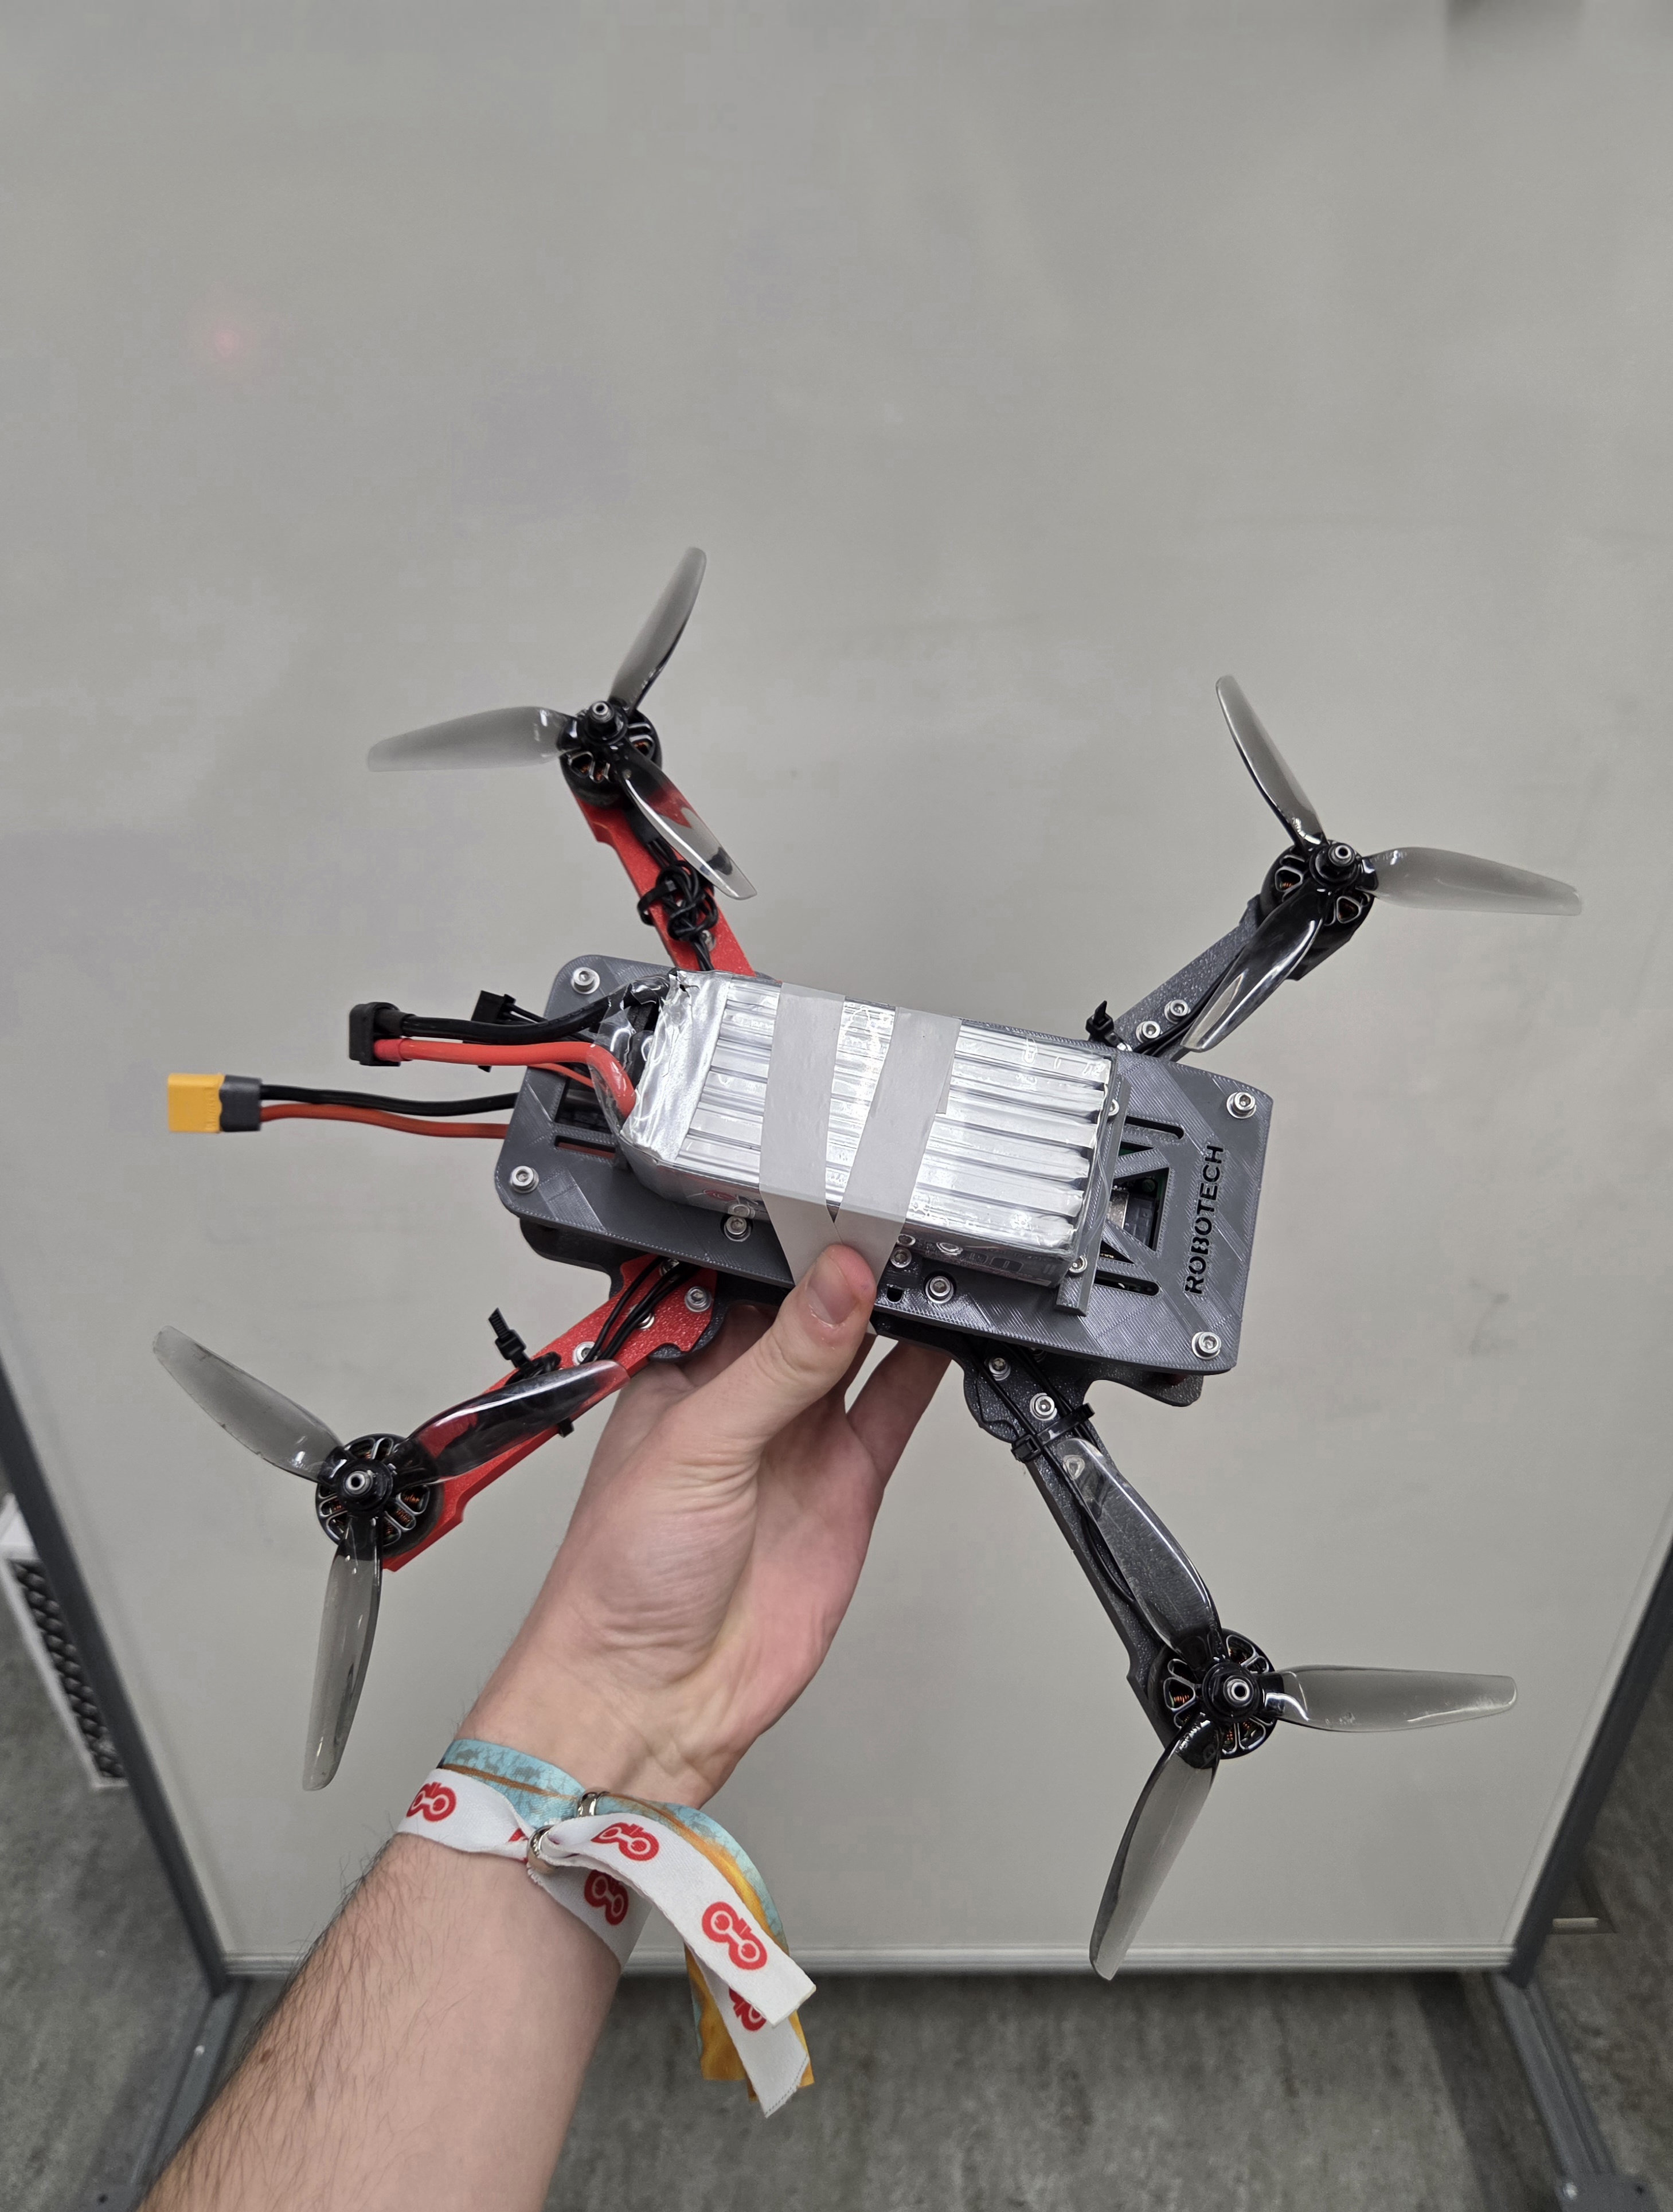
A 9-axis IMU (accelerometer, gyroscope, magnetometer) feeds a Madgwick AHRS filter to estimate attitude. Angular commands from that estimate drive the motors via DShot.
| Part | Model |
|---|---|
| MCU | ESP32 DevKit |
| Accel / Gyro | MPU-9265 |
| Magnetometer | GY-271 (not-used) |
| Motors | XING-E Pro 2207 1800KV 2–6S (iFlight) |
| ESC | Hobbywing XRotor Micro 65A G2 4-in-1 AM32 |
| Battery | LiPo GNB 6S 2200 mAh 120C — XT60 (Gaoneng) |
| Link | ESP32 Wi-Fi (UDP) |
| Frame | Designed in Fusion 360, 3D-printed |
| PCB | Designed in KiCad 9 |
After library issues with DShot under ESP-IDF / PlatformIO, the flight code moved to Arduino IDE to use a more recent DSHOTRMT build. Firmware lives under main/.
A Qt 6 ground station in Emitter/QT_Controller/ connects over Wi-Fi and sends stick / config commands by UDP.
From a clean Linux machine (apt / dnf / yum):
git clone <repo-url>
cd drone-robotech/Emitter/QT_Controller

./install-deps.sh   # cmake, g++, Qt6, QML modules, libevdev, …

cmake -S . -B build -DCMAKE_BUILD_TYPE=Release
cmake --build build -j"$(nproc)"
./build/drone_controller
Use CMake + Qt6 only — do not use qmake / Qt5 (qmake on Ubuntu often points to Qt5).
PID / motor offsets are saved under ~/.config/drone_controller/initialValues.ini.
An Xbox-style gamepad named Generic X-Box pad is optional; without it the UI still starts (sticks can be moved with the on-screen sliders).
Simulation/simulation.py visualizes attitude estimation and the four motor responses so PID gains can be tuned offline.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 8 | MountingHole | MountingHole:MountingHole_3.2mm_M3_Pad | H1, H2, H3, H4, H5, H6, H7, H8 |
| 7 | Conn_01x03_Pin | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | GP_POT1, JL1, JL2, JR1, JR2, SW1, SW2 |
| 2 | LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1, D2 |
| 2 | R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R2 |
| 1 | Arduino_Nano_v3.x | Module:Arduino_Nano | A1 |
| 1 | Conn_01x02_Pin | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J2 |
| 1 | NRF_RADIO | Connector_PinHeader_2.54mm:PinHeader_2x04_P2.54mm_Vertical | J1 |

VoronDesign/Voron-Hardware
Cool Hardware designed by the Voron Design group

hoglet67/RGBtoHDMI
Bare-metal Raspberry Pi project that provides pixel-perfect sampling of Retro Computer RGB/YUV video and conversion to HDMI

hackclub/OnBoard
💡 Join 1,000 teenagers and make your first PCB with a $100 grant!

abhishek-kakkar/BeagleLogic
A Software Suite that implements a logic analyzer with the PRU on the BeagleBone / BeagleBone Black.

Chrismettal/flipper-zero-backpacks
Backpack-style addon boards for the Flipper Zero!


CRImier/MyKiCad
My KiCad boards. Can't be bothered uploading individually anymore, so here you go.
It measures 164.2 × 95 mm and has 2 copper layers, 1.6 mm thick.
22 parts. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the Tomnwol/drone-robotech repository on GitHub, at the commit this page was made from: the board is Hardware/Manette/Manette drone Robotech.kicad_pcb and its schematic Hardware/FlightController/DronePCB.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask Tomnwol before reusing the design.