
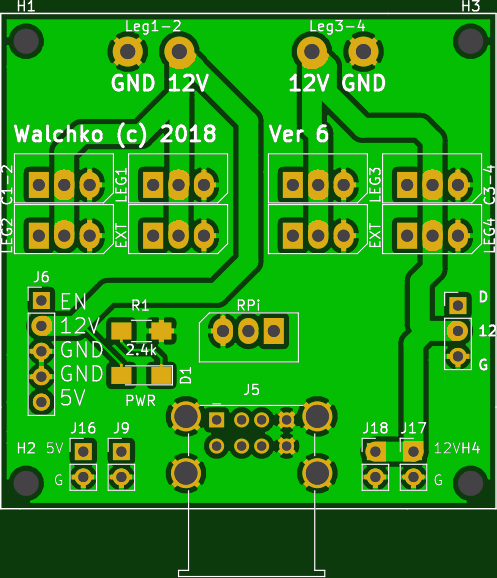
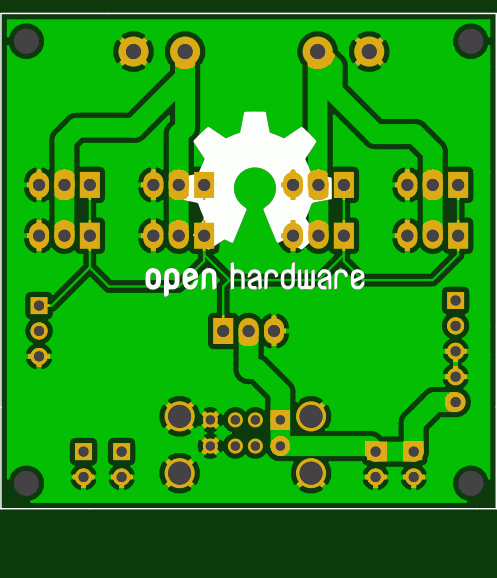
2 layers49.5 × 49.5 mm
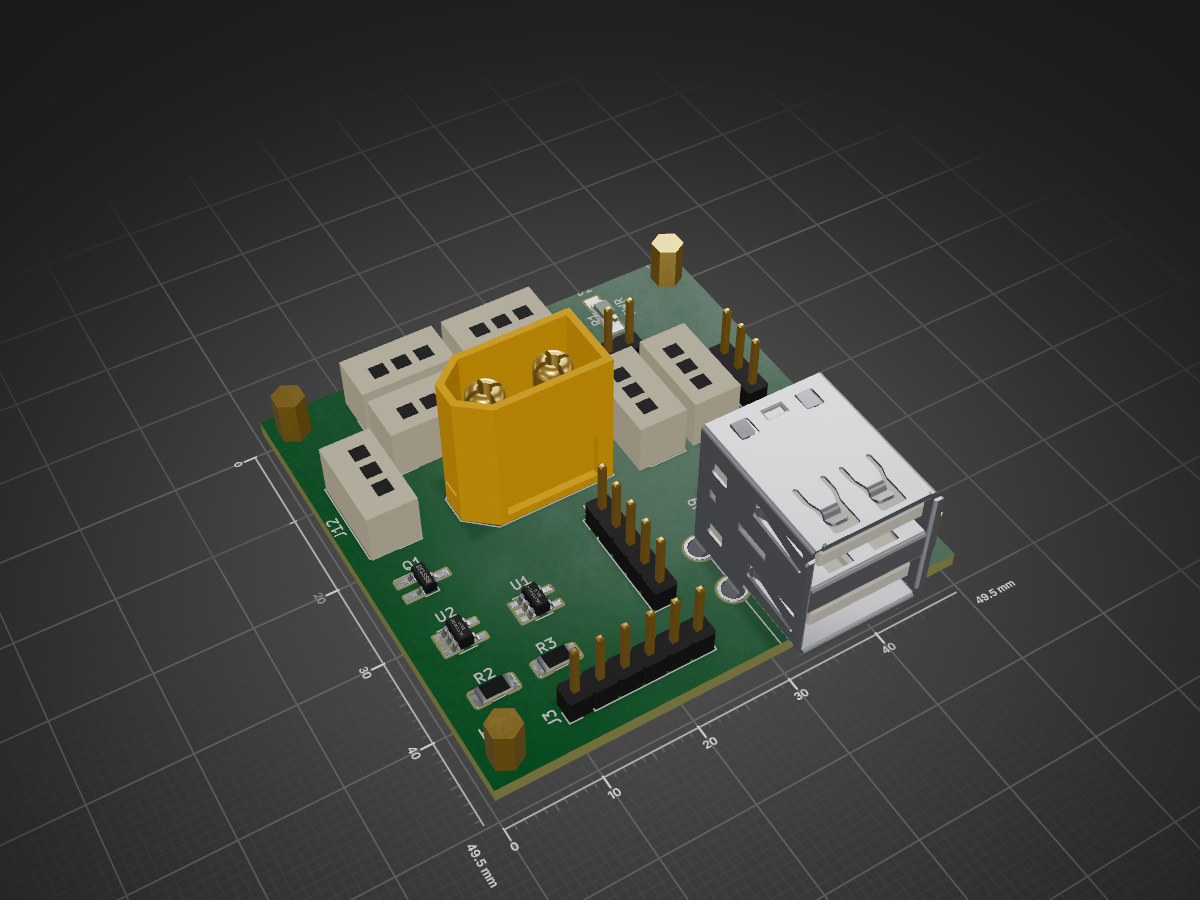
:robot: Simple hexapod robot using AX-12A servos
Robot is an open-source printed circuit board by MultipedRobotics, from the MultipedRobotics/hexapod-ax-12a repository on GitHub, published under the MIT licence. It is a 2-layer board of 49.5 × 49.5 mm with 26 parts on 10 nets.
It is built around the 74LVC1G125, 74LVC1G126Z and BSS138. Its parts include 14 connectors, 3 resistors, 2 ICs, 1 diode and 1 transistor. It belongs with the robots and motor control boards of this library.


| Qty | Value | Footprint | References |
|---|---|---|---|
| 4 | MountingHole | MountingHole:MountingHole_2.2mm_M2_DIN965 | H1, H2, H3, H4 |
| 2 | R_US | Resistor_SMD:R_1206_3216Metric_Pad1.42x1.75mm_HandSolder | R2, R3 |
| 1 | 12V | Pin_Headers:Pin_Header_Straight_1x02_Pitch2.54mm | J17 |
| 1 | 2.4k | Resistors_SMD:R_1206_HandSoldering | R1 |
| 1 | 5V | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J9 |
| 1 | 5V Pwr | Pin_Headers:Pin_Header_Straight_1x05_Pitch2.54mm | J6 |
| 1 | 74LVC1G125 | Package_TO_SOT_SMD:SOT-23-5_HandSoldering | U2 |
| 1 | 74LVC1G126 | Package_TO_SOT_SMD:SOT-23-5_HandSoldering | U1 |
| 1 | BSS138 | Package_TO_SOT_SMD:SOT-23_Handsoldering | Q1 |
| 1 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J3 |
| 1 | EXTRA | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J12 |
| 1 | EXTRA | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J15 |
| 1 | LEG1 | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J1 |
| 1 | LEG2 | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J8 |
| 1 | LEG3 | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J10 |
| 1 | LEG4 | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J11 |
| 1 | LEG5 | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J2 |
| 1 | LEG6 | Connector_Molex:Molex_SPOX_5267-03A_1x03_P2.50mm_Vertical | J14 |
| 1 | Logo_Open_Hardware_Large | Symbol:OSHW-Logo2_24.3x20mm_SilkScreen | LOGO1 |
| 1 | PWR | LEDs:LED_1206_HandSoldering | D1 |
| 1 | USB_A_2_PORT | Connector_USB:USB_A_Wuerth_61400826021_Horizontal_Stacked | J5 |
| 1 | xt60 | Connector_AMASS:AMASS_XT60-M_1x02_P7.20mm_Vertical | J19 |


kim-xps12/m5stack_board_unitree_brushless_digital_servo
Unitree Servo UART Board for M5Stack: auto-direction 4 Mbps half-duplex TTL bus for Unitree J288 / S288 brushless digital servos (KiCad 9, JLCPCB PCBA)


abhishek-kakkar/beaglelogic-standalone
BeagleLogic implemented as a turnkey and standalone logic analyzer


It measures 49.5 × 49.5 mm and has 2 copper layers, 1.6 mm thick.
26 parts, built around the 74LVC1G125, 74LVC1G126Z and BSS138. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the MultipedRobotics/hexapod-ax-12a repository on GitHub, at the commit this page was made from: the board is electrical/power-v6/robot.kicad_pcb. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the MIT licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).
