6 layers37.9 × 37.9 mm
OpenFC
OpenDrone-hw/OpenFC-Lite
Open-source Betaflight flight controller. RP2354B, 30.5x30.5 mm, 6-layer, 3-8S, CERN-OHL-S-2.0.
164 parts85CERN-OHL-S-2.0

 HazzerTheGreat/SPAR
A flight controller for fixed wing UAVs based on the STM32H7 and designed to run betaflight or INAV
FlightControllerV2 is an open-source printed circuit board by HazzerTheGreat, from the HazzerTheGreat/SPAR repository on GitHub. It is a 6-layer board of 48 × 58 mm with 105 parts on 145 nets, routed with 893 tracks and 278 vias.
It is built around the AT7456E, LMR33630ARNXR and BMP280, with the 8122S-25.000NQ33FTL, AP2112K-3.3 and SM03B-SRSS-TB(LF)(SN) among its other parts. Its parts include 52 capacitors, 16 resistors, 15 connectors, 13 ICs and 2 diodes. It belongs with the robots and motor control boards and the STM32 boards of this library.


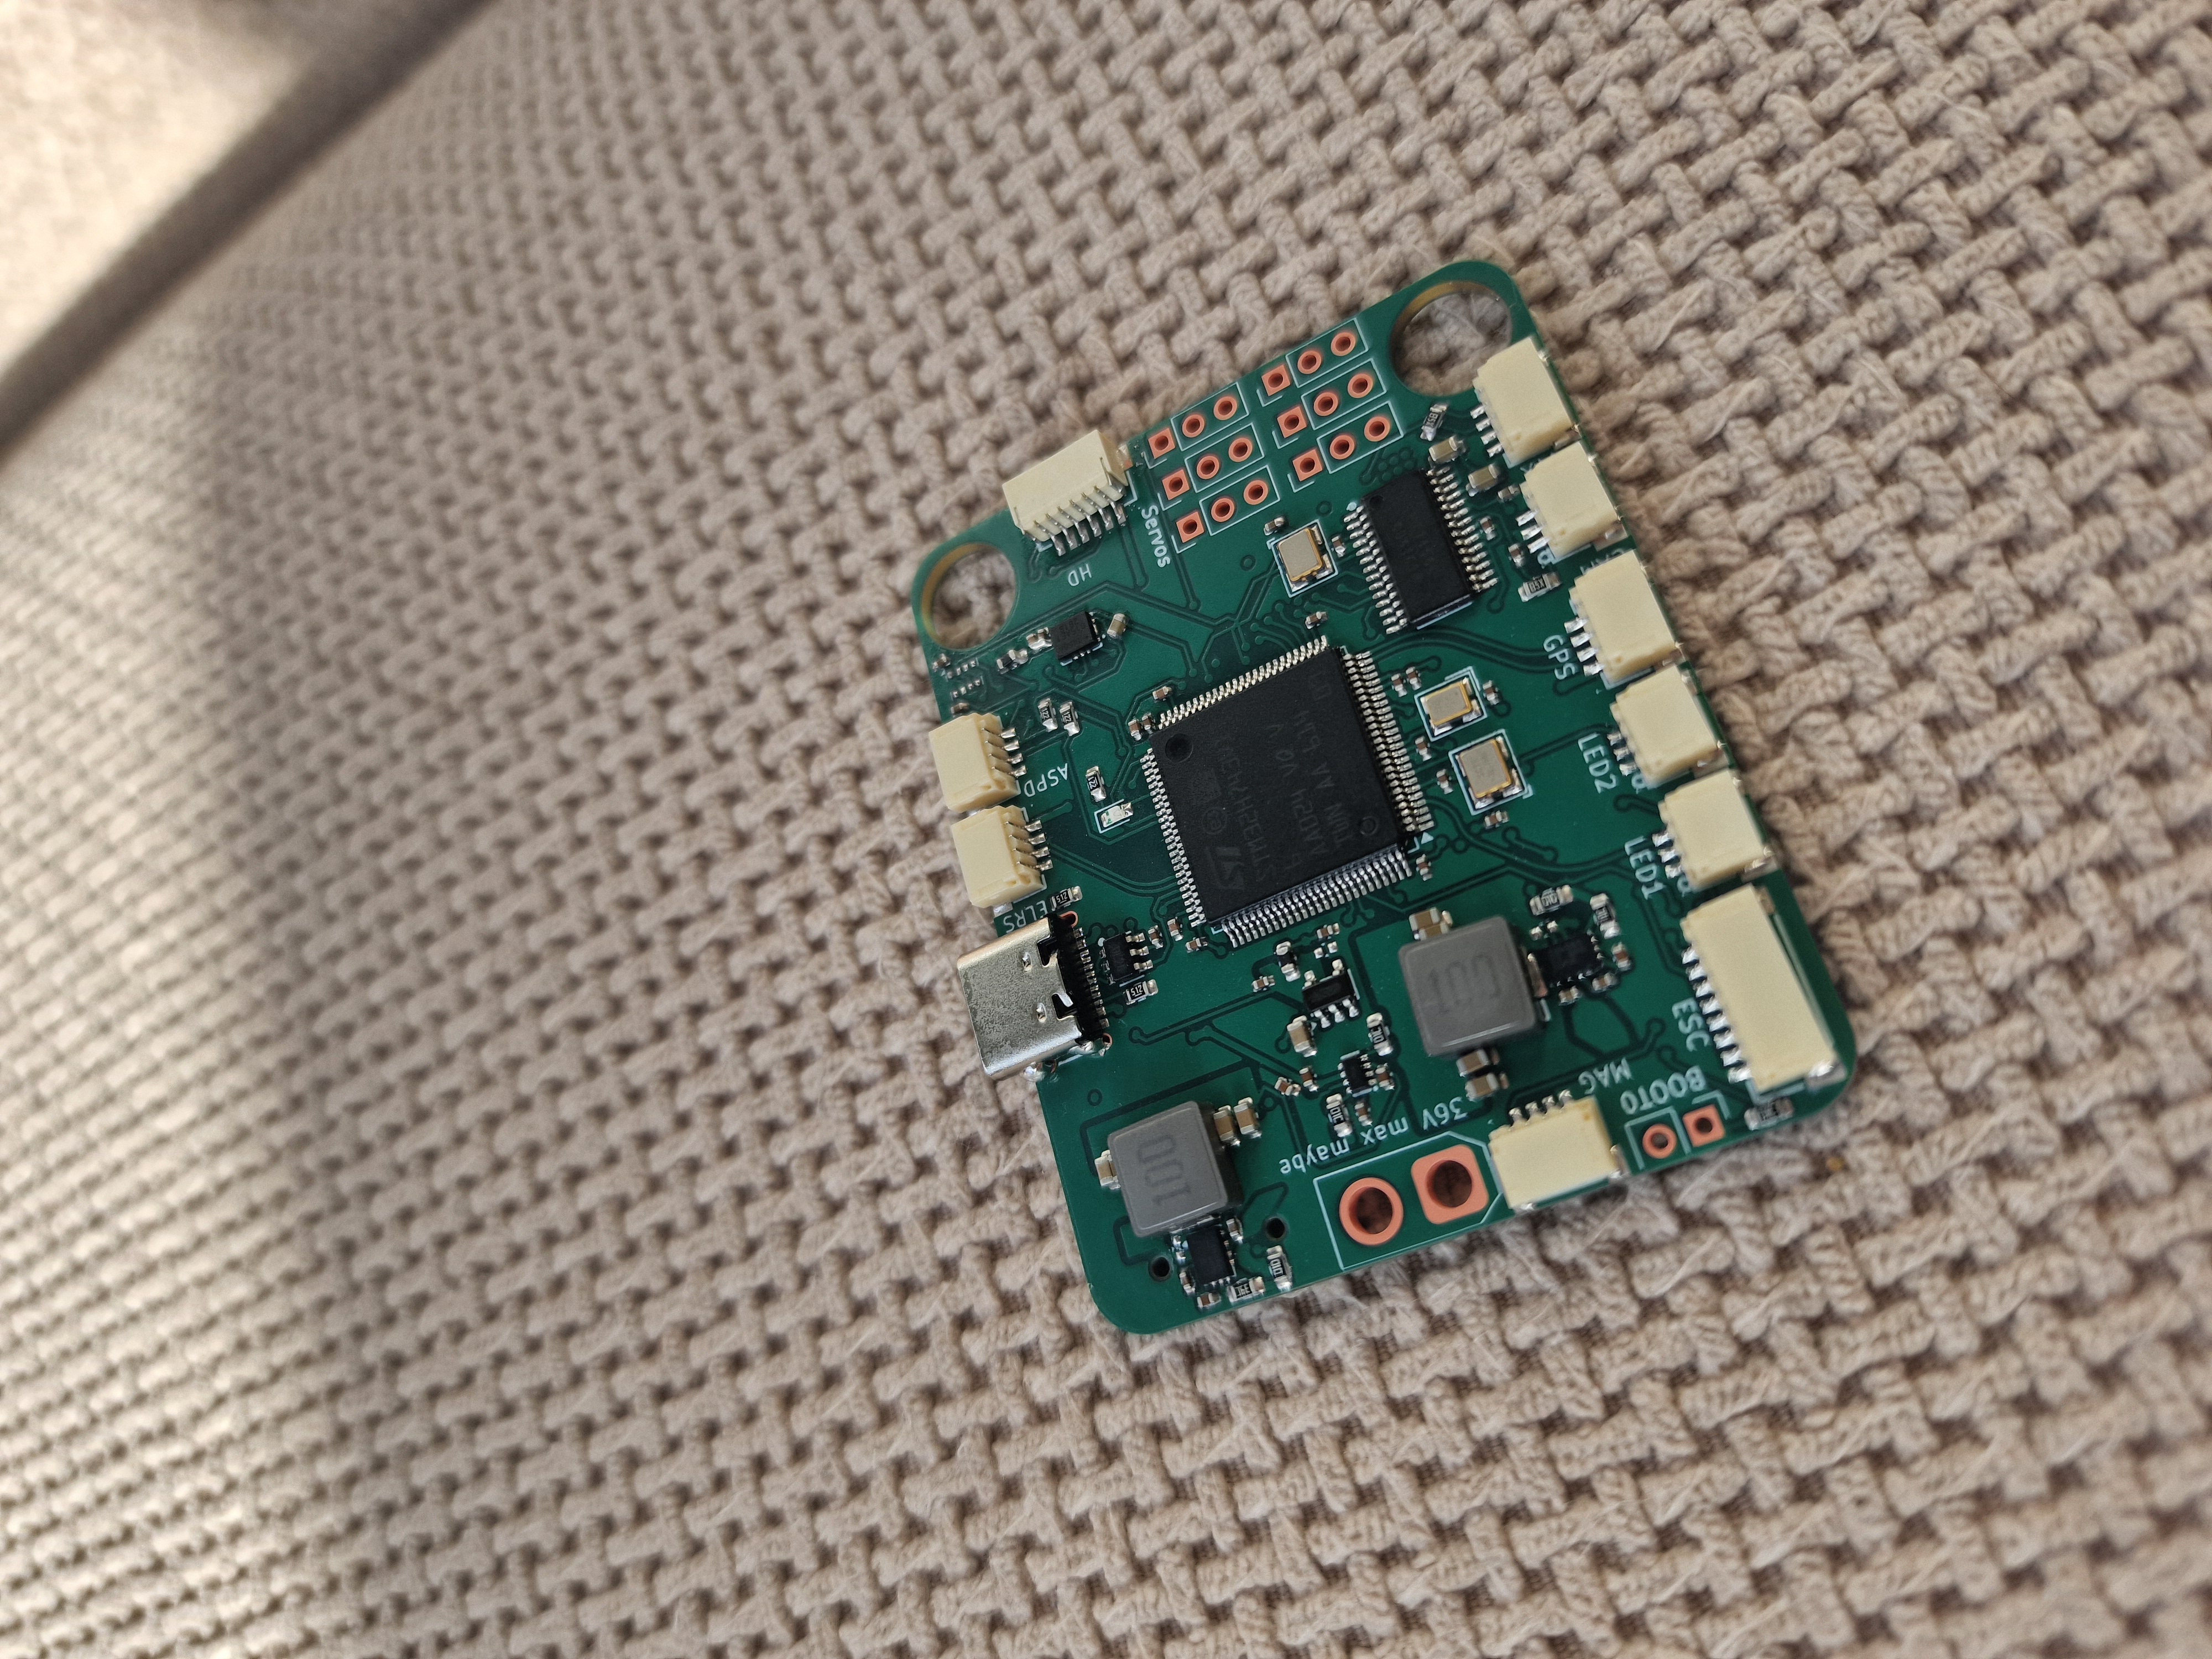
This is a flight controller primarily designed for fixed wing aircraft (or quadcopters etc) that is designed to run either BetaFlight, INAV or ArduPilot firmware. It handles flight stabilization, OSD, control of servos, waypoints, data logging and anything else any other flight controller can do. This flight controller has an STM32H743 which is an extremely capable MCU with a blazing fast speed of up to 480MHz. Most likely overkill for the majority of applications but it can accomodate for the most demanding projects. I made it as I was interested in the design of such systems and also enjoy building aircraft and could find a highly capable flight controller useful plus the benefit that I have built it myself.
Specs:
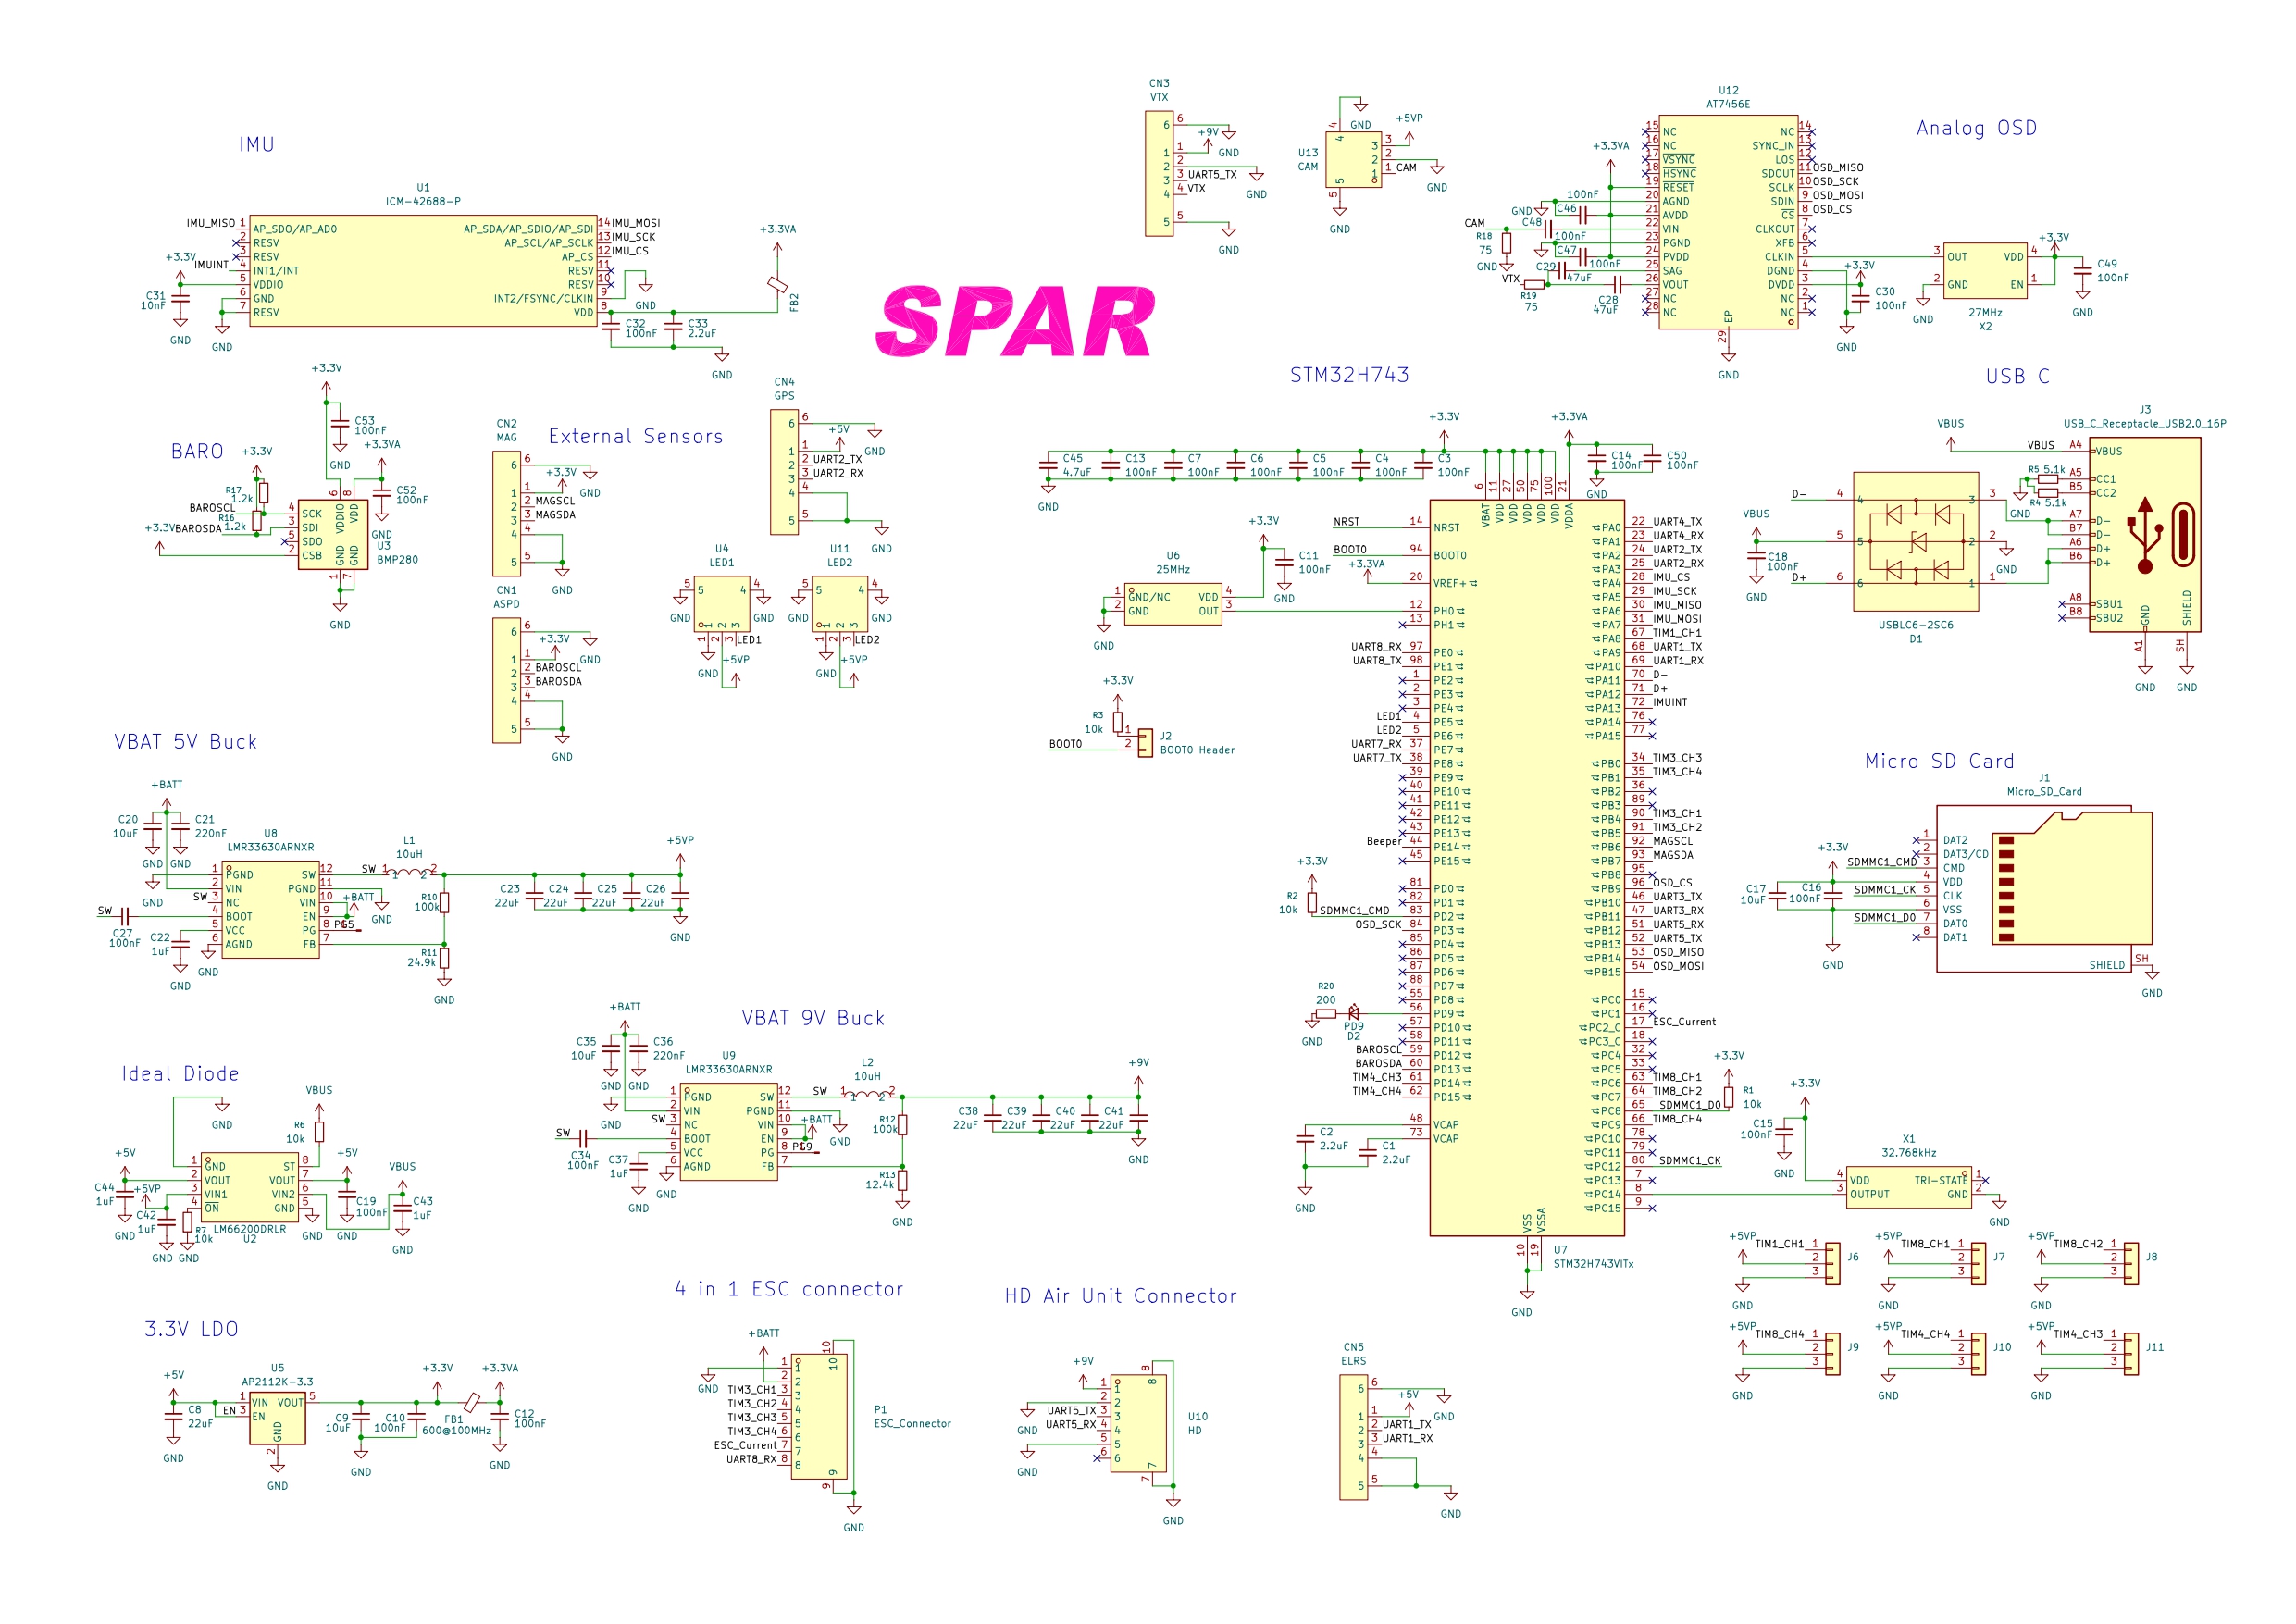
Peripherals:
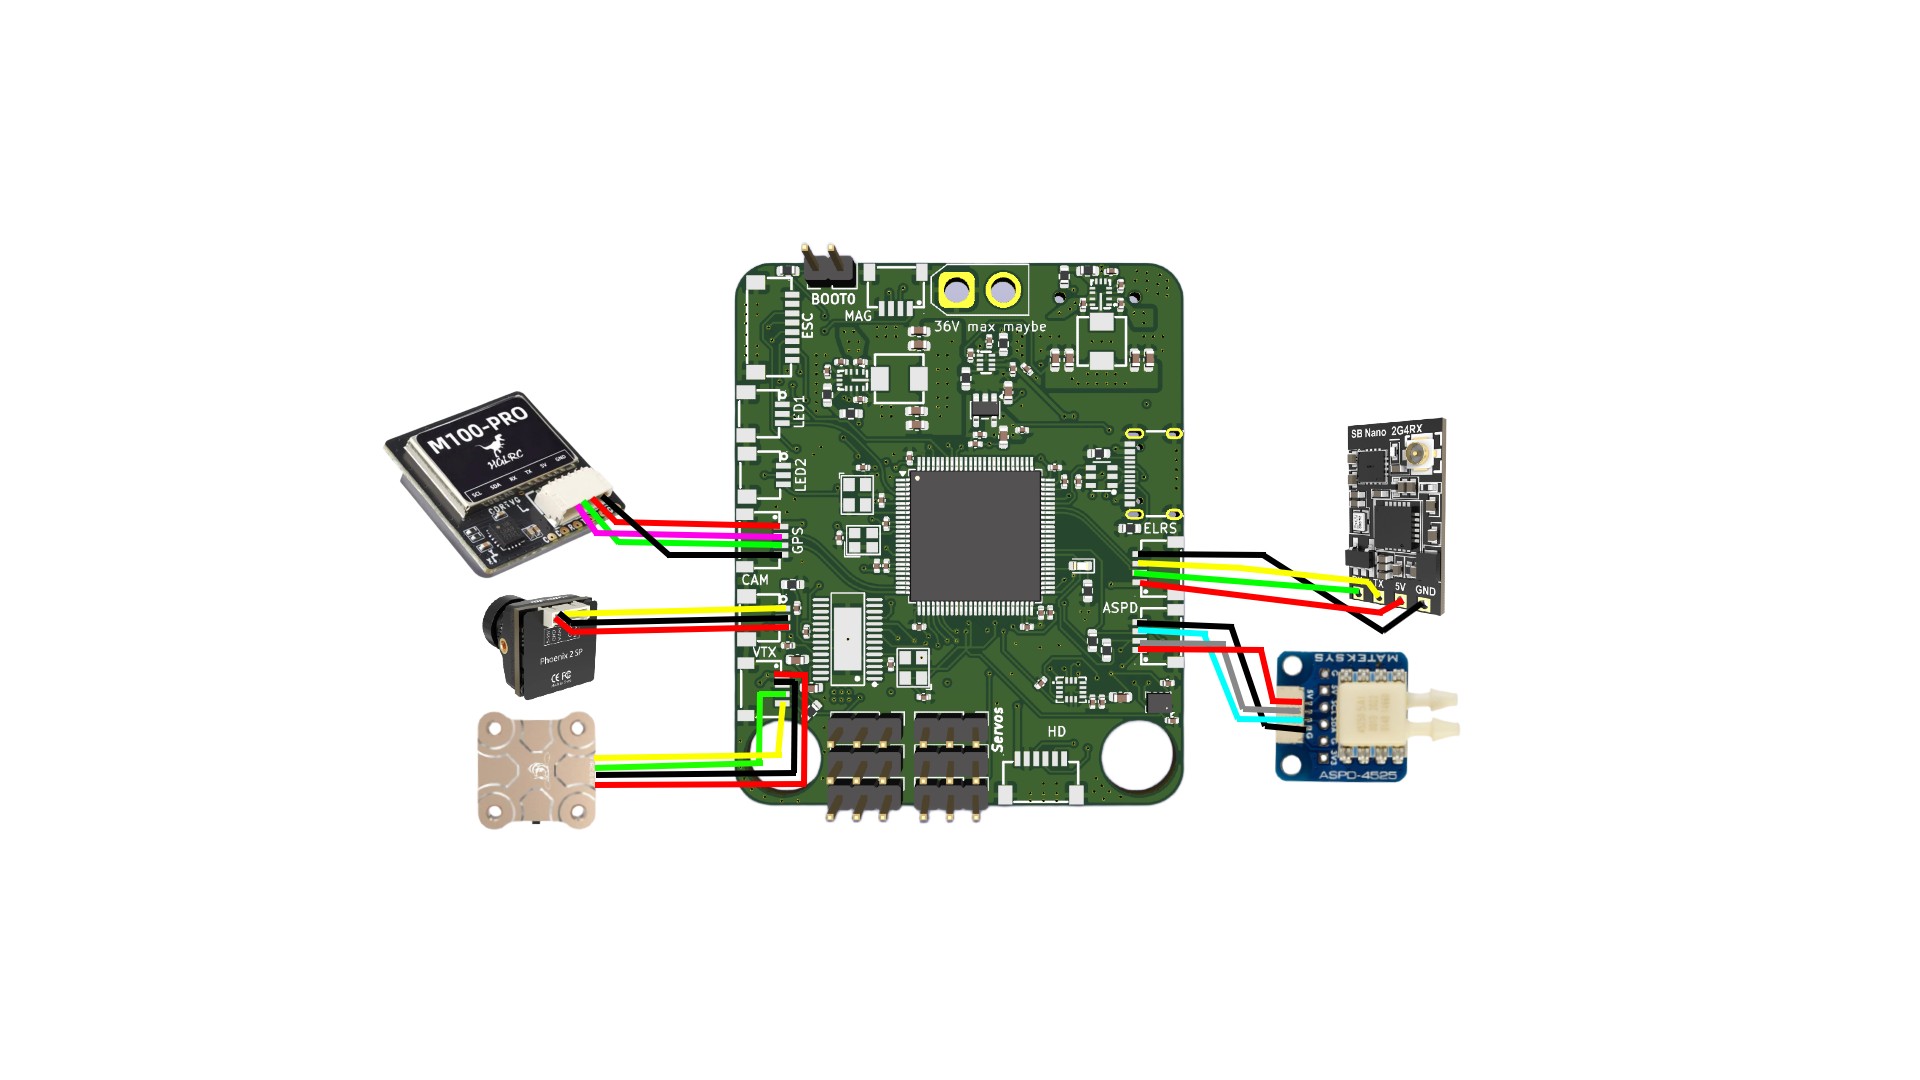
The flight controller board has connectors for external airspeed, GPS, and mag sensors as well as plugs for ELRS, 4 in 1 ESC, analog camera, analog VTX, digital VTX and PWM LEDs.
Firmware/flashing:
This board does not have custom firmware, it is based on INAV: https://github.com/iNavFlight/inav/. However a custom build of INAV including relevant target configuration is required. I will put this custom target in the /Project_Files/INAV folder. This tutorial shows how to build INAV with a custom target: https://youtu.be/ThrsS_y9zDo?si=cllAaaTRHZ6ADbW4 To flash the board, the board must be powered up with the boot0 pin shorted to enter DFU mode on the STM32 where it can then be flashed in INAV configurator.
BOM:
The board costs about £27 from JLCPCB for a basic 6 layer PCB. The BOM for components can be found in the BOM.csv in the production folder. This totals around £40 which mainly accounts for buying large quantities of passives so the per board price is probably much cheaper.
| Qty | Value | Footprint | References |
|---|---|---|---|
| 25 | 100nF | Capacitor_SMD:C_0402_1005Metric | C3, C4, C10, C11, C12, C13, C14, C15, C16, C18, C19, C27, C30, C32, C34, C46 +9 |
| 9 | 22uF | Capacitor_SMD:C_0603_1608Metric | C8, C23, C24, C25, C26, C38, C39, C40, C41 |
| 6 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J6, J7, J8, J9, J10, J11 |
| 5 | 10k | Resistor_SMD:R_0603_1608Metric | R1, R2, R3, R6, R7 |
| 5 | 1uF | Capacitor_SMD:C_0402_1005Metric | C22, C37, C42, C43, C44 |
| 4 | 10uF | Capacitor_SMD:C_0402_1005Metric | C9, C17, C20, C35 |
| 3 | 2.2uF | Capacitor_SMD:C_0402_1005Metric | C1, C2, C33 |
| 2 | 1.2k | Resistor_SMD:R_0603_1608Metric | R16, R17 |
| 2 | 100k | Resistor_SMD:R_0603_1608Metric | R10, R12 |
| 2 | 10uH | easyeda2kicad:IND-SMD_L5.2-W5.2_MCW-0530 | L1, L2 |
| 2 | 220nF | Capacitor_SMD:C_0402_1005Metric | C21, C36 |
| 2 | 47uF | Capacitor_SMD:C_0603_1608Metric | C28, C29 |
| 2 | 5.1k | Resistor_SMD:R_0603_1608Metric | R4, R5 |
| 2 | 600@100MHz | Capacitor_SMD:C_0603_1608Metric | FB1, FB2 |
| 2 | 75 | Resistor_SMD:R_0603_1608Metric | R18, R19 |
| 2 | LMR33630ARNXR | easyeda2kicad:VQFN-12_L3.0-W2.0-P0.65-BL_TI_RNX | U8, U9 |
| 1 | 10nF | Capacitor_SMD:C_0402_1005Metric | C31 |
| 1 | 12.4k | Resistor_SMD:R_0603_1608Metric | R13 |
| 1 | 200 | Resistor_SMD:R_0603_1608Metric | R20 |
| 1 | 24.9k | Resistor_SMD:R_0603_1608Metric | R11 |
| 1 | 25MHz | easyeda2kicad:OSC-SMD_4P-L2.5-W2.0-BL | U6 |
| 1 | 27MHz | easyeda2kicad:OSC-SMD_4P-L3.2-W2.5-BL | X2 |
| 1 | 32.768kHz | easyeda2kicad:OSC-SMD_4P-L3.2-W2.5-BL | X1 |
| 1 | 4.7uF | Capacitor_SMD:C_0402_1005Metric | C45 |
| 1 | AP2112K-3.3 | Package_TO_SOT_SMD:SOT-23-5 | U5 |
| 1 | ASPD | easyeda2kicad:CONN-SMD_4P-P1.00_SM04B-SRSS-TB-LF-SN | CN1 |
| 1 | AT7456E | easyeda2kicad:TSSOP-28_L9.7-W4.4-P0.65-LS6.4-BL-EP-2 | U12 |
| 1 | BMP280 | Package_LGA:Bosch_LGA-8_2x2.5mm_P0.65mm_ClockwisePinNumbering | U3 |
| 1 | BOOT0 Header | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J2 |
| 1 | CAM | easyeda2kicad:CONN-SMD_SM03B-SRSS-TB-LF-SN-P | U13 |
| 1 | ELRS | easyeda2kicad:CONN-SMD_4P-P1.00_SM04B-SRSS-TB-LF-SN | CN5 |
| 1 | ESC_Connector | easyeda2kicad:CONN-TH_SM08B-SRSS-TB-LF-SN | P1 |
| 1 | GPS | easyeda2kicad:CONN-SMD_4P-P1.00_SM04B-SRSS-TB-LF-SN | CN4 |
| 1 | HD | easyeda2kicad:CONN-SMD_SM06B-SRSS-TB-LF-SN | U10 |
| 1 | ICM-42688-P | easyeda2kicad:LGA-14_L3.0-W2.5-P0.50-TL | U1 |
| 1 | LED1 | easyeda2kicad:CONN-SMD_SM03B-SRSS-TB-LF-SN-P | U4 |
| 1 | LED2 | easyeda2kicad:CONN-SMD_SM03B-SRSS-TB-LF-SN-P | U11 |
| 1 | LM66200DRLR | easyeda2kicad:SOT-583-8_L2.1-W1.2-P0.50-LS1.6-BL | U2 |
| 1 | MAG | easyeda2kicad:CONN-SMD_4P-P1.00_SM04B-SRSS-TB-LF-SN | CN2 |
| 1 | Micro_SD_Card | easyeda2kicad:TF-SMD_TF-PUSH | J1 |
| 1 | PD9 | LED_SMD:LED_0603_1608Metric | D2 |
| 1 | STM32H743VITx | Package_QFP:LQFP-100_14x14mm_P0.5mm | U7 |
| 1 | USBLC6-2SC6 | easyeda2kicad:SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | D1 |
| 1 | USB_C_Receptacle_USB2.0_16P | easyeda2kicad:USB-C-SMD_TYPE-C-16PIN-2MD-073 | J3 |
| 1 | VTX | easyeda2kicad:CONN-SMD_4P-P1.00_SM04B-SRSS-TB-LF-SN | CN3 |
The 104 most common of 105 parts.
OpenDrone-hw/OpenFC-Lite
Open-source Betaflight flight controller. RP2354B, 30.5x30.5 mm, 6-layer, 3-8S, CERN-OHL-S-2.0.


HeyPCB/kestrel-fc
Kestrel H7: STM32H743 FPV flight controller with ICM-20602 + BMI088, MS5611, 16 MB blackbox, 5 V and switchable 10 V BECs.


ara-mkr/f405-flight-controller
This is a flight controller I designed as a side project. It was fun and pretty challenging, and I'm planning to build a drone with it at some point!

Kaiser041224/HPM5361-RMCS_Slave-Pro
HPM5361-RMCSSlave-V1.0 是一个基于 KiCad 9 的硬件工程,核心主控为 HPM5361ICB1。从顶层框图、层级原理图和关键器件选型来看,这块板更像一块面向机器人/运动控制场景的从控板,用于通信汇聚、PWM 外设输出、姿态感知、板载存储和基础人机交互。

darshg321/Mini-Air
Mini-Air is a DIY FPV drone! it features: - a custom flight controller supporting Betaflight - an ESC supporting Bluejay firmware - ELRS protocol - an analog camera - GPS

sneakylizard123-4/Dreamscape-F405-2020
a 20x20mm flight controller for 3" fpv drone
It measures 48 × 58 mm and has 6 copper layers, 1.6 mm thick.
105 parts, built around the AT7456E, LMR33630ARNXR, BMP280 and 8122S-25.000NQ33FTL. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the HazzerTheGreat/SPAR repository on GitHub, at the commit this page was made from: the board is PCB/FlightControllerV2.kicad_pcb and its schematic PCB/FlightControllerV2.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask HazzerTheGreat before reusing the design.