4 layers66.2 × 71 mm
Macropad
astinchang/KiCAD-Macropad
Custom RP2040-based controller board designed to interface with:
67 partsUnlicense

 ElectronPlant/beepy_rc
Hobby project to make a RC rover platform using spare RC parts.
BeepyRcBrd only top is an open-source printed circuit board by ElectronPlant, from the ElectronPlant/beepy_rc repository on GitHub. It is a 4-layer board of 100 × 150 mm with 173 parts on 124 nets.
It is built around the TC118S, AT25SF161B-SSHB-T and CD4011BM96, with the INA139NA, TLV1117-33DCY and BSS138LT1G among its other parts. Its parts include 45 resistors, 33 capacitors, 19 connectors, 15 diodes and 12 ICs. It belongs with the robots and motor control boards and the STM32 boards of this library.


Hobby project to make a RC rover platform using spare RC parts. The goal of this project is to develop a complete platform to support long term RC assisted missions.
Content summary
* The platform is built on a custom PCB based on a STM32F4 microcontroller.
* The firmware is implemented using FreeRTOS for simple and reliable multitasking and real-time operation.
* The enclosure is fully 3d printable.
* Support for off-the-shelf RC components with SBUS, 5V VTX power output, 3x standard servo outputs.Minimal-feature rover to support a simple, yet fun mission: exploring the house and firing a Nerf blaster in FPV (First-Person View).
The rover enables you to explore the house remotely using the RC interface and the FPV live feed provided by the video transmitter (VTX). The Nerf blaster and the VTX are mounted on a servo-operated arm, which controls their yaw and pitch angles. The arm provides two extra degrees of freedom to easily explore the room and aim the blaster. Once the target has been acquired, take the shot remotely using the aux channels of the RC remote.
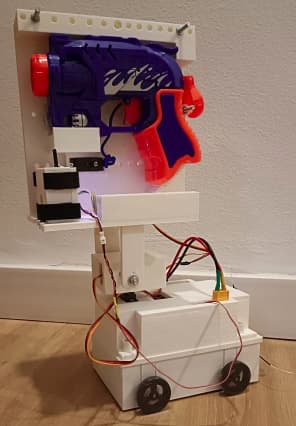
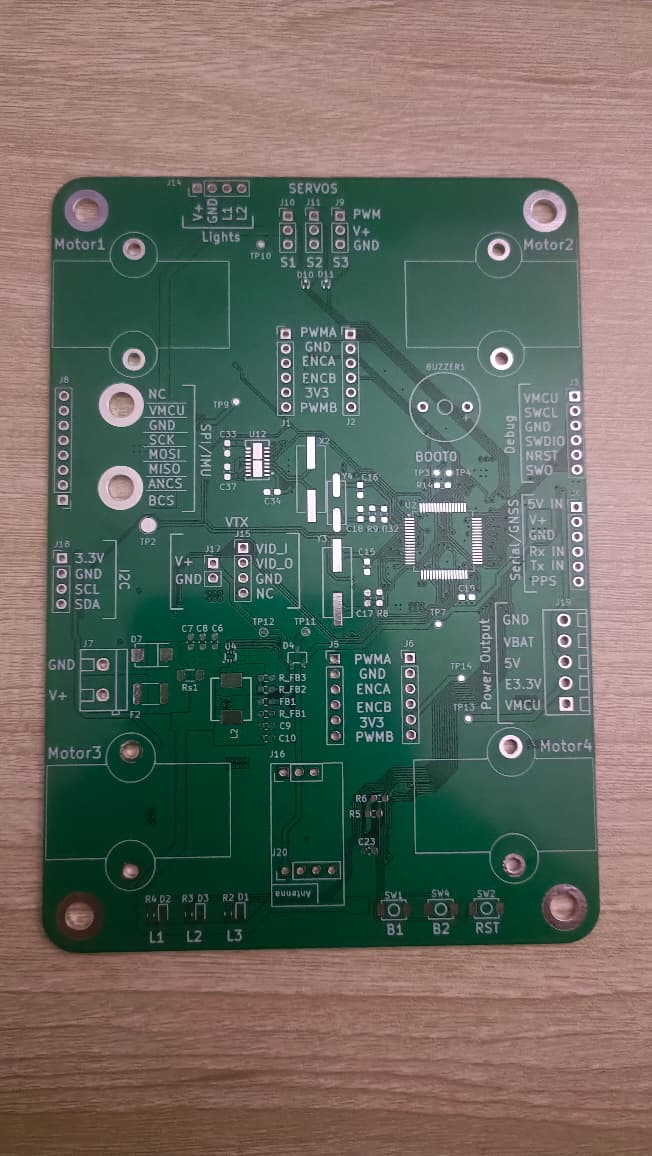
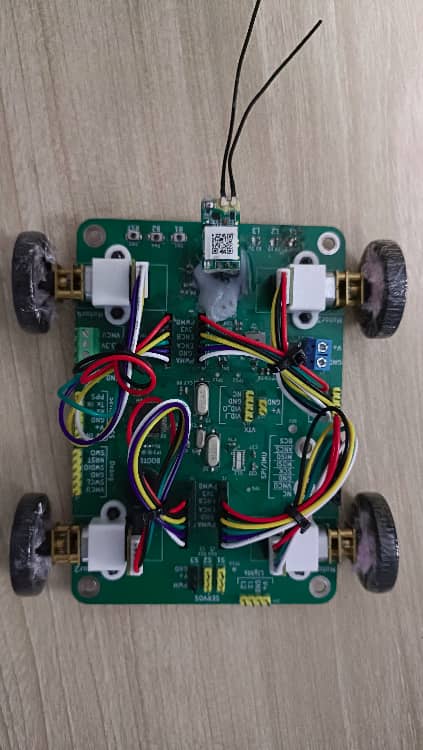
For more information about the project check the documentation in docs/ or deplay with mkdocs
run:
pip install mkdocsor:
python -m pip install mkdocspip install mkdocs-materialor:
python -m pip install mkdocs-materialpip install mkdoxyor
python -m pip install mkdoxyThe installation procedure depends on the operating system, see: Doxygen docs
For ubuntu:
sudo apt-get install doxygenmkdocs servethen the documentation will be served at:
http://127.0.0.1:8000/| Qty | Value | Footprint | References |
|---|---|---|---|
| 18 | 10k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R1, R14, R16, R19, R20, R29, R30, R35, R36, R37, R38, R39, R40, R41, R43, R45 +2 |
| 12 | 100nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C8, C21, C22, C23, C24, C25, C26, C28, C30, C33, C34, C37 |
| 9 | TestPoint | TestPoint:TestPoint_Pad_D1.0mm | TP3, TP4, TP7, TP9, TP10, TP11, TP12, TP13, TP14 |
| 8 | MT | MountingHole:MountingHole_2.2mm_M2_DIN965_Pad_TopBottom | H5, H6, H7, H8, H9, H10, H11, H12 |
| 7 | UESD3.3DT5G | lscs:SOT-723_L1.2-W0.8-P0.40-LS1.2-BR | D9, D10, D11, D12, D13, D14, D15 |
| 6 | 0 | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R13, R15, R21, R22, R27, R28 |
| 6 | MT | MountingHole:MountingHole_4.3mm_M4_DIN965_Pad_TopBottom | H1, H2, H3, H4, H13, H14 |
| 5 | 1μF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C3, C4, C5, C11, C27 |
| 5 | Conn_01x04 | Connector_PinHeader_2.54mm:PinHeader_1x04_P2.54mm_Vertical | J13, J14, J15, J18, J20 |
| 5 | Conn_01x06 | Connector_PinHeader_2.54mm:PinHeader_1x06_P2.54mm_Vertical | J1, J2, J3, J5, J6 |
| 4 | 22R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R23, R24, R25, R26 |
| 4 | 22μF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C9, C10, C14, C29 |
| 4 | BSS138LT1G | lscs:SOT-23-3_L2.9-W1.6-P1.90-LS2.8-BR | Q1, Q2, Q4, Q5 |
| 4 | Motor | beepyRcBrd:Motor | Motor1, Motor2, Motor3, Motor4 |
| 4 | TC118S | lscs:SOP-8_L4.9-W3.9-P1.27-LS6.0-BL | U1, U6, U7, U8 |
| 3 | 10μF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C6, C7, C20 |
| 3 | 2.2k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R2, R3, R4 |
| 3 | 51k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R7, R10, R12 |
| 3 | Conn_01x03 | Connector_PinHeader_2.54mm:PinHeader_1x03_P2.54mm_Vertical | J9, J10, J11 |
| 3 | SW_Push | lscs:SW-SMD_L3.9-W3.0-P4.45 | SW1, SW2, SW4 |
| 2 | 10nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C12, C13 |
| 2 | 14pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C16, C18 |
| 2 | 30pF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C15, C17 |
| 2 | 3k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R_FB2, R_FB3 |
| 2 | 51R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R17, R18 |
| 2 | 75R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R33, R34 |
| 2 | CDSOT23-SM712 | lscs:SOT-23_L2.9-W1.3-P1.90-LS2.4-BR | D6, D8 |
| 2 | FerriteBead | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | FB1, FB2 |
| 1 | 1.8μH | lscs:IND-SMD_L7.0-W6.6_MCW-0650-220 | L2 |
| 1 | 100R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R31 |
| 1 | 150k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R9 |
| 1 | 17m | Resistor_SMD:R_1206_3216Metric_Pad1.30x1.75mm_HandSolder | Rs1 |
| 1 | 18nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C2 |
| 1 | 200k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R32 |
| 1 | 30k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R11 |
| 1 | 4.7μF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C19 |
| 1 | 40k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R42 |
| 1 | 49k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R_FB1 |
| 1 | 5.1nF | Capacitor_SMD:C_0603_1608Metric_Pad1.08x0.95mm_HandSolder | C1 |
| 1 | 50k | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R44 |
| 1 | 604R | Resistor_SMD:R_0603_1608Metric_Pad0.98x0.95mm_HandSolder | R8 |
| 1 | AT25SF161B-SSHB-T | lscs:SOP-8_L4.9-W3.9-P1.27-LS6.0-BL | U11 |
| 1 | AT7456ELAH_C42388749 | lscs:LGA-16_L6.8-W4.0-P0.65-TL-2EP | U12 |
| 1 | BSMD1812L-600-12V | Fuse:Fuse_1812_4532Metric_Pad1.30x3.40mm_HandSolder | F2 |
| 1 | BSS138DW-7-F | lscs:SC-70-6_L2.2-W1.3-P0.65-LS2.1-TL | Q3 |
| 1 | CD4011BM96 | beepyRcBrd:SOIC-14_L8.7-W3.9-P1.27-LS6.0-BL | U10 |
| 1 | Conn_01x02 | lscs:CONN-TH_P5.00_KF301-5.0-2P | J7 |
| 1 | Conn_01x02 | Connector_PinHeader_2.54mm:PinHeader_1x02_P2.54mm_Vertical | J17 |
| 1 | Conn_01x03 | beepyRcBrd:rc | J16 |
| 1 | Conn_01x05 | lscs:CONN-TH_5P-P3.50_DORABO_DB125-3.5-5P-GN-S | J19 |
| 1 | Conn_01x05 | Connector_PinHeader_2.54mm:PinHeader_1x05_P2.54mm_Vertical | J12 |
| 1 | Conn_01x08 | beepyRcBrd:gy91 | J8 |
| 1 | D_Schottky | Diode_SMD:D_SOD-323 | D5 |
| 1 | GREEN | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D2 |
| 1 | H6OEL89CSC-SUGYLC-27M | lscs:HC-49S_L11.4-W4.8-LS12.7 | X2 |
| 1 | HY8M49SSMDOB2R20 | lscs:CRYSTAL-SMD_L11.4-W4.7-LS12.7 | Y3 |
| 1 | INA139 | Package_TO_SOT_SMD:SOT-23-5 | U3 |
| 1 | M332768DWNAC | lscs:OSC-SMD_2P-L7.4-W3.1-LS8.0 | Y4 |
| 1 | MC33275ST-3.3T3G | lscs:SOT-223_L6.5-W3.5-P2.30-LS7.0-BR | U5 |
| 1 | MINISMDC050F-2 | Fuse:Fuse_1812_4532Metric_Pad1.30x3.40mm_HandSolder | F1 |
| 1 | RED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1 |
| 1 | SDM20E40C-7-F | lscs:SOT-23-3_L2.9-W1.6-P1.90-LS2.8-BR | D4 |
| 1 | SMBJ15A_C83846 | lscs:SMB_L4.6-W3.6-LS5.3-RD | D7 |
| 1 | STM32F446RETx | Package_QFP:LQFP-64_10x10mm_P0.5mm | U2 |
| 1 | TLV1117-33 | lscs:SOT-223_L6.5-W3.5-P2.30-LS7.0-BR | U9 |
| 1 | TMB12A05 | lscs:BUZ-TH_BD12.0-P7.60-D0.6-FD | BUZZER1 |
| 1 | TPS564242DRLR | lscs:SOT-5X3-6_W1.6-L1.2-P0.50-LS1.6-BL | U4 |
| 1 | TestPoint | TestPoint:TestPoint_Pad_D2.5mm | TP2 |
| 1 | YELLOW | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D3 |
astinchang/KiCAD-Macropad
Custom RP2040-based controller board designed to interface with:

jgazeley/accord
Raspberry Pi Pico W firmware and keyless-entry hardware for a 2001 Honda Accord.

pasachan/ESP-32-RELAY-CONTROLLER
An 8-channel relay controller with Wi-Fi, an RS-485 field bus, and a 12 V power rail for downstream nodes. Designed as the master board for a small home-automation network: this board switches loads directly, talks to…


laneboysrc/rc-light-controller
Extensible RC car light controller with Web-based configuration tool

RocketScientist26/Quadruped-Hardware
Main, Battery protection and Servo PCBs for Quadruped robot

AndreiVladescu/LibrePLC32
The goal of the project is to create a compact, hackable, and well-documented PLC platform for industrial automation experiments, prototyping, education, and open hardware development.

emb3rcia/spark-rp2040-swd-probe
Open-source financialy-accesible SWD probe.
It measures 100 × 150 mm and has 4 copper layers, 1.6 mm thick.
173 parts, built around the TC118S, AT25SF161B-SSHB-T, CD4011BM96 and INA139NA. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the ElectronPlant/beepy_rc repository on GitHub, at the commit this page was made from: the board is hardware/beepyRcBrd/beepyRcBrd_only_top.kicad_pcb and its schematic hardware/beepyRcBrd/3v3_external_reg.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository states no licence, so its author keeps all rights: ask ElectronPlant before reusing the design.