4 layers98.8 × 80 mm
Brushless Controller Test Board
DJAY101/Dynamiq_BLDC_Controller
Bringing brushless motor control to the masses
118 partsGPL-3.0

 DJAY101/Dynamiq_BLDC_Controller
Bringing brushless motor control to the masses
BLDC Version1 1 0 is an open-source printed circuit board by DJAY101, from the DJAY101/Dynamiq_BLDC_Controller repository on GitHub, published under the GPL-3.0 licence. It is a 4-layer board of 80 × 80 mm with 125 parts on 113 nets, routed with 706 tracks and 573 vias.
It is built around the ESP32-S3-WROOM-1-N8, TMC6200-TA-T and TPS5430DDAR, with the SRV05-4-HXY, DB910-7.62-3P-GN-S and SI7129DN-T1-GE3-HXY among its other parts. Its parts include 29 resistors, 26 capacitors, 12 ICs, 9 diodes and 7 transistors. It belongs with the robots and motor control boards and the ESP32 boards of this library.


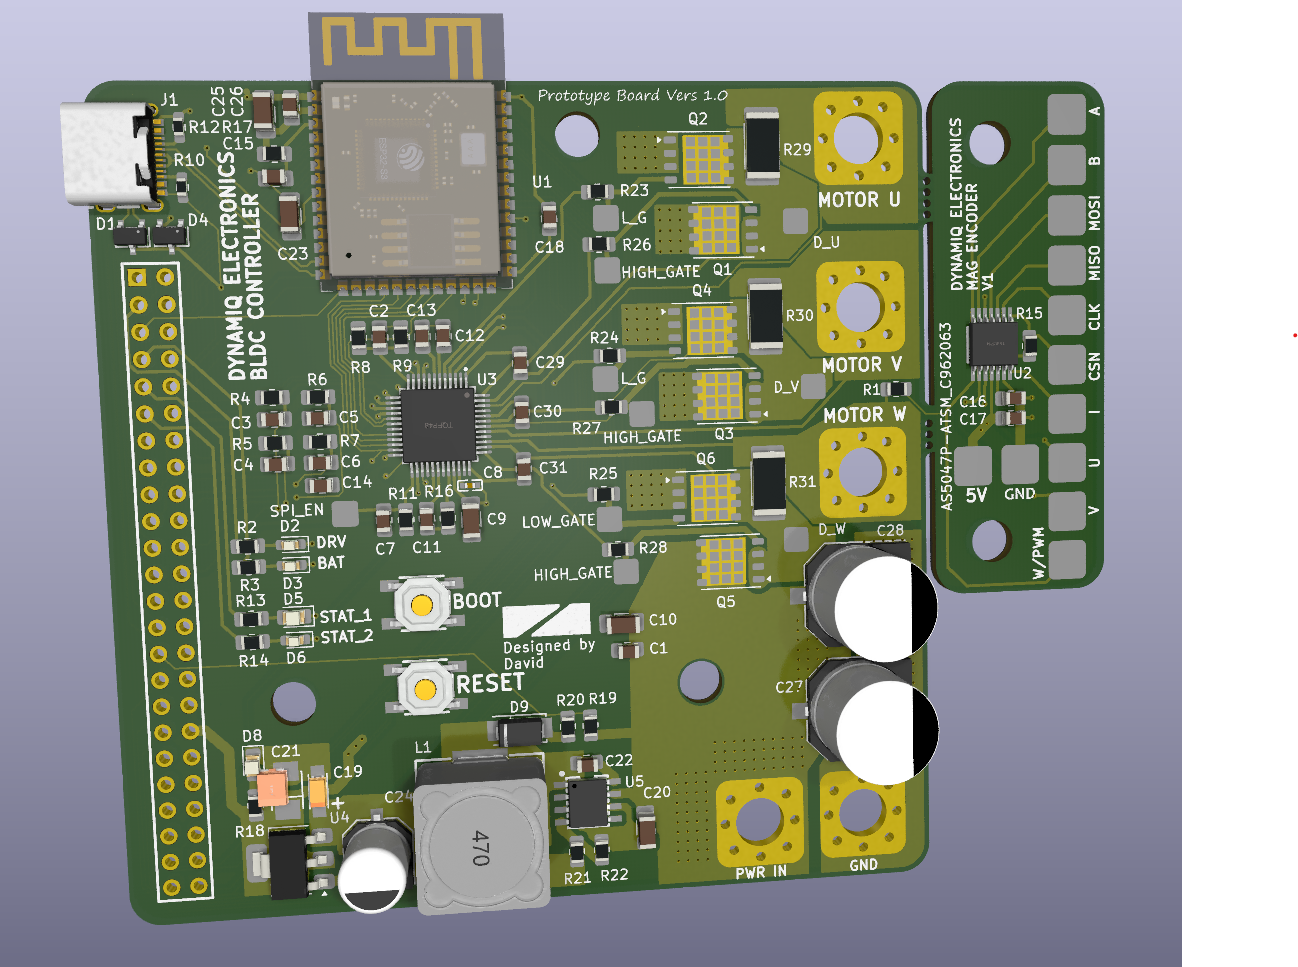 I'm currently on the journey of creating a simple cost effective controller that
will eventually be sold to the masses to remove the high barrier to entry into using high performing brushless motor actuators.
FRC Falcon 500 Motors inspired this project, since there are no suitable motor options at a suitable price that enables hobbyists to utilise these amazing pieces of technology. (Odrive being 200USD+)
(Do note this is actually my very second PCB designed, so I lack a lot of experience)
Version 1 of the PCB worked with the following code. However I ended up frying two of the boards during programming and tinkering with the board. I am currently working on a version 2 iteration of the PCB from the mistakes and lack of safety features in V1.
(I actually got the motor to turn on the very first iteration of this board which is a massive win)
The progress on the code is halted as I have no working boards anymore since I fried all 2 of them haha.
PCB was manufactured by JLPCB, assembly services was also opted, 5 boards were 10 bucks aud and assembly and parts for 2 board added $150 aud
Reddit also reviewd my board before I manufactured it heres the link to that discussion https://www.reddit.com/r/PCB/comments/1lk1n3d/review_request_my_first_pcb_bldc_sinusoidal/
This man made coding this thing a lot easier. Just pass sine waves into the motor and itll turn. I reckon it was much more easier to implement than step control. https://www.youtube.com/watch?v=zSdetJsSeNw&t
Cool channels
If you'd like to contact me for more information or collaboration on this project feel free to DM me on insta at DJAY10101, or if you prefer email its djay01602@gmail.com
| Qty | Value | Footprint | References |
|---|---|---|---|
| 11 | 10K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R5, R8, R10, R17, R19, R20, R21, R22, R24, R25, R27 |
| 6 | 0.1uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C2, C15, C17, C18, C22, C23 |
| 6 | 2.2 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R12, R13, R15, R16, R23, R26 |
| 6 | N_FET_ISC0602NLS | Project_BLDC_Foorprint_Library:Infineon_PG-TDSON-8_6.15x5.15mm | Q1, Q2, Q4, Q5, Q6, Q7 |
| 6 | TestPoint | TestPoint:TestPoint_Pad_D2.0mm | TP8, TP9, TP10, TP11, TP12, TP13 |
| 5 | 150 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R1, R2, R3, R4, R7 |
| 4 | SRV05-4-HXY | easyeda2kicad:SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BR | U10, U11, U13, U14 |
| 4 | SolderJumper_2_Open | Jumper:SolderJumper-2_P1.3mm_Open_TrianglePad1.0x1.5mm | AMPL, DRV, I_0, I_1 |
| 3 | 10mR | Resistor_SMD:R_2512_6332Metric_Pad1.40x3.35mm_HandSolder | R14, R18, R29 |
| 3 | 10uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C1, C3, C7 |
| 3 | 4.7uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C4, C5, C20 |
| 3 | 470nF 16V | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C13, C14, C29 |
| 3 | C | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | CU, CV, CW |
| 3 | HIGH_GATE | easyeda2kicad:SMD_RH-5015 | TP3, TP6, TP22 |
| 3 | LED | LED_SMD:LED_0805_2012Metric_Pad1.15x1.40mm_HandSolder | D3, D4, D6 |
| 3 | LOW_GATE | easyeda2kicad:SMD_RH-5015 | TP2, TP5, TP19 |
| 3 | OUTPUT_POINT | easyeda2kicad:SMD_RH-5015 | TP4, TP7, TP25 |
| 3 | TestPoint | easyeda2kicad:SMD_RH-5015 | TP14, TP15, TP16 |
| 2 | 0.1uF 50V | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C25, C26 |
| 2 | 100uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C6, C9 |
| 2 | 3.3K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R9, R11 |
| 2 | B340A-E3/61T | easyeda2kicad:SMA_L4.3-W2.6-LS5.2-RD | D7, D8 |
| 2 | LED | LED_SMD:LED_0603_1608Metric_Pad1.05x0.95mm_HandSolder | D1, D2 |
| 2 | RVT1E471M1010-C3351 | easyeda2kicad:CAP-SMD_BD10.0-L10.3-W10.3-LS11.0-FD | C11, C12 |
| 2 | SW_MEC_5E | easyeda2kicad:SW-SMD_4P-L5.2-W5.2-P3.70-LS6.5 | SW1, SW2 |
| 2 | ~ | Project_BLDC_Foorprint_Library:1x3 Male Headers | U6, U8 |
| 1 | 0.01uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C8 |
| 1 | 100nF 16V | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C27 |
| 1 | 1A Fuse | Fuse:Fuse_1206_3216Metric_Pad1.42x1.75mm_HandSolder | F1 |
| 1 | 1K | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R6 |
| 1 | 2.2uF | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C21 |
| 1 | 220uF | easyeda2kicad:CAP-SMD_BD6.3-L6.6-W6.6-FD | C10 |
| 1 | 22nF 100V | Capacitor_SMD:C_0805_2012Metric_Pad1.18x1.45mm_HandSolder | C28 |
| 1 | 22uH | easyeda2kicad:IND-SMD_L5.5-W5.2 | L1 |
| 1 | 47 | Resistor_SMD:R_0805_2012Metric_Pad1.20x1.40mm_HandSolder | R28 |
| 1 | 8x Male Headers | Project_BLDC_Foorprint_Library:2x4 Male Headers | U7 |
| 1 | AP7363-33D-13 | Package_TO_SOT_SMD:TO-252-2 | U2 |
| 1 | DB910-7.62-3P | easyeda2kicad:CONN-TH_3P-P7.62_DB910-7.62-3P | CN1 |
| 1 | ESP32-S3-WROOM-1 | PCM_Espressif:ESP32-S3-WROOM-1 | U1 |
| 1 | LOGO | Project_BLDC_Foorprint_Library:LOGO_LARGE | G*** |
| 1 | LOGO | Project_BLDC_Foorprint_Library:Cat | G*** |
| 1 | LOGO | Project_BLDC_Foorprint_Library:LOGO | G*** |
| 1 | Male Headers | Project_BLDC_Foorprint_Library:1x6 Male Headers | U9 |
| 1 | SI7129DN-T1-GE3 | easyeda2kicad:POWERPAK-1212-8_L3.3-W3.3-P0.65-BL-EP | Q3 |
| 1 | SM03B-GHS-TB(LF)(SN) | easyeda2kicad:CONN-TH_SM03B-GHS-TB-LF-SN | CN4 |
| 1 | SM06B-GHS-TB(LF)(SN) | easyeda2kicad:CONN-TH_SM06B-GHS-TB-LF-SN | CN3 |
| 1 | SMAJ18CA_C908822 | easyeda2kicad:SMA_L4.4-W2.8-LS5.1-BI | D5 |
| 1 | TMC6200-TA-T | easyeda2kicad:TQFP-48_L7.0-W7.0-P0.50-LS9.0-BL-EP | U3 |
| 1 | TPS5430DDAR | easyeda2kicad:ESOP-8_L4.9-W3.9-P1.27-LS6.0-TL-EP | U4 |
| 1 | TestPoint | TestPoint:TestPoint_Pad_D3.0mm | 5V |
| 1 | USBLC6-2SC6 | easyeda2kicad:SOT-23-6_L2.9-W1.6-P0.95-LS2.8-BL | D9 |
| 1 | USB_C_Receptacle_USB2.0_14P | easyeda2kicad:USB-C_SMD-TYPE-C-31-M-12 | J1 |
| 1 | XT60PW-M | easyeda2kicad:CONN-TH_XT60PW-M | CN2 |
The 121 most common of 125 parts.
DJAY101/Dynamiq_BLDC_Controller
Bringing brushless motor control to the masses

slippery-carrot/ESPrinkler-Retic-Controller
8-Zone reticulation controller based on ESPHome for Home Assistant

acanyulaf/24V-10A-BLDC-Driver
This is a technical assignment problem given by Kuartis. The aim is to design a 24V/10A BLDC controller. There will be also an I2C or SPI interface for control inputs.


Tropaion/Manafish_Mainboard
The Manafish Mainboard is the main electronics board of the Manafish ROV. It replaces the Raspberry Pi 3B, the USB-connected Raspberry Pi Pico and the wiring between them with one board:

Arrow-air/project-caribou
Project Caribou documentation, designs, and project artifacts.


It measures 80 × 80 mm and has 4 copper layers, 1.6 mm thick.
125 parts, built around the ESP32-S3-WROOM-1-N8, TMC6200-TA-T, TPS5430DDAR and SRV05-4-HXY. The full list of its parts is on this page, with links to each part's symbol and footprint where PCBKit's library has them.
From the DJAY101/Dynamiq_BLDC_Controller repository on GitHub, at the commit this page was made from: the board is Version 1.1 PCB/BLDC_Version1_1_0.kicad_pcb and its schematic PCB_FILES_Version1/Brushless_Controller_Test_Board.kicad_sch. PCBKit opens the board in the browser, with nothing to install.
Its repository publishes it under the GPL-3.0 licence: you may reuse it on that licence's terms (keep the author's notice, and for a copyleft licence share your changes alike).